Compare commits
| Author | SHA1 | Date | |
|---|---|---|---|
 Danny Nguyen |
4a8e62d30e | ||
|
Danny Nguyen
|
2c8149aa55 | ||
|
holtenc
|
5971b663cb | ||
|
gorbachev
|
6766c5315e | ||
|
Danny
|
0744af97af | ||
|
|
3449000f42 | ||
|
Nick Brassel
|
155be34a1d | ||
|
XScorpion2
|
4f788c2ae9 | ||
|
|
02b3fadbac | ||
|
zunger-humu
|
912b6a5916 | ||
|
kakunpc
|
67105b2a21 | ||
|
|
0874502757 | ||
|
|
d9ebd5cde6 | ||
|
zvecr
|
c393d3afde | ||
|
Austin Hill
|
8eb5022af5 | ||
|
jotix
|
016a258301 | ||
|
jotix
|
9f5733b595 | ||
|
Elliot Powellandnoroadsleft
|
d3317a8a66 | ||
|
zvecr
|
f9c0936cea | ||
|
zvecr
|
dabd73b769 | ||
|
noroadsleft
|
2a1f6389c2 | ||
|
Elliot Powell
|
9cc5841a91 | ||
|
zvecr
|
ba6b3fc1b5 | ||
|
Alex Speller
|
6693d16362 | ||
|
yiancar
|
6241cf977e | ||
|
Austin Hill
|
b877596096 | ||
|
Jason Dunsmore
|
3fd34daf14 | ||
|
Peter Tillemans
|
88966767ee | ||
|
Elliot Powell
|
3ef425423a |
No files matched your search
+7
-17
@@ -11,31 +11,21 @@ env:
|
|||||||
global:
|
global:
|
||||||
- secure: vBTSL34BDPxDilKUuTXqU4CJ26Pv5hogD2nghatkxSQkI1/jbdnLj/DQdPUrMJFDIY6TK3AltsBx72MaMsLQ1JO/Ou24IeHINHXzUC1FlS9yQa48cpxnhX5kzXNyGs3oa0qaFbvnr7RgYRWtmD52n4bIZuSuW+xpBv05x2OCizdT2ZonH33nATaHGFasxROm4qYZ241VfzcUv766V6RVHgL4x9V08warugs+RENVkfzxxwhk3NmkrISabze0gSVJLHBPHxroZC6EUcf/ocobcuDrCwFqtEt90i7pNIAFUE7gZsN2uE75LmpzAWin21G7lLPcPL2k4FJVd8an1HiP2WmscJU6U89fOfMb2viObnKcCzebozBCmKGtHEuXZo9FcReOx49AnQSpmESJGs+q2dL/FApkTjQiyT4J6O5dJpoww0/r57Wx0cmmqjETKBb5rSgXM51Etk3wO09mvcPHsEwrT7qH8r9XWdyCDoEn7FCLX3/LYnf/D4SmZ633YPl5gv3v9XEwxR5+04akjgnvWDSNIaDbWBdxHNb7l4pMc+WR1bwCyMyA7KXj0RrftEGOrm9ZRLe6BkbT4cycA+j77nbPOMcyZChliV9pPQos+4TOJoTzcK2L8yWVoY409aDNVuAjdP6Yum0R2maBGl/etLmIMpJC35C5/lZ+dUNjJAM=
|
||||||
- MAKEFLAGS="-j3 --output-sync"
|
- MAKEFLAGS="-j3 --output-sync"
|
||||||
|
services:
|
||||||
|
- docker
|
||||||
before_install:
|
before_install:
|
||||||
- wget http://ww1.microchip.com/downloads/en/DeviceDoc/avr8-gnu-toolchain-3.5.4.1709-linux.any.x86_64.tar.gz || wget http://qmk.fm/avr8-gnu-toolchain-3.5.4.1709-linux.any.x86_64.tar.gz
|
- docker build -t qmkfm/qmk_firmware .
|
||||||
# Need DFU > .5 for dfu-suffix
|
|
||||||
- sudo add-apt-repository --yes ppa:tormodvolden/ppa
|
|
||||||
- sudo apt-get update -qq
|
|
||||||
install:
|
install:
|
||||||
- tar -zxf avr8-gnu-toolchain-3.5.4.1709-linux.any.x86_64.tar.gz
|
|
||||||
- export PATH="$PATH:$TRAVIS_BUILD_DIR/avr8-gnu-toolchain-linux_x86_64/bin"
|
|
||||||
- npm install -g moxygen
|
- npm install -g moxygen
|
||||||
- sudo apt-get -y --force-yes install dfu-util
|
|
||||||
before_script:
|
|
||||||
- avr-gcc --version
|
|
||||||
script:
|
script:
|
||||||
- git rev-parse --short HEAD
|
- git rev-parse --short HEAD
|
||||||
- bash util/travis_test.sh
|
- bash util/travis_test.sh
|
||||||
- bash util/travis_build.sh
|
- bash util/travis_build.sh
|
||||||
- bash util/travis_docs.sh
|
- bash util/travis_docs.sh
|
||||||
addons:
|
addons:
|
||||||
apt:
|
apt:
|
||||||
packages:
|
packages:
|
||||||
- dfu-programmer
|
|
||||||
- pandoc
|
- pandoc
|
||||||
- gcc-arm-none-eabi
|
|
||||||
- binutils-arm-none-eabi
|
|
||||||
- libnewlib-arm-none-eabi
|
|
||||||
- diffutils
|
- diffutils
|
||||||
- dos2unix
|
- dos2unix
|
||||||
- doxygen
|
- doxygen
|
||||||
|
|||||||
+1
-4
@@ -19,11 +19,8 @@ RUN apt-get update && apt-get install --no-install-recommends -y \
|
|||||||
zip \
|
zip \
|
||||||
&& rm -rf /var/lib/apt/lists/*
|
&& rm -rf /var/lib/apt/lists/*
|
||||||
|
|
||||||
ENV KEYBOARD=ergodox_ez
|
|
||||||
ENV KEYMAP=default
|
|
||||||
|
|
||||||
VOLUME /qmk_firmware
|
VOLUME /qmk_firmware
|
||||||
WORKDIR /qmk_firmware
|
WORKDIR /qmk_firmware
|
||||||
COPY . .
|
COPY . .
|
||||||
|
|
||||||
CMD make $KEYBOARD:$KEYMAP
|
CMD make all:default
|
||||||
@@ -38,7 +38,7 @@ or `keymap.c`:
|
|||||||
} else {
|
} else {
|
||||||
tap_code(KC_PGUP);
|
tap_code(KC_PGUP);
|
||||||
}
|
}
|
||||||
} else if (index == 1) { /* Second encoder
|
} else if (index == 1) { /* Second encoder */
|
||||||
if (clockwise) {
|
if (clockwise) {
|
||||||
tap_code(KC_UP);
|
tap_code(KC_UP);
|
||||||
} else {
|
} else {
|
||||||
|
|||||||
@@ -12,11 +12,17 @@ Within the folder `users` is a directory for each user. This is a place for user
|
|||||||
|
|
||||||
### Keyboard Project Structure
|
### Keyboard Project Structure
|
||||||
|
|
||||||
Within the folder `keyboards` and its subfolder `handwired` is a directory for each keyboard project, for example `qmk_firmware/keyboards/clueboard`. Within it you'll find the following structure:
|
Within the folder `keyboards`, its subfolder `handwired` and its vendor and manufacture subdirectories e.g. `clueboard` is a directory for each keyboard project, for example `qmk_firmware/keyboards/clueboard/2x1800`. Within it, you'll find the following structure:
|
||||||
|
|
||||||
* `keymaps/`: Different keymaps that can be built
|
* `keymaps/`: Different keymaps that can be built
|
||||||
* `rules.mk`: The file that sets the default "make" options. Do not edit this file directly, instead use a keymap specific `rules.mk`.
|
* `rules.mk`: The file that sets the default "make" options. Do not edit this file directly, instead use a keymap specific `rules.mk`.
|
||||||
* `config.h`: The file that sets the default compile time options. Do not edit this file directly, instead use a keymap specific `config.h`.
|
* `config.h`: The file that sets the default compile time options. Do not edit this file directly, instead use a keymap specific `config.h`.
|
||||||
|
* `info.json`: The file used for setting layout for QMK Configurator. See [Configurator Support](reference_configurator_support.md) for more information.
|
||||||
|
* `readme.md`: A brief overview of the keyboard.
|
||||||
|
* `<keyboardName>.h`: This file is where the keyboard layout is defined against the keyboard's switch matrix.
|
||||||
|
* `<keyboardName>.c`: This file is where you can find custom code for the keyboard.
|
||||||
|
|
||||||
|
For more information on project structure, see [QMK Keyboard Guidelines](hardware_keyboard_guidelines.md).
|
||||||
|
|
||||||
### Keymap Structure
|
### Keymap Structure
|
||||||
|
|
||||||
|
|||||||
+24
-5
@@ -65,11 +65,30 @@ By default the I2C1 hardware driver is assumed to be used. If another hardware d
|
|||||||
|
|
||||||
STM32 MCUs allows a variety of pins to be configured as I2C pins depending on the hardware driver used. By default B6 and B7 are set to I2C. You can use these defines to set your i2c pins:
|
STM32 MCUs allows a variety of pins to be configured as I2C pins depending on the hardware driver used. By default B6 and B7 are set to I2C. You can use these defines to set your i2c pins:
|
||||||
|
|
||||||
| Variable | Description | Default |
|
| Variable | Description | Default |
|
||||||
|-------------|----------------------------------------------|---------|
|
|--------------------------|----------------------------------------------------------------------------------------------|---------|
|
||||||
| `I2C1_BANK` | The bank of pins (`GPIOA`, `GPIOB`, `GPIOC`) | `GPIOB` |
|
| `I2C1_SCL_BANK` | The bank of pins (`GPIOA`, `GPIOB`, `GPIOC`) to use for SCL | `GPIOB` |
|
||||||
| `I2C1_SCL` | The pin number for the SCL pin (0-9) | `6` |
|
| `I2C1_SDA_BANK` | The bank of pins (`GPIOA`, `GPIOB`, `GPIOC`) to use for SDA | `GPIOB` |
|
||||||
| `I2C1_SDA` | The pin number for the SDA pin (0-9) | `7` |
|
| `I2C1_SCL` | The pin number for the SCL pin (0-9) | `6` |
|
||||||
|
| `I2C1_SDA` | The pin number for the SDA pin (0-9) | `7` |
|
||||||
|
| `I2C1_BANK` (deprecated) | The bank of pins (`GPIOA`, `GPIOB`, `GPIOC`), superceded by `I2C1_SCL_BANK`, `I2C1_SDA_BANK` | `GPIOB` |
|
||||||
|
|
||||||
|
STM32 MCUs allow for different timing parameters when configuring I2C. These can be modified using the following parameters, using https://www.st.com/en/embedded-software/stsw-stm32126.html as a reference:
|
||||||
|
|
||||||
|
| Variable | Default |
|
||||||
|
|-----------------------|---------|
|
||||||
|
| `I2C1_TIMINGR_PRESC` | `15U` |
|
||||||
|
| `I2C1_TIMINGR_SCLDEL` | `4U` |
|
||||||
|
| `I2C1_TIMINGR_SDADEL` | `2U` |
|
||||||
|
| `I2C1_TIMINGR_SCLH` | `15U` |
|
||||||
|
| `I2C1_TIMINGR_SCLL` | `21U` |
|
||||||
|
|
||||||
|
STM32 MCUs allow for different "alternate function" modes when configuring GPIO pins. These are required to switch the pins used to I2C mode. See the respective datasheet for the appropriate values for your MCU.
|
||||||
|
|
||||||
|
| Variable | Default |
|
||||||
|
|---------------------|---------|
|
||||||
|
| `I2C1_SCL_PAL_MODE` | `4` |
|
||||||
|
| `I2C1_SDA_PAL_MODE` | `4` |
|
||||||
|
|
||||||
You can also overload the `void i2c_init(void)` function, which has a weak attribute. If you do this the configuration variables above will not be used. Please consult the datasheet of your MCU for the available GPIO configurations. The following is an example initialization function:
|
You can also overload the `void i2c_init(void)` function, which has a weak attribute. If you do this the configuration variables above will not be used. Please consult the datasheet of your MCU for the available GPIO configurations. The following is an example initialization function:
|
||||||
|
|
||||||
|
|||||||
@@ -89,7 +89,7 @@ Once the layout is as desired, move to the Raw Data tab in KLE, and copy the con
|
|||||||
|
|
||||||
To convert this data into our JSON, go to the [QMK KLE-JSON Converter](https://qmk.fm/converter/), paste the Raw Data into the Input field, and click the Convert button. After a moment, our JSON data will appear in the Output field. Copy the contents to a new text document, and name the document `info.json`, saving it in the same folder that contains `numpad.h`.
|
||||||
|
|
||||||
Use the `keyboard_name` object to set the name of the keyboard. The `bootloader` object is deprecated, so it can be deleted. For instruction purposes, we will put each key's object on its own line. This is only to make the file more human-readable, and does not affect the Configurator's functionality.
|
Use the `keyboard_name` object to set the name of the keyboard. For instruction purposes, we will put each key's object on its own line. This is only to make the file more human-readable, and does not affect the Configurator's functionality.
|
||||||
|
|
||||||
```json
|
```json
|
||||||
{
|
{
|
||||||
|
|||||||
@@ -32,12 +32,10 @@
|
|||||||
|
|
||||||
static uint8_t i2c_address;
|
static uint8_t i2c_address;
|
||||||
|
|
||||||
// This configures the I2C clock to 400khz assuming a 72Mhz clock
|
|
||||||
// For more info : https://www.st.com/en/embedded-software/stsw-stm32126.html
|
|
||||||
static const I2CConfig i2cconfig = {
|
static const I2CConfig i2cconfig = {
|
||||||
STM32_TIMINGR_PRESC(15U) |
|
STM32_TIMINGR_PRESC(I2C1_TIMINGR_PRESC) |
|
||||||
STM32_TIMINGR_SCLDEL(4U) | STM32_TIMINGR_SDADEL(2U) |
|
STM32_TIMINGR_SCLDEL(I2C1_TIMINGR_SCLDEL) | STM32_TIMINGR_SDADEL(I2C1_TIMINGR_SDADEL) |
|
||||||
STM32_TIMINGR_SCLH(15U) | STM32_TIMINGR_SCLL(21U),
|
STM32_TIMINGR_SCLH(I2C1_TIMINGR_SCLH) | STM32_TIMINGR_SCLL(I2C1_TIMINGR_SCLL),
|
||||||
0,
|
0,
|
||||||
0
|
0
|
||||||
};
|
};
|
||||||
@@ -58,13 +56,13 @@ __attribute__ ((weak))
|
|||||||
void i2c_init(void)
|
void i2c_init(void)
|
||||||
{
|
{
|
||||||
// Try releasing special pins for a short time
|
// Try releasing special pins for a short time
|
||||||
palSetPadMode(I2C1_BANK, I2C1_SCL, PAL_MODE_INPUT);
|
palSetPadMode(I2C1_SCL_BANK, I2C1_SCL, PAL_MODE_INPUT);
|
||||||
palSetPadMode(I2C1_BANK, I2C1_SDA, PAL_MODE_INPUT);
|
palSetPadMode(I2C1_SDA_BANK, I2C1_SDA, PAL_MODE_INPUT);
|
||||||
|
|
||||||
chThdSleepMilliseconds(10);
|
chThdSleepMilliseconds(10);
|
||||||
|
|
||||||
palSetPadMode(I2C1_BANK, I2C1_SCL, PAL_MODE_ALTERNATE(4) | PAL_STM32_OTYPE_OPENDRAIN);
|
palSetPadMode(I2C1_SCL_BANK, I2C1_SCL, PAL_MODE_ALTERNATE(I2C1_SCL_PAL_MODE) | PAL_STM32_OTYPE_OPENDRAIN);
|
||||||
palSetPadMode(I2C1_BANK, I2C1_SDA, PAL_MODE_ALTERNATE(4) | PAL_STM32_OTYPE_OPENDRAIN);
|
palSetPadMode(I2C1_SDA_BANK, I2C1_SDA, PAL_MODE_ALTERNATE(I2C1_SDA_PAL_MODE) | PAL_STM32_OTYPE_OPENDRAIN);
|
||||||
|
|
||||||
//i2cInit(); //This is invoked by halInit() so no need to redo it.
|
//i2cInit(); //This is invoked by halInit() so no need to redo it.
|
||||||
}
|
}
|
||||||
|
|||||||
@@ -26,9 +26,19 @@
|
|||||||
#include "ch.h"
|
#include "ch.h"
|
||||||
#include <hal.h>
|
#include <hal.h>
|
||||||
|
|
||||||
#ifndef I2C1_BANK
|
#ifdef I2C1_BANK
|
||||||
#define I2C1_BANK GPIOB
|
#define I2C1_SCL_BANK I2C1_BANK
|
||||||
|
#define I2C1_SDA_BANK I2C1_BANK
|
||||||
#endif
|
#endif
|
||||||
|
|
||||||
|
#ifndef I2C1_SCL_BANK
|
||||||
|
#define I2C1_SCL_BANK GPIOB
|
||||||
|
#endif
|
||||||
|
|
||||||
|
#ifndef I2C1_SDA_BANK
|
||||||
|
#define I2C1_SDA_BANK GPIOB
|
||||||
|
#endif
|
||||||
|
|
||||||
#ifndef I2C1_SCL
|
#ifndef I2C1_SCL
|
||||||
#define I2C1_SCL 6
|
#define I2C1_SCL 6
|
||||||
#endif
|
#endif
|
||||||
@@ -36,6 +46,32 @@
|
|||||||
#define I2C1_SDA 7
|
#define I2C1_SDA 7
|
||||||
#endif
|
#endif
|
||||||
|
|
||||||
|
// The default PAL alternate modes are used to signal that the pins are used for I2C
|
||||||
|
#ifndef I2C1_SCL_PAL_MODE
|
||||||
|
#define I2C1_SCL_PAL_MODE 4
|
||||||
|
#endif
|
||||||
|
#ifndef I2C1_SDA_PAL_MODE
|
||||||
|
#define I2C1_SDA_PAL_MODE 4
|
||||||
|
#endif
|
||||||
|
|
||||||
|
// The default timing values below configures the I2C clock to 400khz assuming a 72Mhz clock
|
||||||
|
// For more info : https://www.st.com/en/embedded-software/stsw-stm32126.html
|
||||||
|
#ifndef I2C1_TIMINGR_PRESC
|
||||||
|
#define I2C1_TIMINGR_PRESC 15U
|
||||||
|
#endif
|
||||||
|
#ifndef I2C1_TIMINGR_SCLDEL
|
||||||
|
#define I2C1_TIMINGR_SCLDEL 4U
|
||||||
|
#endif
|
||||||
|
#ifndef I2C1_TIMINGR_SDADEL
|
||||||
|
#define I2C1_TIMINGR_SDADEL 2U
|
||||||
|
#endif
|
||||||
|
#ifndef I2C1_TIMINGR_SCLH
|
||||||
|
#define I2C1_TIMINGR_SCLH 15U
|
||||||
|
#endif
|
||||||
|
#ifndef I2C1_TIMINGR_SCLL
|
||||||
|
#define I2C1_TIMINGR_SCLL 21U
|
||||||
|
#endif
|
||||||
|
|
||||||
#ifndef I2C_DRIVER
|
#ifndef I2C_DRIVER
|
||||||
#define I2C_DRIVER I2CD1
|
#define I2C_DRIVER I2CD1
|
||||||
#endif
|
#endif
|
||||||
|
|||||||
@@ -0,0 +1 @@
|
|||||||
|
#include "8pack.h"
|
||||||
@@ -0,0 +1,11 @@
|
|||||||
|
#pragma once
|
||||||
|
|
||||||
|
#include "quantum.h"
|
||||||
|
|
||||||
|
#ifdef KEYBOARD_8pack_rev11
|
||||||
|
#include "rev11.h"
|
||||||
|
#endif
|
||||||
|
|
||||||
|
#ifdef KEYBOARD_8pack_rev12
|
||||||
|
#include "rev12.h"
|
||||||
|
#endif
|
||||||
@@ -0,0 +1,39 @@
|
|||||||
|
#pragma once
|
||||||
|
|
||||||
|
#include "config_common.h"
|
||||||
|
|
||||||
|
/* USB Device descriptor parameter */
|
||||||
|
#define VENDOR_ID 0xFEED
|
||||||
|
#define PRODUCT_ID 0x2171
|
||||||
|
#define MANUFACTURER Charles Garcia
|
||||||
|
#define PRODUCT 8-Pack
|
||||||
|
|
||||||
|
/* COL2ROW or ROW2COL */
|
||||||
|
#define DIODE_DIRECTION COL2ROW
|
||||||
|
|
||||||
|
/* Set 0 if debouncing isn't needed */
|
||||||
|
#define DEBOUNCE 5
|
||||||
|
|
||||||
|
/* Mechanical locking support. Use KC_LCAP, KC_LNUM or KC_LSCR instead in keymap */
|
||||||
|
#define LOCKING_SUPPORT_ENABLE
|
||||||
|
|
||||||
|
/* Locking resynchronize hack */
|
||||||
|
#define LOCKING_RESYNC_ENABLE
|
||||||
|
|
||||||
|
/* key matrix size */
|
||||||
|
#define MATRIX_ROWS 2
|
||||||
|
#define MATRIX_COLS 4
|
||||||
|
|
||||||
|
/* key matrix pins */
|
||||||
|
|
||||||
|
#define DIRECT_PINS { { F4, F5, F6, F7 }, { B1, B3, B2, B6 } }
|
||||||
|
|
||||||
|
#define BACKLIGHT_LED_COUNT 8
|
||||||
|
#undef BACKLIGHT_PIN
|
||||||
|
#define BACKLIGHT_PINS { D1, D0, D4, C6, D7, E6, B4, B5 }
|
||||||
|
#define BACKLIGHT_LEVELS 8
|
||||||
|
|
||||||
|
// ws2812 options
|
||||||
|
#define RGB_DI_PIN D2 // pin the DI on the ws2812 is hooked-up to
|
||||||
|
#define RGBLED_NUM 8 // number of LEDs
|
||||||
|
#define RGBLIGHT_ANIMATIONS
|
||||||
@@ -0,0 +1,21 @@
|
|||||||
|
{
|
||||||
|
"keyboard_name": "8-Pack",
|
||||||
|
"url": "https://github.com/cgarcia2097/8-Pack",
|
||||||
|
"maintainer": "Charles Garcia",
|
||||||
|
"width": 4,
|
||||||
|
"height": 2,
|
||||||
|
"layouts": {
|
||||||
|
"LAYOUT": {
|
||||||
|
"layout": [
|
||||||
|
{"x":0, "y":0},
|
||||||
|
{"x":1, "y":0},
|
||||||
|
{"x":2, "y":0},
|
||||||
|
{"x":3, "y":0},
|
||||||
|
{"x":0, "y":1},
|
||||||
|
{"x":1, "y":1},
|
||||||
|
{"x":2, "y":1},
|
||||||
|
{"x":3, "y":1}
|
||||||
|
]
|
||||||
|
}
|
||||||
|
}
|
||||||
|
}
|
||||||
@@ -0,0 +1,12 @@
|
|||||||
|
#include QMK_KEYBOARD_H
|
||||||
|
|
||||||
|
const uint16_t PROGMEM keymaps[][MATRIX_ROWS][MATRIX_COLS] = {
|
||||||
|
[0] = LAYOUT(
|
||||||
|
KC_V, KC_C, KC_X, MO(1),
|
||||||
|
KC_A, KC_S, KC_D, KC_F
|
||||||
|
),
|
||||||
|
[1] = LAYOUT(
|
||||||
|
RGB_TOG, RGB_RMOD, RGB_MOD, KC_NO,
|
||||||
|
RESET, BL_DEC, BL_INC, BL_TOGG
|
||||||
|
)
|
||||||
|
};
|
||||||
@@ -0,0 +1,13 @@
|
|||||||
|
# 8-Pack Macropad
|
||||||
|
|
||||||
|
An open source 2x4 macropad designed by Charles Garcia.
|
||||||
|
|
||||||
|
Keyboard Maintainer: [Charles Garcia](https://github.com/cgarcia2097)
|
||||||
|
Hardware Supported: 8-Pack Macropad PCB
|
||||||
|
Hardware Availability: [8-Pack Github](https://github.com/cgarcia2097/8-Pack)
|
||||||
|
|
||||||
|
Make example for this keyboard (after setting up your build environment):
|
||||||
|
|
||||||
|
make 8pack:default
|
||||||
|
|
||||||
|
See the [build environment setup](https://docs.qmk.fm/#/getting_started_build_tools) and the [make instructions](https://docs.qmk.fm/#/getting_started_make_guide) for more information. Brand new to QMK? Start with our [Complete Newbs Guide](https://docs.qmk.fm/#/newbs).
|
||||||
@@ -0,0 +1,3 @@
|
|||||||
|
#pragma once
|
||||||
|
|
||||||
|
#define DEVICE_VER 0x0001
|
||||||
@@ -0,0 +1 @@
|
|||||||
|
#include "rev11.h"
|
||||||
@@ -0,0 +1,11 @@
|
|||||||
|
#pragma once
|
||||||
|
|
||||||
|
#include "8pack.h"
|
||||||
|
|
||||||
|
#define LAYOUT( \
|
||||||
|
K00, K01, K02, K03, \
|
||||||
|
K10, K11, K12, K13 \
|
||||||
|
) { \
|
||||||
|
{ K13, K12, K11, K10 }, \
|
||||||
|
{ K03, K02, K01, K00 } \
|
||||||
|
}
|
||||||
Whitespace-only changes.
@@ -0,0 +1,3 @@
|
|||||||
|
#pragma once
|
||||||
|
|
||||||
|
#define DEVICE_VER 0x0002
|
||||||
@@ -0,0 +1 @@
|
|||||||
|
#include "rev12.h"
|
||||||
@@ -0,0 +1,11 @@
|
|||||||
|
#pragma once
|
||||||
|
|
||||||
|
#include "8pack.h"
|
||||||
|
|
||||||
|
#define LAYOUT( \
|
||||||
|
K00, K01, K02, K03, \
|
||||||
|
K10, K11, K12, K13 \
|
||||||
|
) { \
|
||||||
|
{ K03, K02, K01, K00 }, \
|
||||||
|
{ K13, K12, K11, K10 } \
|
||||||
|
}
|
||||||
Whitespace-only changes.
@@ -0,0 +1,63 @@
|
|||||||
|
# MCU name
|
||||||
|
MCU = atmega32u4
|
||||||
|
|
||||||
|
# Processor frequency.
|
||||||
|
# This will define a symbol, F_CPU, in all source code files equal to the
|
||||||
|
# processor frequency in Hz. You can then use this symbol in your source code to
|
||||||
|
# calculate timings. Do NOT tack on a 'UL' at the end, this will be done
|
||||||
|
# automatically to create a 32-bit value in your source code.
|
||||||
|
#
|
||||||
|
# This will be an integer division of F_USB below, as it is sourced by
|
||||||
|
# F_USB after it has run through any CPU prescalers. Note that this value
|
||||||
|
# does not *change* the processor frequency - it should merely be updated to
|
||||||
|
# reflect the processor speed set externally so that the code can use accurate
|
||||||
|
# software delays.
|
||||||
|
F_CPU = 16000000
|
||||||
|
|
||||||
|
#
|
||||||
|
# LUFA specific
|
||||||
|
#
|
||||||
|
# Target architecture (see library "Board Types" documentation).
|
||||||
|
ARCH = AVR8
|
||||||
|
|
||||||
|
# Input clock frequency.
|
||||||
|
# This will define a symbol, F_USB, in all source code files equal to the
|
||||||
|
# input clock frequency (before any prescaling is performed) in Hz. This value may
|
||||||
|
# differ from F_CPU if prescaling is used on the latter, and is required as the
|
||||||
|
# raw input clock is fed directly to the PLL sections of the AVR for high speed
|
||||||
|
# clock generation for the USB and other AVR subsections. Do NOT tack on a 'UL'
|
||||||
|
# at the end, this will be done automatically to create a 32-bit value in your
|
||||||
|
# source code.
|
||||||
|
#
|
||||||
|
# If no clock division is performed on the input clock inside the AVR (via the
|
||||||
|
# CPU clock adjust registers or the clock division fuses), this will be equal to F_CPU.
|
||||||
|
F_USB = $(F_CPU)
|
||||||
|
|
||||||
|
# Interrupt driven control endpoint task(+60)
|
||||||
|
OPT_DEFS += -DINTERRUPT_CONTROL_ENDPOINT
|
||||||
|
|
||||||
|
# Bootloader selection
|
||||||
|
# Teensy halfkay
|
||||||
|
# Pro Micro caterina
|
||||||
|
# Atmel DFU atmel-dfu
|
||||||
|
# LUFA DFU lufa-dfu
|
||||||
|
# QMK DFU qmk-dfu
|
||||||
|
# atmega32a bootloadHID
|
||||||
|
BOOTLOADER = caterina
|
||||||
|
|
||||||
|
# Build Options
|
||||||
|
# comment out to disable the options.
|
||||||
|
#
|
||||||
|
BOOTMAGIC_ENABLE = no # Virtual DIP switch configuration(+1000)
|
||||||
|
MOUSEKEY_ENABLE = no # Mouse keys(+4700)
|
||||||
|
EXTRAKEY_ENABLE = no # Audio control and System control(+450)
|
||||||
|
CONSOLE_ENABLE = yes # Console for debug(+400)
|
||||||
|
COMMAND_ENABLE = yes # Commands for debug and configuration
|
||||||
|
SLEEP_LED_ENABLE = no # Breathing sleep LED during USB suspend
|
||||||
|
NKRO_ENABLE = no # USB Nkey Rollover - if this doesn't work, see here: https://github.com/tmk/tmk_keyboard/wiki/FAQ#nkro-doesnt-work
|
||||||
|
BACKLIGHT_ENABLE = yes # Enable keyboard backlight functionality
|
||||||
|
AUDIO_ENABLE = no
|
||||||
|
RGBLIGHT_ENABLE = yes
|
||||||
|
OLED_DRIVER_ENABLE = no
|
||||||
|
|
||||||
|
DEFAULT_FOLDER = 8pack/rev12
|
||||||
@@ -0,0 +1,245 @@
|
|||||||
|
/*
|
||||||
|
Copyright 2019 Ryota Goto
|
||||||
|
|
||||||
|
This program is free software: you can redistribute it and/or modify
|
||||||
|
it under the terms of the GNU General Public License as published by
|
||||||
|
the Free Software Foundation, either version 2 of the License, or
|
||||||
|
(at your option) any later version.
|
||||||
|
|
||||||
|
This program is distributed in the hope that it will be useful,
|
||||||
|
but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
GNU General Public License for more details.
|
||||||
|
|
||||||
|
You should have received a copy of the GNU General Public License
|
||||||
|
along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
|
||||||
|
#pragma once
|
||||||
|
|
||||||
|
#include "config_common.h"
|
||||||
|
|
||||||
|
/* USB Device descriptor parameter */
|
||||||
|
#define VENDOR_ID 0xA103
|
||||||
|
#define PRODUCT_ID 0x0004
|
||||||
|
#define DEVICE_VER 0x0001
|
||||||
|
#define MANUFACTURER ai03 Design Studio
|
||||||
|
#define PRODUCT Soyuz
|
||||||
|
#define DESCRIPTION Single-PCB Numpad Kit
|
||||||
|
|
||||||
|
/* key matrix size */
|
||||||
|
#define MATRIX_ROWS 5
|
||||||
|
#define MATRIX_COLS 4
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Keyboard Matrix Assignments
|
||||||
|
*
|
||||||
|
* Change this to how you wired your keyboard
|
||||||
|
* COLS: AVR pins used for columns, left to right
|
||||||
|
* ROWS: AVR pins used for rows, top to bottom
|
||||||
|
* DIODE_DIRECTION: COL2ROW = COL = Anode (+), ROW = Cathode (-, marked on diode)
|
||||||
|
* ROW2COL = ROW = Anode (+), COL = Cathode (-, marked on diode)
|
||||||
|
*
|
||||||
|
*/
|
||||||
|
#define MATRIX_ROW_PINS { D4, C6, B6, E6, B4 }
|
||||||
|
#define MATRIX_COL_PINS { F4, B3, D7, B5 }
|
||||||
|
#define UNUSED_PINS
|
||||||
|
|
||||||
|
/* COL2ROW, ROW2COL*/
|
||||||
|
#define DIODE_DIRECTION COL2ROW
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Split Keyboard specific options, make sure you have 'SPLIT_KEYBOARD = yes' in your rules.mk, and define SOFT_SERIAL_PIN.
|
||||||
|
*/
|
||||||
|
#define SOFT_SERIAL_PIN D0 // or D1, D2, D3, E6
|
||||||
|
|
||||||
|
// #define BACKLIGHT_PIN B7
|
||||||
|
// #define BACKLIGHT_BREATHING
|
||||||
|
// #define BACKLIGHT_LEVELS 3
|
||||||
|
|
||||||
|
// #define RGB_DI_PIN E2
|
||||||
|
// #ifdef RGB_DI_PIN
|
||||||
|
// #define RGBLED_NUM 16
|
||||||
|
// #define RGBLIGHT_HUE_STEP 8
|
||||||
|
// #define RGBLIGHT_SAT_STEP 8
|
||||||
|
// #define RGBLIGHT_VAL_STEP 8
|
||||||
|
// #define RGBLIGHT_LIMIT_VAL 255 /* The maximum brightness level */
|
||||||
|
// #define RGBLIGHT_SLEEP /* If defined, the RGB lighting will be switched off when the host goes to sleep */
|
||||||
|
// /*== all animations enable ==*/
|
||||||
|
// #define RGBLIGHT_ANIMATIONS
|
||||||
|
// /*== or choose animations ==*/
|
||||||
|
// #define RGBLIGHT_EFFECT_BREATHING
|
||||||
|
// #define RGBLIGHT_EFFECT_RAINBOW_MOOD
|
||||||
|
// #define RGBLIGHT_EFFECT_RAINBOW_SWIRL
|
||||||
|
// #define RGBLIGHT_EFFECT_SNAKE
|
||||||
|
// #define RGBLIGHT_EFFECT_KNIGHT
|
||||||
|
// #define RGBLIGHT_EFFECT_CHRISTMAS
|
||||||
|
// #define RGBLIGHT_EFFECT_STATIC_GRADIENT
|
||||||
|
// #define RGBLIGHT_EFFECT_RGB_TEST
|
||||||
|
// #define RGBLIGHT_EFFECT_ALTERNATING
|
||||||
|
// #endif
|
||||||
|
|
||||||
|
/* Debounce reduces chatter (unintended double-presses) - set 0 if debouncing is not needed */
|
||||||
|
#define DEBOUNCE 5
|
||||||
|
|
||||||
|
/* define if matrix has ghost (lacks anti-ghosting diodes) */
|
||||||
|
//#define MATRIX_HAS_GHOST
|
||||||
|
|
||||||
|
/* number of backlight levels */
|
||||||
|
|
||||||
|
/* Mechanical locking support. Use KC_LCAP, KC_LNUM or KC_LSCR instead in keymap */
|
||||||
|
#define LOCKING_SUPPORT_ENABLE
|
||||||
|
/* Locking resynchronize hack */
|
||||||
|
#define LOCKING_RESYNC_ENABLE
|
||||||
|
|
||||||
|
/* If defined, GRAVE_ESC will always act as ESC when CTRL is held.
|
||||||
|
* This is userful for the Windows task manager shortcut (ctrl+shift+esc).
|
||||||
|
*/
|
||||||
|
// #define GRAVE_ESC_CTRL_OVERRIDE
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Force NKRO
|
||||||
|
*
|
||||||
|
* Force NKRO (nKey Rollover) to be enabled by default, regardless of the saved
|
||||||
|
* state in the bootmagic EEPROM settings. (Note that NKRO must be enabled in the
|
||||||
|
* makefile for this to work.)
|
||||||
|
*
|
||||||
|
* If forced on, NKRO can be disabled via magic key (default = LShift+RShift+N)
|
||||||
|
* until the next keyboard reset.
|
||||||
|
*
|
||||||
|
* NKRO may prevent your keystrokes from being detected in the BIOS, but it is
|
||||||
|
* fully operational during normal computer usage.
|
||||||
|
*
|
||||||
|
* For a less heavy-handed approach, enable NKRO via magic key (LShift+RShift+N)
|
||||||
|
* or via bootmagic (hold SPACE+N while plugging in the keyboard). Once set by
|
||||||
|
* bootmagic, NKRO mode will always be enabled until it is toggled again during a
|
||||||
|
* power-up.
|
||||||
|
*
|
||||||
|
*/
|
||||||
|
//#define FORCE_NKRO
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Magic Key Options
|
||||||
|
*
|
||||||
|
* Magic keys are hotkey commands that allow control over firmware functions of
|
||||||
|
* the keyboard. They are best used in combination with the HID Listen program,
|
||||||
|
* found here: https://www.pjrc.com/teensy/hid_listen.html
|
||||||
|
*
|
||||||
|
* The options below allow the magic key functionality to be changed. This is
|
||||||
|
* useful if your keyboard/keypad is missing keys and you want magic key support.
|
||||||
|
*
|
||||||
|
*/
|
||||||
|
|
||||||
|
/* key combination for magic key command */
|
||||||
|
/* defined by default; to change, uncomment and set to the combination you want */
|
||||||
|
// #define IS_COMMAND() (get_mods() == (MOD_BIT(KC_LSHIFT) | MOD_BIT(KC_RSHIFT)))
|
||||||
|
|
||||||
|
/* control how magic key switches layers */
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_FKEYS true
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_NKEYS true
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_CUSTOM false
|
||||||
|
|
||||||
|
/* override magic key keymap */
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_FKEYS
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_NKEYS
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_CUSTOM
|
||||||
|
//#define MAGIC_KEY_HELP H
|
||||||
|
//#define MAGIC_KEY_HELP_ALT SLASH
|
||||||
|
//#define MAGIC_KEY_DEBUG D
|
||||||
|
//#define MAGIC_KEY_DEBUG_MATRIX X
|
||||||
|
//#define MAGIC_KEY_DEBUG_KBD K
|
||||||
|
//#define MAGIC_KEY_DEBUG_MOUSE M
|
||||||
|
//#define MAGIC_KEY_VERSION V
|
||||||
|
//#define MAGIC_KEY_STATUS S
|
||||||
|
//#define MAGIC_KEY_CONSOLE C
|
||||||
|
//#define MAGIC_KEY_LAYER0 0
|
||||||
|
//#define MAGIC_KEY_LAYER0_ALT GRAVE
|
||||||
|
//#define MAGIC_KEY_LAYER1 1
|
||||||
|
//#define MAGIC_KEY_LAYER2 2
|
||||||
|
//#define MAGIC_KEY_LAYER3 3
|
||||||
|
//#define MAGIC_KEY_LAYER4 4
|
||||||
|
//#define MAGIC_KEY_LAYER5 5
|
||||||
|
//#define MAGIC_KEY_LAYER6 6
|
||||||
|
//#define MAGIC_KEY_LAYER7 7
|
||||||
|
//#define MAGIC_KEY_LAYER8 8
|
||||||
|
//#define MAGIC_KEY_LAYER9 9
|
||||||
|
//#define MAGIC_KEY_BOOTLOADER B
|
||||||
|
//#define MAGIC_KEY_BOOTLOADER_ALT ESC
|
||||||
|
//#define MAGIC_KEY_LOCK CAPS
|
||||||
|
//#define MAGIC_KEY_EEPROM E
|
||||||
|
//#define MAGIC_KEY_EEPROM_CLEAR BSPACE
|
||||||
|
//#define MAGIC_KEY_NKRO N
|
||||||
|
//#define MAGIC_KEY_SLEEP_LED Z
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Feature disable options
|
||||||
|
* These options are also useful to firmware size reduction.
|
||||||
|
*/
|
||||||
|
|
||||||
|
/* disable debug print */
|
||||||
|
//#define NO_DEBUG
|
||||||
|
|
||||||
|
/* disable print */
|
||||||
|
//#define NO_PRINT
|
||||||
|
|
||||||
|
/* disable action features */
|
||||||
|
//#define NO_ACTION_LAYER
|
||||||
|
//#define NO_ACTION_TAPPING
|
||||||
|
//#define NO_ACTION_ONESHOT
|
||||||
|
//#define NO_ACTION_MACRO
|
||||||
|
//#define NO_ACTION_FUNCTION
|
||||||
|
|
||||||
|
/*
|
||||||
|
* MIDI options
|
||||||
|
*/
|
||||||
|
|
||||||
|
/* Prevent use of disabled MIDI features in the keymap */
|
||||||
|
//#define MIDI_ENABLE_STRICT 1
|
||||||
|
|
||||||
|
/* enable basic MIDI features:
|
||||||
|
- MIDI notes can be sent when in Music mode is on
|
||||||
|
*/
|
||||||
|
//#define MIDI_BASIC
|
||||||
|
|
||||||
|
/* enable advanced MIDI features:
|
||||||
|
- MIDI notes can be added to the keymap
|
||||||
|
- Octave shift and transpose
|
||||||
|
- Virtual sustain, portamento, and modulation wheel
|
||||||
|
- etc.
|
||||||
|
*/
|
||||||
|
//#define MIDI_ADVANCED
|
||||||
|
|
||||||
|
/* override number of MIDI tone keycodes (each octave adds 12 keycodes and allocates 12 bytes) */
|
||||||
|
//#define MIDI_TONE_KEYCODE_OCTAVES 1
|
||||||
|
|
||||||
|
/*
|
||||||
|
* HD44780 LCD Display Configuration
|
||||||
|
*/
|
||||||
|
/*
|
||||||
|
#define LCD_LINES 2 //< number of visible lines of the display
|
||||||
|
#define LCD_DISP_LENGTH 16 //< visibles characters per line of the display
|
||||||
|
|
||||||
|
#define LCD_IO_MODE 1 //< 0: memory mapped mode, 1: IO port mode
|
||||||
|
|
||||||
|
#if LCD_IO_MODE
|
||||||
|
#define LCD_PORT PORTB //< port for the LCD lines
|
||||||
|
#define LCD_DATA0_PORT LCD_PORT //< port for 4bit data bit 0
|
||||||
|
#define LCD_DATA1_PORT LCD_PORT //< port for 4bit data bit 1
|
||||||
|
#define LCD_DATA2_PORT LCD_PORT //< port for 4bit data bit 2
|
||||||
|
#define LCD_DATA3_PORT LCD_PORT //< port for 4bit data bit 3
|
||||||
|
#define LCD_DATA0_PIN 4 //< pin for 4bit data bit 0
|
||||||
|
#define LCD_DATA1_PIN 5 //< pin for 4bit data bit 1
|
||||||
|
#define LCD_DATA2_PIN 6 //< pin for 4bit data bit 2
|
||||||
|
#define LCD_DATA3_PIN 7 //< pin for 4bit data bit 3
|
||||||
|
#define LCD_RS_PORT LCD_PORT //< port for RS line
|
||||||
|
#define LCD_RS_PIN 3 //< pin for RS line
|
||||||
|
#define LCD_RW_PORT LCD_PORT //< port for RW line
|
||||||
|
#define LCD_RW_PIN 2 //< pin for RW line
|
||||||
|
#define LCD_E_PORT LCD_PORT //< port for Enable line
|
||||||
|
#define LCD_E_PIN 1 //< pin for Enable line
|
||||||
|
#endif
|
||||||
|
*/
|
||||||
|
|
||||||
|
/* Bootmagic Lite key configuration */
|
||||||
|
// #define BOOTMAGIC_LITE_ROW 0
|
||||||
|
// #define BOOTMAGIC_LITE_COLUMN 0
|
||||||
@@ -0,0 +1,33 @@
|
|||||||
|
{
|
||||||
|
"keyboard_name": "Soyuz",
|
||||||
|
"url": "https://github.com/ai03-2725/soyuz",
|
||||||
|
"maintainer": "ai03",
|
||||||
|
"width": 4,
|
||||||
|
"height": 5,
|
||||||
|
"layouts": {
|
||||||
|
"LAYOUT_ortho_5x4": {
|
||||||
|
"layout": [
|
||||||
|
{"x":0, "y":0},
|
||||||
|
{"x":1, "y":0},
|
||||||
|
{"x":2, "y":0},
|
||||||
|
{"x":3, "y":0},
|
||||||
|
{"x":0, "y":1},
|
||||||
|
{"x":1, "y":1},
|
||||||
|
{"x":2, "y":1},
|
||||||
|
{"x":3, "y":1},
|
||||||
|
{"x":0, "y":2},
|
||||||
|
{"x":1, "y":2},
|
||||||
|
{"x":2, "y":2},
|
||||||
|
{"x":3, "y":2},
|
||||||
|
{"x":0, "y":3},
|
||||||
|
{"x":1, "y":3},
|
||||||
|
{"x":2, "y":3},
|
||||||
|
{"x":3, "y":3},
|
||||||
|
{"x":0, "y":4},
|
||||||
|
{"x":1, "y":4},
|
||||||
|
{"x":2, "y":4},
|
||||||
|
{"x":3, "y":4}
|
||||||
|
]
|
||||||
|
}
|
||||||
|
}
|
||||||
|
}
|
||||||
@@ -0,0 +1,57 @@
|
|||||||
|
/* Copyright 2019 Ryota Goto
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#include QMK_KEYBOARD_H
|
||||||
|
|
||||||
|
// Defines the keycodes used by our macros in process_record_user
|
||||||
|
enum custom_keycodes {
|
||||||
|
DBLZERO = SAFE_RANGE
|
||||||
|
};
|
||||||
|
|
||||||
|
const uint16_t PROGMEM keymaps[][MATRIX_ROWS][MATRIX_COLS] = {
|
||||||
|
[0] = LAYOUT_ortho_5x4( /* Base */
|
||||||
|
KC_NLCK, KC_PSLS, KC_PAST, KC_BSPC, \
|
||||||
|
KC_P7, KC_P8, KC_P9, KC_MINS, \
|
||||||
|
KC_P4, KC_P5, KC_P6, KC_PPLS, \
|
||||||
|
KC_P1, KC_P2, KC_P3, KC_EQL, \
|
||||||
|
DBLZERO, KC_P0, KC_PDOT, KC_PENT \
|
||||||
|
)
|
||||||
|
};
|
||||||
|
|
||||||
|
bool process_record_user(uint16_t keycode, keyrecord_t *record) {
|
||||||
|
switch (keycode) {
|
||||||
|
case DBLZERO:
|
||||||
|
if (record->event.pressed) {
|
||||||
|
// when keycode QMKBEST is pressed
|
||||||
|
SEND_STRING("00");
|
||||||
|
} else {
|
||||||
|
// when keycode QMKBEST is released
|
||||||
|
}
|
||||||
|
break;
|
||||||
|
}
|
||||||
|
return true;
|
||||||
|
}
|
||||||
|
|
||||||
|
void matrix_init_user(void) {
|
||||||
|
|
||||||
|
}
|
||||||
|
|
||||||
|
void matrix_scan_user(void) {
|
||||||
|
|
||||||
|
}
|
||||||
|
|
||||||
|
void led_set_user(uint8_t usb_led) {
|
||||||
|
|
||||||
|
}
|
||||||
@@ -0,0 +1,3 @@
|
|||||||
|
# The 1U keymap for Soyuz
|
||||||
|
|
||||||
|
A keymap that uses 1U keys everywhere for a 20-key numpad.
|
||||||
@@ -0,0 +1,42 @@
|
|||||||
|
/* Copyright 2019 Ryota Goto
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#include QMK_KEYBOARD_H
|
||||||
|
|
||||||
|
const uint16_t PROGMEM keymaps[][MATRIX_ROWS][MATRIX_COLS] = {
|
||||||
|
[0] = LAYOUT_ortho_5x4( /* Base */
|
||||||
|
KC_NLCK, KC_PSLS, KC_PAST, KC_PMNS, \
|
||||||
|
KC_P7, KC_P8, KC_P9, KC_PPLS, \
|
||||||
|
KC_P4, KC_P5, KC_P6, KC_PPLS, \
|
||||||
|
KC_P1, KC_P2, KC_P3, KC_PENT, \
|
||||||
|
KC_P0, KC_P0, KC_PDOT, KC_PENT \
|
||||||
|
)
|
||||||
|
};
|
||||||
|
|
||||||
|
bool process_record_user(uint16_t keycode, keyrecord_t *record) {
|
||||||
|
return true;
|
||||||
|
}
|
||||||
|
|
||||||
|
void matrix_init_user(void) {
|
||||||
|
|
||||||
|
}
|
||||||
|
|
||||||
|
void matrix_scan_user(void) {
|
||||||
|
|
||||||
|
}
|
||||||
|
|
||||||
|
void led_set_user(uint8_t usb_led) {
|
||||||
|
|
||||||
|
}
|
||||||
@@ -0,0 +1,3 @@
|
|||||||
|
# The default keymap for Soyuz
|
||||||
|
|
||||||
|
A very basic keymap for a "typical" numpad layout using 2U keys wherever applicable.
|
||||||
@@ -0,0 +1,15 @@
|
|||||||
|
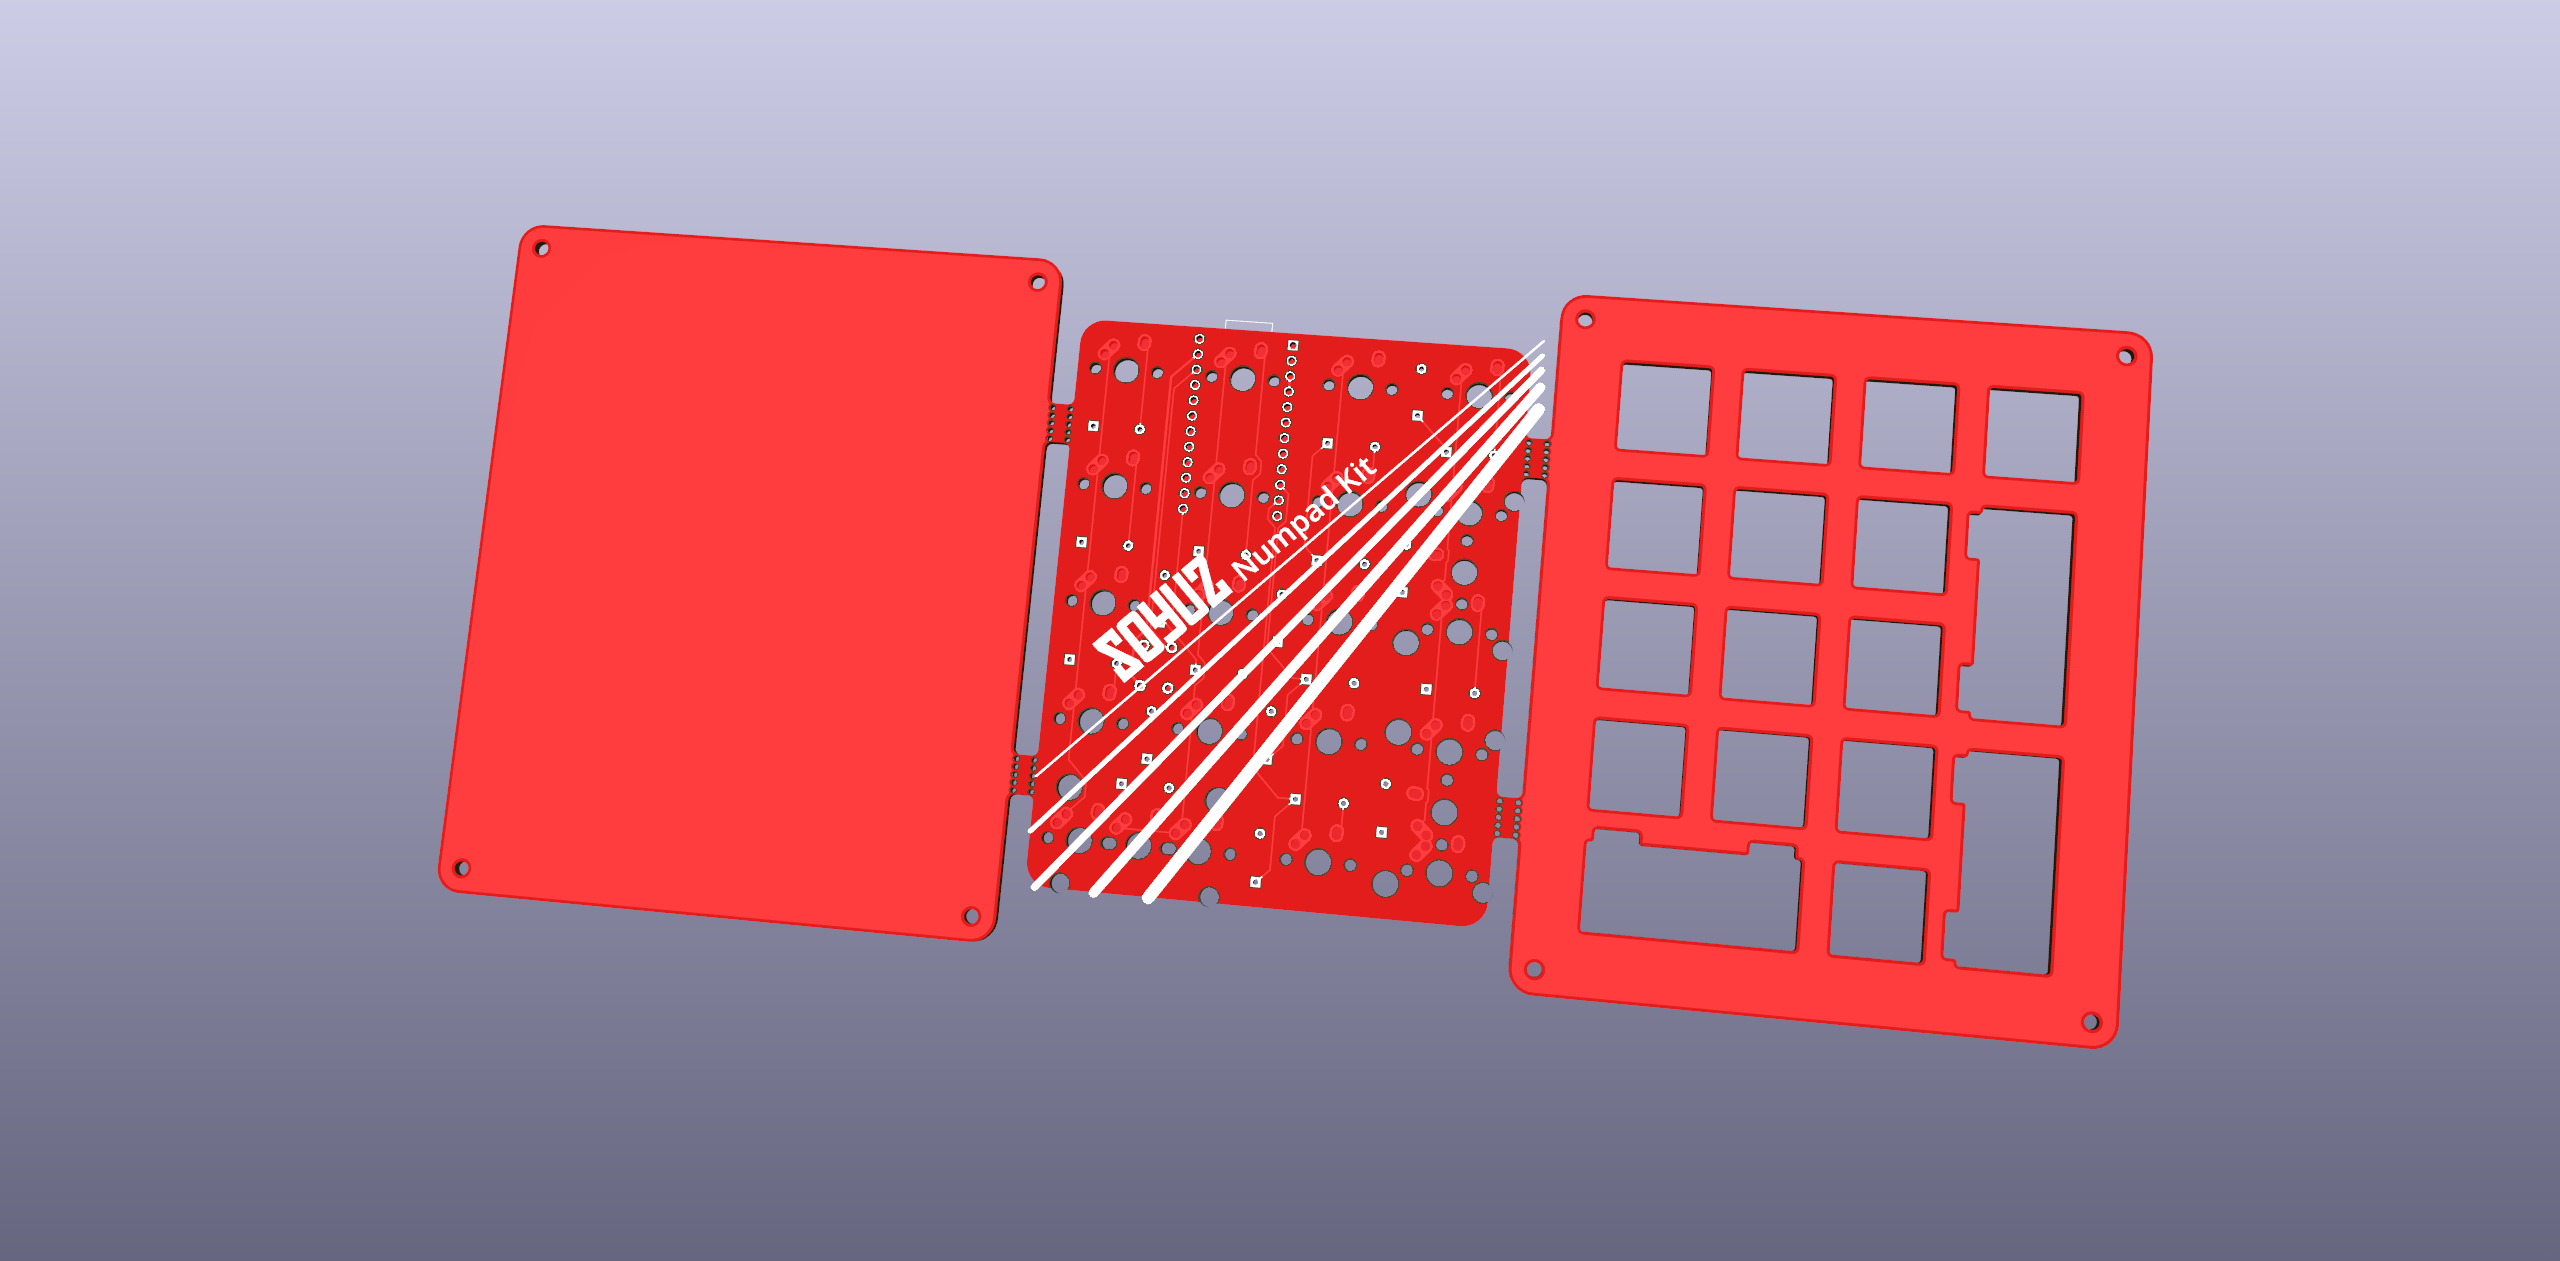
# Soyuz
|
||||||
|
|
||||||
|
|
||||||
|
|
||||||
|
A single-PCB numpad kit
|
||||||
|
|
||||||
|
Keyboard Maintainer: [ai03](https://github.com/ai03-2725)
|
||||||
|
Hardware Supported: [Soyuz PCB](https://github.com/ai03-2725/soyuz)
|
||||||
|
Hardware Availability: Various vendors - List will be maintained in the [PCB repo](https://github.com/ai03-2725/soyuz)
|
||||||
|
|
||||||
|
Make example for this keyboard (after setting up your build environment):
|
||||||
|
|
||||||
|
make ai03/soyuz:default
|
||||||
|
|
||||||
|
See the [build environment setup](https://docs.qmk.fm/#/getting_started_build_tools) and the [make instructions](https://docs.qmk.fm/#/getting_started_make_guide) for more information. Brand new to QMK? Start with our [Complete Newbs Guide](https://docs.qmk.fm/#/newbs).
|
||||||
@@ -0,0 +1,82 @@
|
|||||||
|
# MCU name
|
||||||
|
MCU = atmega32u4
|
||||||
|
|
||||||
|
# Processor frequency.
|
||||||
|
# This will define a symbol, F_CPU, in all source code files equal to the
|
||||||
|
# processor frequency in Hz. You can then use this symbol in your source code to
|
||||||
|
# calculate timings. Do NOT tack on a 'UL' at the end, this will be done
|
||||||
|
# automatically to create a 32-bit value in your source code.
|
||||||
|
#
|
||||||
|
# This will be an integer division of F_USB below, as it is sourced by
|
||||||
|
# F_USB after it has run through any CPU prescalers. Note that this value
|
||||||
|
# does not *change* the processor frequency - it should merely be updated to
|
||||||
|
# reflect the processor speed set externally so that the code can use accurate
|
||||||
|
# software delays.
|
||||||
|
F_CPU = 16000000
|
||||||
|
|
||||||
|
|
||||||
|
#
|
||||||
|
# LUFA specific
|
||||||
|
#
|
||||||
|
# Target architecture (see library "Board Types" documentation).
|
||||||
|
ARCH = AVR8
|
||||||
|
|
||||||
|
# Input clock frequency.
|
||||||
|
# This will define a symbol, F_USB, in all source code files equal to the
|
||||||
|
# input clock frequency (before any prescaling is performed) in Hz. This value may
|
||||||
|
# differ from F_CPU if prescaling is used on the latter, and is required as the
|
||||||
|
# raw input clock is fed directly to the PLL sections of the AVR for high speed
|
||||||
|
# clock generation for the USB and other AVR subsections. Do NOT tack on a 'UL'
|
||||||
|
# at the end, this will be done automatically to create a 32-bit value in your
|
||||||
|
# source code.
|
||||||
|
#
|
||||||
|
# If no clock division is performed on the input clock inside the AVR (via the
|
||||||
|
# CPU clock adjust registers or the clock division fuses), this will be equal to F_CPU.
|
||||||
|
F_USB = $(F_CPU)
|
||||||
|
|
||||||
|
# Interrupt driven control endpoint task(+60)
|
||||||
|
OPT_DEFS += -DINTERRUPT_CONTROL_ENDPOINT
|
||||||
|
|
||||||
|
|
||||||
|
# Bootloader selection
|
||||||
|
# Teensy halfkay
|
||||||
|
# Pro Micro caterina
|
||||||
|
# Atmel DFU atmel-dfu
|
||||||
|
# LUFA DFU lufa-dfu
|
||||||
|
# QMK DFU qmk-dfu
|
||||||
|
# atmega32a bootloadHID
|
||||||
|
BOOTLOADER = atmel-dfu
|
||||||
|
|
||||||
|
|
||||||
|
# If you don't know the bootloader type, then you can specify the
|
||||||
|
# Boot Section Size in *bytes* by uncommenting out the OPT_DEFS line
|
||||||
|
# Teensy halfKay 512
|
||||||
|
# Teensy++ halfKay 1024
|
||||||
|
# Atmel DFU loader 4096
|
||||||
|
# LUFA bootloader 4096
|
||||||
|
# USBaspLoader 2048
|
||||||
|
# OPT_DEFS += -DBOOTLOADER_SIZE=4096
|
||||||
|
|
||||||
|
|
||||||
|
# Build Options
|
||||||
|
# change yes to no to disable
|
||||||
|
#
|
||||||
|
BOOTMAGIC_ENABLE = no # Virtual DIP switch configuration(+1000)
|
||||||
|
MOUSEKEY_ENABLE = yes # Mouse keys(+4700)
|
||||||
|
EXTRAKEY_ENABLE = yes # Audio control and System control(+450)
|
||||||
|
CONSOLE_ENABLE = no # Console for debug(+400)
|
||||||
|
COMMAND_ENABLE = yes # Commands for debug and configuration
|
||||||
|
# Do not enable SLEEP_LED_ENABLE. it uses the same timer as BACKLIGHT_ENABLE
|
||||||
|
SLEEP_LED_ENABLE = no # Breathing sleep LED during USB suspend
|
||||||
|
# if this doesn't work, see here: https://github.com/tmk/tmk_keyboard/wiki/FAQ#nkro-doesnt-work
|
||||||
|
NKRO_ENABLE = yes # USB Nkey Rollover
|
||||||
|
BACKLIGHT_ENABLE = no # Enable keyboard backlight functionality on B7 by default
|
||||||
|
RGBLIGHT_ENABLE = no # Enable keyboard RGB underglow
|
||||||
|
MIDI_ENABLE = no # MIDI support (+2400 to 4200, depending on config)
|
||||||
|
UNICODE_ENABLE = no # Unicode
|
||||||
|
BLUETOOTH_ENABLE = no # Enable Bluetooth with the Adafruit EZ-Key HID
|
||||||
|
AUDIO_ENABLE = no # Audio output on port C6
|
||||||
|
FAUXCLICKY_ENABLE = no # Use buzzer to emulate clicky switches
|
||||||
|
HD44780_ENABLE = no # Enable support for HD44780 based LCDs (+400)
|
||||||
|
|
||||||
|
LAYOUTS = ortho_5x4
|
||||||
@@ -0,0 +1,43 @@
|
|||||||
|
/* Copyright 2019 Ryota Goto
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#include "soyuz.h"
|
||||||
|
|
||||||
|
void matrix_init_kb(void) {
|
||||||
|
// put your keyboard start-up code here
|
||||||
|
// runs once when the firmware starts up
|
||||||
|
|
||||||
|
matrix_init_user();
|
||||||
|
}
|
||||||
|
|
||||||
|
void matrix_scan_kb(void) {
|
||||||
|
// put your looping keyboard code here
|
||||||
|
// runs every cycle (a lot)
|
||||||
|
|
||||||
|
matrix_scan_user();
|
||||||
|
}
|
||||||
|
|
||||||
|
bool process_record_kb(uint16_t keycode, keyrecord_t *record) {
|
||||||
|
// put your per-action keyboard code here
|
||||||
|
// runs for every action, just before processing by the firmware
|
||||||
|
|
||||||
|
return process_record_user(keycode, record);
|
||||||
|
}
|
||||||
|
|
||||||
|
void led_set_kb(uint8_t usb_led) {
|
||||||
|
// put your keyboard LED indicator (ex: Caps Lock LED) toggling code here
|
||||||
|
|
||||||
|
led_set_user(usb_led);
|
||||||
|
}
|
||||||
@@ -0,0 +1,41 @@
|
|||||||
|
/* Copyright 2019 Ryota Goto
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#pragma once
|
||||||
|
|
||||||
|
#include "quantum.h"
|
||||||
|
|
||||||
|
/* This a shortcut to help you visually see your layout.
|
||||||
|
*
|
||||||
|
* The first section contains all of the arguments representing the physical
|
||||||
|
* layout of the board and position of the keys.
|
||||||
|
*
|
||||||
|
* The second converts the arguments into a two-dimensional array which
|
||||||
|
* represents the switch matrix.
|
||||||
|
*/
|
||||||
|
|
||||||
|
#define LAYOUT_ortho_5x4( \
|
||||||
|
K00, K01, K02, K03, \
|
||||||
|
K10, K11, K12, K13, \
|
||||||
|
K20, K21, K22, K23, \
|
||||||
|
K30, K31, K32, K33, \
|
||||||
|
K40, K41, K42, K43 \
|
||||||
|
) { \
|
||||||
|
{ K00, K01, K02, K03 }, \
|
||||||
|
{ K10, K11, K12, K13 }, \
|
||||||
|
{ K20, K21, K22, K23 }, \
|
||||||
|
{ K30, K31, K32, K33 }, \
|
||||||
|
{ K40, K41, K42, K43 } \
|
||||||
|
}
|
||||||
@@ -0,0 +1,51 @@
|
|||||||
|
/* Copyright 2019 kakunpc
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#include "alpha.h"
|
||||||
|
|
||||||
|
// Optional override functions below.
|
||||||
|
// You can leave any or all of these undefined.
|
||||||
|
// These are only required if you want to perform custom actions.
|
||||||
|
|
||||||
|
/*
|
||||||
|
|
||||||
|
void matrix_init_kb(void) {
|
||||||
|
// put your keyboard start-up code here
|
||||||
|
// runs once when the firmware starts up
|
||||||
|
|
||||||
|
matrix_init_user();
|
||||||
|
}
|
||||||
|
|
||||||
|
void matrix_scan_kb(void) {
|
||||||
|
// put your looping keyboard code here
|
||||||
|
// runs every cycle (a lot)
|
||||||
|
|
||||||
|
matrix_scan_user();
|
||||||
|
}
|
||||||
|
|
||||||
|
bool process_record_kb(uint16_t keycode, keyrecord_t *record) {
|
||||||
|
// put your per-action keyboard code here
|
||||||
|
// runs for every action, just before processing by the firmware
|
||||||
|
|
||||||
|
return process_record_user(keycode, record);
|
||||||
|
}
|
||||||
|
|
||||||
|
void led_set_kb(uint8_t usb_led) {
|
||||||
|
// put your keyboard LED indicator (ex: Caps Lock LED) toggling code here
|
||||||
|
|
||||||
|
led_set_user(usb_led);
|
||||||
|
}
|
||||||
|
|
||||||
|
*/
|
||||||
@@ -0,0 +1,35 @@
|
|||||||
|
/* Copyright 2019 kakunpc
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#pragma once
|
||||||
|
|
||||||
|
#include "quantum.h"
|
||||||
|
|
||||||
|
/* This a shortcut to help you visually see your layout.
|
||||||
|
*
|
||||||
|
* The first section contains all of the arguments representing the physical
|
||||||
|
* layout of the board and position of the keys.
|
||||||
|
*
|
||||||
|
* The second converts the arguments into a two-dimensional array which
|
||||||
|
* represents the switch matrix.
|
||||||
|
*/
|
||||||
|
#define LAYOUT( \
|
||||||
|
k00, k01, k02, \
|
||||||
|
k10, k11, k12 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ k00, k01, k02 }, \
|
||||||
|
{ k10, k11, k12 }, \
|
||||||
|
}
|
||||||
@@ -0,0 +1,243 @@
|
|||||||
|
/*
|
||||||
|
Copyright 2019 kakunpc
|
||||||
|
|
||||||
|
This program is free software: you can redistribute it and/or modify
|
||||||
|
it under the terms of the GNU General Public License as published by
|
||||||
|
the Free Software Foundation, either version 2 of the License, or
|
||||||
|
(at your option) any later version.
|
||||||
|
|
||||||
|
This program is distributed in the hope that it will be useful,
|
||||||
|
but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
GNU General Public License for more details.
|
||||||
|
|
||||||
|
You should have received a copy of the GNU General Public License
|
||||||
|
along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
|
||||||
|
#pragma once
|
||||||
|
|
||||||
|
#include "config_common.h"
|
||||||
|
|
||||||
|
/* USB Device descriptor parameter */
|
||||||
|
#define VENDOR_ID 0xFEED
|
||||||
|
#define PRODUCT_ID 0x0000
|
||||||
|
#define DEVICE_VER 0x0001
|
||||||
|
#define MANUFACTURER kakunpc
|
||||||
|
#define PRODUCT business_card
|
||||||
|
#define DESCRIPTION A custom keyboard
|
||||||
|
|
||||||
|
/* key matrix size */
|
||||||
|
#define MATRIX_ROWS 2
|
||||||
|
#define MATRIX_COLS 3
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Keyboard Matrix Assignments
|
||||||
|
*
|
||||||
|
* Change this to how you wired your keyboard
|
||||||
|
* COLS: AVR pins used for columns, left to right
|
||||||
|
* ROWS: AVR pins used for rows, top to bottom
|
||||||
|
* DIODE_DIRECTION: COL2ROW = COL = Anode (+), ROW = Cathode (-, marked on diode)
|
||||||
|
* ROW2COL = ROW = Anode (+), COL = Cathode (-, marked on diode)
|
||||||
|
*
|
||||||
|
*/
|
||||||
|
#define MATRIX_ROW_PINS { B2, B6 }
|
||||||
|
#define MATRIX_COL_PINS { E6, B4, B5 }
|
||||||
|
#define UNUSED_PINS
|
||||||
|
|
||||||
|
/* COL2ROW, ROW2COL*/
|
||||||
|
#define DIODE_DIRECTION COL2ROW
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Split Keyboard specific options, make sure you have 'SPLIT_KEYBOARD = yes' in your rules.mk, and define SOFT_SERIAL_PIN.
|
||||||
|
*/
|
||||||
|
#define SOFT_SERIAL_PIN D0 // or D1, D2, D3, E6
|
||||||
|
|
||||||
|
// #define BACKLIGHT_PIN B7
|
||||||
|
// #define BACKLIGHT_BREATHING
|
||||||
|
// #define BACKLIGHT_LEVELS 3
|
||||||
|
|
||||||
|
#define RGB_DI_PIN D3
|
||||||
|
#ifdef RGB_DI_PIN
|
||||||
|
#define RGBLED_NUM 6
|
||||||
|
#define RGBLIGHT_HUE_STEP 8
|
||||||
|
#define RGBLIGHT_SAT_STEP 8
|
||||||
|
#define RGBLIGHT_VAL_STEP 8
|
||||||
|
#define RGBLIGHT_LIMIT_VAL 255 /* The maximum brightness level */
|
||||||
|
#define RGBLIGHT_SLEEP /* If defined, the RGB lighting will be switched off when the host goes to sleep */
|
||||||
|
// /*== all animations enable ==*/
|
||||||
|
// #define RGBLIGHT_ANIMATIONS
|
||||||
|
// /*== or choose animations ==*/
|
||||||
|
// #define RGBLIGHT_EFFECT_BREATHING
|
||||||
|
// #define RGBLIGHT_EFFECT_RAINBOW_MOOD
|
||||||
|
// #define RGBLIGHT_EFFECT_RAINBOW_SWIRL
|
||||||
|
// #define RGBLIGHT_EFFECT_SNAKE
|
||||||
|
// #define RGBLIGHT_EFFECT_KNIGHT
|
||||||
|
// #define RGBLIGHT_EFFECT_CHRISTMAS
|
||||||
|
// #define RGBLIGHT_EFFECT_STATIC_GRADIENT
|
||||||
|
// #define RGBLIGHT_EFFECT_RGB_TEST
|
||||||
|
// #define RGBLIGHT_EFFECT_ALTERNATING
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/* Debounce reduces chatter (unintended double-presses) - set 0 if debouncing is not needed */
|
||||||
|
#define DEBOUNCE 5
|
||||||
|
|
||||||
|
/* define if matrix has ghost (lacks anti-ghosting diodes) */
|
||||||
|
//#define MATRIX_HAS_GHOST
|
||||||
|
|
||||||
|
/* Mechanical locking support. Use KC_LCAP, KC_LNUM or KC_LSCR instead in keymap */
|
||||||
|
#define LOCKING_SUPPORT_ENABLE
|
||||||
|
/* Locking resynchronize hack */
|
||||||
|
#define LOCKING_RESYNC_ENABLE
|
||||||
|
|
||||||
|
/* If defined, GRAVE_ESC will always act as ESC when CTRL is held.
|
||||||
|
* This is userful for the Windows task manager shortcut (ctrl+shift+esc).
|
||||||
|
*/
|
||||||
|
// #define GRAVE_ESC_CTRL_OVERRIDE
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Force NKRO
|
||||||
|
*
|
||||||
|
* Force NKRO (nKey Rollover) to be enabled by default, regardless of the saved
|
||||||
|
* state in the bootmagic EEPROM settings. (Note that NKRO must be enabled in the
|
||||||
|
* makefile for this to work.)
|
||||||
|
*
|
||||||
|
* If forced on, NKRO can be disabled via magic key (default = LShift+RShift+N)
|
||||||
|
* until the next keyboard reset.
|
||||||
|
*
|
||||||
|
* NKRO may prevent your keystrokes from being detected in the BIOS, but it is
|
||||||
|
* fully operational during normal computer usage.
|
||||||
|
*
|
||||||
|
* For a less heavy-handed approach, enable NKRO via magic key (LShift+RShift+N)
|
||||||
|
* or via bootmagic (hold SPACE+N while plugging in the keyboard). Once set by
|
||||||
|
* bootmagic, NKRO mode will always be enabled until it is toggled again during a
|
||||||
|
* power-up.
|
||||||
|
*
|
||||||
|
*/
|
||||||
|
//#define FORCE_NKRO
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Magic Key Options
|
||||||
|
*
|
||||||
|
* Magic keys are hotkey commands that allow control over firmware functions of
|
||||||
|
* the keyboard. They are best used in combination with the HID Listen program,
|
||||||
|
* found here: https://www.pjrc.com/teensy/hid_listen.html
|
||||||
|
*
|
||||||
|
* The options below allow the magic key functionality to be changed. This is
|
||||||
|
* useful if your keyboard/keypad is missing keys and you want magic key support.
|
||||||
|
*
|
||||||
|
*/
|
||||||
|
|
||||||
|
/* key combination for magic key command */
|
||||||
|
/* defined by default; to change, uncomment and set to the combination you want */
|
||||||
|
// #define IS_COMMAND() (get_mods() == (MOD_BIT(KC_LSHIFT) | MOD_BIT(KC_RSHIFT)))
|
||||||
|
|
||||||
|
/* control how magic key switches layers */
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_FKEYS true
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_NKEYS true
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_CUSTOM false
|
||||||
|
|
||||||
|
/* override magic key keymap */
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_FKEYS
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_NKEYS
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_CUSTOM
|
||||||
|
//#define MAGIC_KEY_HELP H
|
||||||
|
//#define MAGIC_KEY_HELP_ALT SLASH
|
||||||
|
//#define MAGIC_KEY_DEBUG D
|
||||||
|
//#define MAGIC_KEY_DEBUG_MATRIX X
|
||||||
|
//#define MAGIC_KEY_DEBUG_KBD K
|
||||||
|
//#define MAGIC_KEY_DEBUG_MOUSE M
|
||||||
|
//#define MAGIC_KEY_VERSION V
|
||||||
|
//#define MAGIC_KEY_STATUS S
|
||||||
|
//#define MAGIC_KEY_CONSOLE C
|
||||||
|
//#define MAGIC_KEY_LAYER0 0
|
||||||
|
//#define MAGIC_KEY_LAYER0_ALT GRAVE
|
||||||
|
//#define MAGIC_KEY_LAYER1 1
|
||||||
|
//#define MAGIC_KEY_LAYER2 2
|
||||||
|
//#define MAGIC_KEY_LAYER3 3
|
||||||
|
//#define MAGIC_KEY_LAYER4 4
|
||||||
|
//#define MAGIC_KEY_LAYER5 5
|
||||||
|
//#define MAGIC_KEY_LAYER6 6
|
||||||
|
//#define MAGIC_KEY_LAYER7 7
|
||||||
|
//#define MAGIC_KEY_LAYER8 8
|
||||||
|
//#define MAGIC_KEY_LAYER9 9
|
||||||
|
//#define MAGIC_KEY_BOOTLOADER B
|
||||||
|
//#define MAGIC_KEY_BOOTLOADER_ALT ESC
|
||||||
|
//#define MAGIC_KEY_LOCK CAPS
|
||||||
|
//#define MAGIC_KEY_EEPROM E
|
||||||
|
//#define MAGIC_KEY_EEPROM_CLEAR BSPACE
|
||||||
|
//#define MAGIC_KEY_NKRO N
|
||||||
|
//#define MAGIC_KEY_SLEEP_LED Z
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Feature disable options
|
||||||
|
* These options are also useful to firmware size reduction.
|
||||||
|
*/
|
||||||
|
|
||||||
|
/* disable debug print */
|
||||||
|
//#define NO_DEBUG
|
||||||
|
|
||||||
|
/* disable print */
|
||||||
|
//#define NO_PRINT
|
||||||
|
|
||||||
|
/* disable action features */
|
||||||
|
//#define NO_ACTION_LAYER
|
||||||
|
//#define NO_ACTION_TAPPING
|
||||||
|
//#define NO_ACTION_ONESHOT
|
||||||
|
//#define NO_ACTION_MACRO
|
||||||
|
//#define NO_ACTION_FUNCTION
|
||||||
|
|
||||||
|
/*
|
||||||
|
* MIDI options
|
||||||
|
*/
|
||||||
|
|
||||||
|
/* Prevent use of disabled MIDI features in the keymap */
|
||||||
|
//#define MIDI_ENABLE_STRICT 1
|
||||||
|
|
||||||
|
/* enable basic MIDI features:
|
||||||
|
- MIDI notes can be sent when in Music mode is on
|
||||||
|
*/
|
||||||
|
//#define MIDI_BASIC
|
||||||
|
|
||||||
|
/* enable advanced MIDI features:
|
||||||
|
- MIDI notes can be added to the keymap
|
||||||
|
- Octave shift and transpose
|
||||||
|
- Virtual sustain, portamento, and modulation wheel
|
||||||
|
- etc.
|
||||||
|
*/
|
||||||
|
//#define MIDI_ADVANCED
|
||||||
|
|
||||||
|
/* override number of MIDI tone keycodes (each octave adds 12 keycodes and allocates 12 bytes) */
|
||||||
|
//#define MIDI_TONE_KEYCODE_OCTAVES 1
|
||||||
|
|
||||||
|
/*
|
||||||
|
* HD44780 LCD Display Configuration
|
||||||
|
*/
|
||||||
|
/*
|
||||||
|
#define LCD_LINES 2 //< number of visible lines of the display
|
||||||
|
#define LCD_DISP_LENGTH 16 //< visibles characters per line of the display
|
||||||
|
|
||||||
|
#define LCD_IO_MODE 1 //< 0: memory mapped mode, 1: IO port mode
|
||||||
|
|
||||||
|
#if LCD_IO_MODE
|
||||||
|
#define LCD_PORT PORTB //< port for the LCD lines
|
||||||
|
#define LCD_DATA0_PORT LCD_PORT //< port for 4bit data bit 0
|
||||||
|
#define LCD_DATA1_PORT LCD_PORT //< port for 4bit data bit 1
|
||||||
|
#define LCD_DATA2_PORT LCD_PORT //< port for 4bit data bit 2
|
||||||
|
#define LCD_DATA3_PORT LCD_PORT //< port for 4bit data bit 3
|
||||||
|
#define LCD_DATA0_PIN 4 //< pin for 4bit data bit 0
|
||||||
|
#define LCD_DATA1_PIN 5 //< pin for 4bit data bit 1
|
||||||
|
#define LCD_DATA2_PIN 6 //< pin for 4bit data bit 2
|
||||||
|
#define LCD_DATA3_PIN 7 //< pin for 4bit data bit 3
|
||||||
|
#define LCD_RS_PORT LCD_PORT //< port for RS line
|
||||||
|
#define LCD_RS_PIN 3 //< pin for RS line
|
||||||
|
#define LCD_RW_PORT LCD_PORT //< port for RW line
|
||||||
|
#define LCD_RW_PIN 2 //< pin for RW line
|
||||||
|
#define LCD_E_PORT LCD_PORT //< port for Enable line
|
||||||
|
#define LCD_E_PIN 1 //< pin for Enable line
|
||||||
|
#endif
|
||||||
|
*/
|
||||||
|
|
||||||
|
/* Bootmagic Lite key configuration */
|
||||||
|
// #define BOOTMAGIC_LITE_ROW 0
|
||||||
|
// #define BOOTMAGIC_LITE_COLUMN 0
|
||||||
@@ -0,0 +1,22 @@
|
|||||||
|
/* Copyright 2019 kakunpc
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
|
||||||
|
#pragma once
|
||||||
|
|
||||||
|
// place overrides here
|
||||||
|
#ifdef RGB_DI_PIN
|
||||||
|
#define RGBLIGHT_ANIMATIONS
|
||||||
|
#endif
|
||||||
@@ -0,0 +1,47 @@
|
|||||||
|
/* Copyright 2019 kakunpc
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#include QMK_KEYBOARD_H
|
||||||
|
|
||||||
|
// Defines the keycodes used by our macros in process_record_user
|
||||||
|
|
||||||
|
const uint16_t PROGMEM
|
||||||
|
keymaps[][MATRIX_ROWS][MATRIX_COLS] = {
|
||||||
|
[0] =
|
||||||
|
LAYOUT(/* Base */
|
||||||
|
KC_1, KC_2, KC_3,
|
||||||
|
KC_4, KC_5, KC_6
|
||||||
|
),
|
||||||
|
};
|
||||||
|
|
||||||
|
bool process_record_user(uint16_t keycode, keyrecord_t *record) { return true; }
|
||||||
|
|
||||||
|
void led_set_user(uint8_t usb_led) {}
|
||||||
|
|
||||||
|
void keyboard_post_init_user(void) {
|
||||||
|
rgblight_enable_noeeprom();
|
||||||
|
rgblight_mode_noeeprom(RGBLIGHT_MODE_RAINBOW_MOOD);
|
||||||
|
}
|
||||||
|
|
||||||
|
#ifdef OLED_DRIVER_ENABLE
|
||||||
|
static void render_logo(void) {
|
||||||
|
static const char PROGMEM qmk_logo[] = {0x80, 0x81, 0x82, 0x83, 0x84, 0x85, 0x86, 0x87, 0x88, 0x89, 0x8a, 0x8b, 0x8c, 0x8d, 0x8e, 0x8f, 0x90, 0x91, 0x92, 0x93, 0x94,
|
||||||
|
0xa0, 0xa1, 0xa2, 0xa3, 0xa4, 0xa5, 0xa6, 0xa7, 0xa8, 0xa9, 0xaa, 0xab, 0xac, 0xad, 0xae, 0xaf, 0xb0, 0xb1, 0xb2, 0xb3, 0xb4,
|
||||||
|
0xc0, 0xc1, 0xc2, 0xc3, 0xc4, 0xc5, 0xc6, 0xc7, 0xc8, 0xc9, 0xca, 0xcb, 0xcc, 0xcd, 0xce, 0xcf, 0xd0, 0xd1, 0xd2, 0xd3, 0xd4, 0};
|
||||||
|
|
||||||
|
oled_write_P(qmk_logo, false);
|
||||||
|
}
|
||||||
|
void oled_task_user(void) { render_logo(); }
|
||||||
|
#endif
|
||||||
@@ -0,0 +1 @@
|
|||||||
|
# The default keymap for business_card
|
||||||
@@ -0,0 +1,81 @@
|
|||||||
|
# MCU name
|
||||||
|
MCU = atmega32u4
|
||||||
|
|
||||||
|
# Processor frequency.
|
||||||
|
# This will define a symbol, F_CPU, in all source code files equal to the
|
||||||
|
# processor frequency in Hz. You can then use this symbol in your source code to
|
||||||
|
# calculate timings. Do NOT tack on a 'UL' at the end, this will be done
|
||||||
|
# automatically to create a 32-bit value in your source code.
|
||||||
|
#
|
||||||
|
# This will be an integer division of F_USB below, as it is sourced by
|
||||||
|
# F_USB after it has run through any CPU prescalers. Note that this value
|
||||||
|
# does not *change* the processor frequency - it should merely be updated to
|
||||||
|
# reflect the processor speed set externally so that the code can use accurate
|
||||||
|
# software delays.
|
||||||
|
F_CPU = 16000000
|
||||||
|
|
||||||
|
|
||||||
|
#
|
||||||
|
# LUFA specific
|
||||||
|
#
|
||||||
|
# Target architecture (see library "Board Types" documentation).
|
||||||
|
ARCH = AVR8
|
||||||
|
|
||||||
|
# Input clock frequency.
|
||||||
|
# This will define a symbol, F_USB, in all source code files equal to the
|
||||||
|
# input clock frequency (before any prescaling is performed) in Hz. This value may
|
||||||
|
# differ from F_CPU if prescaling is used on the latter, and is required as the
|
||||||
|
# raw input clock is fed directly to the PLL sections of the AVR for high speed
|
||||||
|
# clock generation for the USB and other AVR subsections. Do NOT tack on a 'UL'
|
||||||
|
# at the end, this will be done automatically to create a 32-bit value in your
|
||||||
|
# source code.
|
||||||
|
#
|
||||||
|
# If no clock division is performed on the input clock inside the AVR (via the
|
||||||
|
# CPU clock adjust registers or the clock division fuses), this will be equal to F_CPU.
|
||||||
|
F_USB = $(F_CPU)
|
||||||
|
|
||||||
|
# Interrupt driven control endpoint task(+60)
|
||||||
|
OPT_DEFS += -DINTERRUPT_CONTROL_ENDPOINT
|
||||||
|
|
||||||
|
|
||||||
|
# Bootloader selection
|
||||||
|
# Teensy halfkay
|
||||||
|
# Pro Micro caterina
|
||||||
|
# Atmel DFU atmel-dfu
|
||||||
|
# LUFA DFU lufa-dfu
|
||||||
|
# QMK DFU qmk-dfu
|
||||||
|
# atmega32a bootloadHID
|
||||||
|
BOOTLOADER = atmel-dfu
|
||||||
|
|
||||||
|
|
||||||
|
# If you don't know the bootloader type, then you can specify the
|
||||||
|
# Boot Section Size in *bytes* by uncommenting out the OPT_DEFS line
|
||||||
|
# Teensy halfKay 512
|
||||||
|
# Teensy++ halfKay 1024
|
||||||
|
# Atmel DFU loader 4096
|
||||||
|
# LUFA bootloader 4096
|
||||||
|
# USBaspLoader 2048
|
||||||
|
# OPT_DEFS += -DBOOTLOADER_SIZE=4096
|
||||||
|
|
||||||
|
|
||||||
|
# Build Options
|
||||||
|
# change yes to no to disable
|
||||||
|
#
|
||||||
|
BOOTMAGIC_ENABLE = no # Virtual DIP switch configuration(+1000)
|
||||||
|
MOUSEKEY_ENABLE = no # Mouse keys(+4700)
|
||||||
|
EXTRAKEY_ENABLE = no # Audio control and System control(+450)
|
||||||
|
CONSOLE_ENABLE = no # Console for debug(+400)
|
||||||
|
COMMAND_ENABLE = no # Commands for debug and configuration
|
||||||
|
# Do not enable SLEEP_LED_ENABLE. it uses the same timer as BACKLIGHT_ENABLE
|
||||||
|
SLEEP_LED_ENABLE = no # Breathing sleep LED during USB suspend
|
||||||
|
# if this doesn't work, see here: https://github.com/tmk/tmk_keyboard/wiki/FAQ#nkro-doesnt-work
|
||||||
|
NKRO_ENABLE = no # USB Nkey Rollover
|
||||||
|
BACKLIGHT_ENABLE = no # Enable keyboard backlight functionality on B7 by default
|
||||||
|
RGBLIGHT_ENABLE = yes # Enable keyboard RGB underglow
|
||||||
|
MIDI_ENABLE = no # MIDI support (+2400 to 4200, depending on config)
|
||||||
|
UNICODE_ENABLE = no # Unicode
|
||||||
|
BLUETOOTH_ENABLE = no # Enable Bluetooth with the Adafruit EZ-Key HID
|
||||||
|
AUDIO_ENABLE = no # Audio output on port C6
|
||||||
|
FAUXCLICKY_ENABLE = no # Use buzzer to emulate clicky switches
|
||||||
|
HD44780_ENABLE = no # Enable support for HD44780 based LCDs (+400)
|
||||||
|
OLED_DRIVER_ENABLE = yes
|
||||||
@@ -0,0 +1,51 @@
|
|||||||
|
/* Copyright 2019 kakunpc
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#include "beta.h"
|
||||||
|
|
||||||
|
// Optional override functions below.
|
||||||
|
// You can leave any or all of these undefined.
|
||||||
|
// These are only required if you want to perform custom actions.
|
||||||
|
|
||||||
|
/*
|
||||||
|
|
||||||
|
void matrix_init_kb(void) {
|
||||||
|
// put your keyboard start-up code here
|
||||||
|
// runs once when the firmware starts up
|
||||||
|
|
||||||
|
matrix_init_user();
|
||||||
|
}
|
||||||
|
|
||||||
|
void matrix_scan_kb(void) {
|
||||||
|
// put your looping keyboard code here
|
||||||
|
// runs every cycle (a lot)
|
||||||
|
|
||||||
|
matrix_scan_user();
|
||||||
|
}
|
||||||
|
|
||||||
|
bool process_record_kb(uint16_t keycode, keyrecord_t *record) {
|
||||||
|
// put your per-action keyboard code here
|
||||||
|
// runs for every action, just before processing by the firmware
|
||||||
|
|
||||||
|
return process_record_user(keycode, record);
|
||||||
|
}
|
||||||
|
|
||||||
|
void led_set_kb(uint8_t usb_led) {
|
||||||
|
// put your keyboard LED indicator (ex: Caps Lock LED) toggling code here
|
||||||
|
|
||||||
|
led_set_user(usb_led);
|
||||||
|
}
|
||||||
|
|
||||||
|
*/
|
||||||
@@ -0,0 +1,37 @@
|
|||||||
|
/* Copyright 2019 kakunpc
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#pragma once
|
||||||
|
|
||||||
|
#include "quantum.h"
|
||||||
|
|
||||||
|
/* This a shortcut to help you visually see your layout.
|
||||||
|
*
|
||||||
|
* The first section contains all of the arguments representing the physical
|
||||||
|
* layout of the board and position of the keys.
|
||||||
|
*
|
||||||
|
* The second converts the arguments into a two-dimensional array which
|
||||||
|
* represents the switch matrix.
|
||||||
|
*/
|
||||||
|
#define LAYOUT( \
|
||||||
|
k00, k01, \
|
||||||
|
k10, k11, \
|
||||||
|
k20, k21 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ k21, k20 }, \
|
||||||
|
{ k11, k10 }, \
|
||||||
|
{ k01, k00 }, \
|
||||||
|
}
|
||||||
@@ -0,0 +1,243 @@
|
|||||||
|
/*
|
||||||
|
Copyright 2019 kakunpc
|
||||||
|
|
||||||
|
This program is free software: you can redistribute it and/or modify
|
||||||
|
it under the terms of the GNU General Public License as published by
|
||||||
|
the Free Software Foundation, either version 2 of the License, or
|
||||||
|
(at your option) any later version.
|
||||||
|
|
||||||
|
This program is distributed in the hope that it will be useful,
|
||||||
|
but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
GNU General Public License for more details.
|
||||||
|
|
||||||
|
You should have received a copy of the GNU General Public License
|
||||||
|
along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
|
||||||
|
#pragma once
|
||||||
|
|
||||||
|
#include "config_common.h"
|
||||||
|
|
||||||
|
/* USB Device descriptor parameter */
|
||||||
|
#define VENDOR_ID 0xFEED
|
||||||
|
#define PRODUCT_ID 0x0000
|
||||||
|
#define DEVICE_VER 0x0001
|
||||||
|
#define MANUFACTURER kakunpc
|
||||||
|
#define PRODUCT business_card
|
||||||
|
#define DESCRIPTION A custom keyboard
|
||||||
|
|
||||||
|
/* key matrix size */
|
||||||
|
#define MATRIX_ROWS 3
|
||||||
|
#define MATRIX_COLS 2
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Keyboard Matrix Assignments
|
||||||
|
*
|
||||||
|
* Change this to how you wired your keyboard
|
||||||
|
* COLS: AVR pins used for columns, left to right
|
||||||
|
* ROWS: AVR pins used for rows, top to bottom
|
||||||
|
* DIODE_DIRECTION: COL2ROW = COL = Anode (+), ROW = Cathode (-, marked on diode)
|
||||||
|
* ROW2COL = ROW = Anode (+), COL = Cathode (-, marked on diode)
|
||||||
|
*
|
||||||
|
*/
|
||||||
|
#define MATRIX_ROW_PINS { B3, B2, B6 }
|
||||||
|
#define MATRIX_COL_PINS { B4, B5 }
|
||||||
|
#define UNUSED_PINS
|
||||||
|
|
||||||
|
/* COL2ROW, ROW2COL*/
|
||||||
|
#define DIODE_DIRECTION COL2ROW
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Split Keyboard specific options, make sure you have 'SPLIT_KEYBOARD = yes' in your rules.mk, and define SOFT_SERIAL_PIN.
|
||||||
|
*/
|
||||||
|
#define SOFT_SERIAL_PIN D0 // or D1, D2, D3, E6
|
||||||
|
|
||||||
|
// #define BACKLIGHT_PIN B7
|
||||||
|
// #define BACKLIGHT_BREATHING
|
||||||
|
// #define BACKLIGHT_LEVELS 3
|
||||||
|
|
||||||
|
#define RGB_DI_PIN D3
|
||||||
|
#ifdef RGB_DI_PIN
|
||||||
|
#define RGBLED_NUM 6
|
||||||
|
#define RGBLIGHT_HUE_STEP 8
|
||||||
|
#define RGBLIGHT_SAT_STEP 8
|
||||||
|
#define RGBLIGHT_VAL_STEP 8
|
||||||
|
#define RGBLIGHT_LIMIT_VAL 255 /* The maximum brightness level */
|
||||||
|
#define RGBLIGHT_SLEEP /* If defined, the RGB lighting will be switched off when the host goes to sleep */
|
||||||
|
// /*== all animations enable ==*/
|
||||||
|
// #define RGBLIGHT_ANIMATIONS
|
||||||
|
// /*== or choose animations ==*/
|
||||||
|
// #define RGBLIGHT_EFFECT_BREATHING
|
||||||
|
// #define RGBLIGHT_EFFECT_RAINBOW_MOOD
|
||||||
|
// #define RGBLIGHT_EFFECT_RAINBOW_SWIRL
|
||||||
|
// #define RGBLIGHT_EFFECT_SNAKE
|
||||||
|
// #define RGBLIGHT_EFFECT_KNIGHT
|
||||||
|
// #define RGBLIGHT_EFFECT_CHRISTMAS
|
||||||
|
// #define RGBLIGHT_EFFECT_STATIC_GRADIENT
|
||||||
|
// #define RGBLIGHT_EFFECT_RGB_TEST
|
||||||
|
// #define RGBLIGHT_EFFECT_ALTERNATING
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/* Debounce reduces chatter (unintended double-presses) - set 0 if debouncing is not needed */
|
||||||
|
#define DEBOUNCE 5
|
||||||
|
|
||||||
|
/* define if matrix has ghost (lacks anti-ghosting diodes) */
|
||||||
|
//#define MATRIX_HAS_GHOST
|
||||||
|
|
||||||
|
/* Mechanical locking support. Use KC_LCAP, KC_LNUM or KC_LSCR instead in keymap */
|
||||||
|
#define LOCKING_SUPPORT_ENABLE
|
||||||
|
/* Locking resynchronize hack */
|
||||||
|
#define LOCKING_RESYNC_ENABLE
|
||||||
|
|
||||||
|
/* If defined, GRAVE_ESC will always act as ESC when CTRL is held.
|
||||||
|
* This is userful for the Windows task manager shortcut (ctrl+shift+esc).
|
||||||
|
*/
|
||||||
|
// #define GRAVE_ESC_CTRL_OVERRIDE
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Force NKRO
|
||||||
|
*
|
||||||
|
* Force NKRO (nKey Rollover) to be enabled by default, regardless of the saved
|
||||||
|
* state in the bootmagic EEPROM settings. (Note that NKRO must be enabled in the
|
||||||
|
* makefile for this to work.)
|
||||||
|
*
|
||||||
|
* If forced on, NKRO can be disabled via magic key (default = LShift+RShift+N)
|
||||||
|
* until the next keyboard reset.
|
||||||
|
*
|
||||||
|
* NKRO may prevent your keystrokes from being detected in the BIOS, but it is
|
||||||
|
* fully operational during normal computer usage.
|
||||||
|
*
|
||||||
|
* For a less heavy-handed approach, enable NKRO via magic key (LShift+RShift+N)
|
||||||
|
* or via bootmagic (hold SPACE+N while plugging in the keyboard). Once set by
|
||||||
|
* bootmagic, NKRO mode will always be enabled until it is toggled again during a
|
||||||
|
* power-up.
|
||||||
|
*
|
||||||
|
*/
|
||||||
|
//#define FORCE_NKRO
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Magic Key Options
|
||||||
|
*
|
||||||
|
* Magic keys are hotkey commands that allow control over firmware functions of
|
||||||
|
* the keyboard. They are best used in combination with the HID Listen program,
|
||||||
|
* found here: https://www.pjrc.com/teensy/hid_listen.html
|
||||||
|
*
|
||||||
|
* The options below allow the magic key functionality to be changed. This is
|
||||||
|
* useful if your keyboard/keypad is missing keys and you want magic key support.
|
||||||
|
*
|
||||||
|
*/
|
||||||
|
|
||||||
|
/* key combination for magic key command */
|
||||||
|
/* defined by default; to change, uncomment and set to the combination you want */
|
||||||
|
// #define IS_COMMAND() (get_mods() == (MOD_BIT(KC_LSHIFT) | MOD_BIT(KC_RSHIFT)))
|
||||||
|
|
||||||
|
/* control how magic key switches layers */
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_FKEYS true
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_NKEYS true
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_CUSTOM false
|
||||||
|
|
||||||
|
/* override magic key keymap */
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_FKEYS
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_NKEYS
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_CUSTOM
|
||||||
|
//#define MAGIC_KEY_HELP H
|
||||||
|
//#define MAGIC_KEY_HELP_ALT SLASH
|
||||||
|
//#define MAGIC_KEY_DEBUG D
|
||||||
|
//#define MAGIC_KEY_DEBUG_MATRIX X
|
||||||
|
//#define MAGIC_KEY_DEBUG_KBD K
|
||||||
|
//#define MAGIC_KEY_DEBUG_MOUSE M
|
||||||
|
//#define MAGIC_KEY_VERSION V
|
||||||
|
//#define MAGIC_KEY_STATUS S
|
||||||
|
//#define MAGIC_KEY_CONSOLE C
|
||||||
|
//#define MAGIC_KEY_LAYER0 0
|
||||||
|
//#define MAGIC_KEY_LAYER0_ALT GRAVE
|
||||||
|
//#define MAGIC_KEY_LAYER1 1
|
||||||
|
//#define MAGIC_KEY_LAYER2 2
|
||||||
|
//#define MAGIC_KEY_LAYER3 3
|
||||||
|
//#define MAGIC_KEY_LAYER4 4
|
||||||
|
//#define MAGIC_KEY_LAYER5 5
|
||||||
|
//#define MAGIC_KEY_LAYER6 6
|
||||||
|
//#define MAGIC_KEY_LAYER7 7
|
||||||
|
//#define MAGIC_KEY_LAYER8 8
|
||||||
|
//#define MAGIC_KEY_LAYER9 9
|
||||||
|
//#define MAGIC_KEY_BOOTLOADER B
|
||||||
|
//#define MAGIC_KEY_BOOTLOADER_ALT ESC
|
||||||
|
//#define MAGIC_KEY_LOCK CAPS
|
||||||
|
//#define MAGIC_KEY_EEPROM E
|
||||||
|
//#define MAGIC_KEY_EEPROM_CLEAR BSPACE
|
||||||
|
//#define MAGIC_KEY_NKRO N
|
||||||
|
//#define MAGIC_KEY_SLEEP_LED Z
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Feature disable options
|
||||||
|
* These options are also useful to firmware size reduction.
|
||||||
|
*/
|
||||||
|
|
||||||
|
/* disable debug print */
|
||||||
|
//#define NO_DEBUG
|
||||||
|
|
||||||
|
/* disable print */
|
||||||
|
//#define NO_PRINT
|
||||||
|
|
||||||
|
/* disable action features */
|
||||||
|
//#define NO_ACTION_LAYER
|
||||||
|
//#define NO_ACTION_TAPPING
|
||||||
|
//#define NO_ACTION_ONESHOT
|
||||||
|
//#define NO_ACTION_MACRO
|
||||||
|
//#define NO_ACTION_FUNCTION
|
||||||
|
|
||||||
|
/*
|
||||||
|
* MIDI options
|
||||||
|
*/
|
||||||
|
|
||||||
|
/* Prevent use of disabled MIDI features in the keymap */
|
||||||
|
//#define MIDI_ENABLE_STRICT 1
|
||||||
|
|
||||||
|
/* enable basic MIDI features:
|
||||||
|
- MIDI notes can be sent when in Music mode is on
|
||||||
|
*/
|
||||||
|
//#define MIDI_BASIC
|
||||||
|
|
||||||
|
/* enable advanced MIDI features:
|
||||||
|
- MIDI notes can be added to the keymap
|
||||||
|
- Octave shift and transpose
|
||||||
|
- Virtual sustain, portamento, and modulation wheel
|
||||||
|
- etc.
|
||||||
|
*/
|
||||||
|
//#define MIDI_ADVANCED
|
||||||
|
|
||||||
|
/* override number of MIDI tone keycodes (each octave adds 12 keycodes and allocates 12 bytes) */
|
||||||
|
//#define MIDI_TONE_KEYCODE_OCTAVES 1
|
||||||
|
|
||||||
|
/*
|
||||||
|
* HD44780 LCD Display Configuration
|
||||||
|
*/
|
||||||
|
/*
|
||||||
|
#define LCD_LINES 2 //< number of visible lines of the display
|
||||||
|
#define LCD_DISP_LENGTH 16 //< visibles characters per line of the display
|
||||||
|
|
||||||
|
#define LCD_IO_MODE 1 //< 0: memory mapped mode, 1: IO port mode
|
||||||
|
|
||||||
|
#if LCD_IO_MODE
|
||||||
|
#define LCD_PORT PORTB //< port for the LCD lines
|
||||||
|
#define LCD_DATA0_PORT LCD_PORT //< port for 4bit data bit 0
|
||||||
|
#define LCD_DATA1_PORT LCD_PORT //< port for 4bit data bit 1
|
||||||
|
#define LCD_DATA2_PORT LCD_PORT //< port for 4bit data bit 2
|
||||||
|
#define LCD_DATA3_PORT LCD_PORT //< port for 4bit data bit 3
|
||||||
|
#define LCD_DATA0_PIN 4 //< pin for 4bit data bit 0
|
||||||
|
#define LCD_DATA1_PIN 5 //< pin for 4bit data bit 1
|
||||||
|
#define LCD_DATA2_PIN 6 //< pin for 4bit data bit 2
|
||||||
|
#define LCD_DATA3_PIN 7 //< pin for 4bit data bit 3
|
||||||
|
#define LCD_RS_PORT LCD_PORT //< port for RS line
|
||||||
|
#define LCD_RS_PIN 3 //< pin for RS line
|
||||||
|
#define LCD_RW_PORT LCD_PORT //< port for RW line
|
||||||
|
#define LCD_RW_PIN 2 //< pin for RW line
|
||||||
|
#define LCD_E_PORT LCD_PORT //< port for Enable line
|
||||||
|
#define LCD_E_PIN 1 //< pin for Enable line
|
||||||
|
#endif
|
||||||
|
*/
|
||||||
|
|
||||||
|
/* Bootmagic Lite key configuration */
|
||||||
|
// #define BOOTMAGIC_LITE_ROW 0
|
||||||
|
// #define BOOTMAGIC_LITE_COLUMN 0
|
||||||
@@ -0,0 +1,23 @@
|
|||||||
|
/* Copyright 2019 kakunpc
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
|
||||||
|
#pragma once
|
||||||
|
|
||||||
|
// place overrides here
|
||||||
|
|
||||||
|
#ifdef RGB_DI_PIN
|
||||||
|
#define RGBLIGHT_ANIMATIONS
|
||||||
|
#endif
|
||||||
@@ -0,0 +1,50 @@
|
|||||||
|
/* Copyright 2019 kakunpc
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#include QMK_KEYBOARD_H
|
||||||
|
|
||||||
|
const uint16_t PROGMEM
|
||||||
|
keymaps[][MATRIX_ROWS][MATRIX_COLS] = {
|
||||||
|
[0] =
|
||||||
|
LAYOUT(/* Base */
|
||||||
|
KC_1, KC_2,
|
||||||
|
KC_3, KC_4,
|
||||||
|
KC_5, KC_6
|
||||||
|
),
|
||||||
|
};
|
||||||
|
|
||||||
|
bool process_record_user(uint16_t keycode, keyrecord_t *record) { return true; }
|
||||||
|
|
||||||
|
void matrix_init_user(void) {
|
||||||
|
rgblight_enable_noeeprom();
|
||||||
|
rgblight_mode_noeeprom(RGBLIGHT_MODE_RAINBOW_MOOD);
|
||||||
|
}
|
||||||
|
|
||||||
|
void matrix_scan_user(void) {}
|
||||||
|
|
||||||
|
void led_set_user(uint8_t usb_led) {}
|
||||||
|
|
||||||
|
void keyboard_post_init_user(void) {}
|
||||||
|
|
||||||
|
#ifdef OLED_DRIVER_ENABLE
|
||||||
|
static void render_logo(void) {
|
||||||
|
static const char PROGMEM qmk_logo[] = {0x80, 0x81, 0x82, 0x83, 0x84, 0x85, 0x86, 0x87, 0x88, 0x89, 0x8a, 0x8b, 0x8c, 0x8d, 0x8e, 0x8f, 0x90, 0x91, 0x92, 0x93, 0x94,
|
||||||
|
0xa0, 0xa1, 0xa2, 0xa3, 0xa4, 0xa5, 0xa6, 0xa7, 0xa8, 0xa9, 0xaa, 0xab, 0xac, 0xad, 0xae, 0xaf, 0xb0, 0xb1, 0xb2, 0xb3, 0xb4,
|
||||||
|
0xc0, 0xc1, 0xc2, 0xc3, 0xc4, 0xc5, 0xc6, 0xc7, 0xc8, 0xc9, 0xca, 0xcb, 0xcc, 0xcd, 0xce, 0xcf, 0xd0, 0xd1, 0xd2, 0xd3, 0xd4, 0};
|
||||||
|
|
||||||
|
oled_write_P(qmk_logo, false);
|
||||||
|
}
|
||||||
|
void oled_task_user(void) { render_logo(); }
|
||||||
|
#endif
|
||||||
@@ -0,0 +1 @@
|
|||||||
|
# The default keymap for business_card
|
||||||
@@ -0,0 +1,81 @@
|
|||||||
|
# MCU name
|
||||||
|
MCU = atmega32u4
|
||||||
|
|
||||||
|
# Processor frequency.
|
||||||
|
# This will define a symbol, F_CPU, in all source code files equal to the
|
||||||
|
# processor frequency in Hz. You can then use this symbol in your source code to
|
||||||
|
# calculate timings. Do NOT tack on a 'UL' at the end, this will be done
|
||||||
|
# automatically to create a 32-bit value in your source code.
|
||||||
|
#
|
||||||
|
# This will be an integer division of F_USB below, as it is sourced by
|
||||||
|
# F_USB after it has run through any CPU prescalers. Note that this value
|
||||||
|
# does not *change* the processor frequency - it should merely be updated to
|
||||||
|
# reflect the processor speed set externally so that the code can use accurate
|
||||||
|
# software delays.
|
||||||
|
F_CPU = 16000000
|
||||||
|
|
||||||
|
|
||||||
|
#
|
||||||
|
# LUFA specific
|
||||||
|
#
|
||||||
|
# Target architecture (see library "Board Types" documentation).
|
||||||
|
ARCH = AVR8
|
||||||
|
|
||||||
|
# Input clock frequency.
|
||||||
|
# This will define a symbol, F_USB, in all source code files equal to the
|
||||||
|
# input clock frequency (before any prescaling is performed) in Hz. This value may
|
||||||
|
# differ from F_CPU if prescaling is used on the latter, and is required as the
|
||||||
|
# raw input clock is fed directly to the PLL sections of the AVR for high speed
|
||||||
|
# clock generation for the USB and other AVR subsections. Do NOT tack on a 'UL'
|
||||||
|
# at the end, this will be done automatically to create a 32-bit value in your
|
||||||
|
# source code.
|
||||||
|
#
|
||||||
|
# If no clock division is performed on the input clock inside the AVR (via the
|
||||||
|
# CPU clock adjust registers or the clock division fuses), this will be equal to F_CPU.
|
||||||
|
F_USB = $(F_CPU)
|
||||||
|
|
||||||
|
# Interrupt driven control endpoint task(+60)
|
||||||
|
OPT_DEFS += -DINTERRUPT_CONTROL_ENDPOINT
|
||||||
|
|
||||||
|
|
||||||
|
# Bootloader selection
|
||||||
|
# Teensy halfkay
|
||||||
|
# Pro Micro caterina
|
||||||
|
# Atmel DFU atmel-dfu
|
||||||
|
# LUFA DFU lufa-dfu
|
||||||
|
# QMK DFU qmk-dfu
|
||||||
|
# atmega32a bootloadHID
|
||||||
|
BOOTLOADER = atmel-dfu
|
||||||
|
|
||||||
|
|
||||||
|
# If you don't know the bootloader type, then you can specify the
|
||||||
|
# Boot Section Size in *bytes* by uncommenting out the OPT_DEFS line
|
||||||
|
# Teensy halfKay 512
|
||||||
|
# Teensy++ halfKay 1024
|
||||||
|
# Atmel DFU loader 4096
|
||||||
|
# LUFA bootloader 4096
|
||||||
|
# USBaspLoader 2048
|
||||||
|
# OPT_DEFS += -DBOOTLOADER_SIZE=4096
|
||||||
|
|
||||||
|
|
||||||
|
# Build Options
|
||||||
|
# change yes to no to disable
|
||||||
|
#
|
||||||
|
BOOTMAGIC_ENABLE = no # Virtual DIP switch configuration(+1000)
|
||||||
|
MOUSEKEY_ENABLE = no # Mouse keys(+4700)
|
||||||
|
EXTRAKEY_ENABLE = no # Audio control and System control(+450)
|
||||||
|
CONSOLE_ENABLE = no # Console for debug(+400)
|
||||||
|
COMMAND_ENABLE = no # Commands for debug and configuration
|
||||||
|
# Do not enable SLEEP_LED_ENABLE. it uses the same timer as BACKLIGHT_ENABLE
|
||||||
|
SLEEP_LED_ENABLE = no # Breathing sleep LED during USB suspend
|
||||||
|
# if this doesn't work, see here: https://github.com/tmk/tmk_keyboard/wiki/FAQ#nkro-doesnt-work
|
||||||
|
NKRO_ENABLE = no # USB Nkey Rollover
|
||||||
|
BACKLIGHT_ENABLE = no # Enable keyboard backlight functionality on B7 by default
|
||||||
|
RGBLIGHT_ENABLE = yes # Enable keyboard RGB underglow
|
||||||
|
MIDI_ENABLE = no # MIDI support (+2400 to 4200, depending on config)
|
||||||
|
UNICODE_ENABLE = no # Unicode
|
||||||
|
BLUETOOTH_ENABLE = no # Enable Bluetooth with the Adafruit EZ-Key HID
|
||||||
|
AUDIO_ENABLE = no # Audio output on port C6
|
||||||
|
FAUXCLICKY_ENABLE = no # Use buzzer to emulate clicky switches
|
||||||
|
HD44780_ENABLE = no # Enable support for HD44780 based LCDs (+400)
|
||||||
|
OLED_DRIVER_ENABLE = yes
|
||||||
@@ -0,0 +1,51 @@
|
|||||||
|
/* Copyright 2019 kakunpc
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#include "business_card.h"
|
||||||
|
|
||||||
|
// Optional override functions below.
|
||||||
|
// You can leave any or all of these undefined.
|
||||||
|
// These are only required if you want to perform custom actions.
|
||||||
|
|
||||||
|
/*
|
||||||
|
|
||||||
|
void matrix_init_kb(void) {
|
||||||
|
// put your keyboard start-up code here
|
||||||
|
// runs once when the firmware starts up
|
||||||
|
|
||||||
|
matrix_init_user();
|
||||||
|
}
|
||||||
|
|
||||||
|
void matrix_scan_kb(void) {
|
||||||
|
// put your looping keyboard code here
|
||||||
|
// runs every cycle (a lot)
|
||||||
|
|
||||||
|
matrix_scan_user();
|
||||||
|
}
|
||||||
|
|
||||||
|
bool process_record_kb(uint16_t keycode, keyrecord_t *record) {
|
||||||
|
// put your per-action keyboard code here
|
||||||
|
// runs for every action, just before processing by the firmware
|
||||||
|
|
||||||
|
return process_record_user(keycode, record);
|
||||||
|
}
|
||||||
|
|
||||||
|
void led_set_kb(uint8_t usb_led) {
|
||||||
|
// put your keyboard LED indicator (ex: Caps Lock LED) toggling code here
|
||||||
|
|
||||||
|
led_set_user(usb_led);
|
||||||
|
}
|
||||||
|
|
||||||
|
*/
|
||||||
@@ -0,0 +1,25 @@
|
|||||||
|
/* Copyright 2019 kakunpc
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#pragma once
|
||||||
|
|
||||||
|
#ifdef KEYBOARD_business_card_alpha
|
||||||
|
#include "alpha.h"
|
||||||
|
#endif
|
||||||
|
#ifdef KEYBOARD_business_card_beta
|
||||||
|
#include "beta.h"
|
||||||
|
#endif
|
||||||
|
|
||||||
|
#include "quantum.h"
|
||||||
Whitespace-only changes.
Whitespace-only changes.
@@ -0,0 +1,15 @@
|
|||||||
|
# business_card
|
||||||
|
|
||||||
|

|
||||||
|
|
||||||
|
A short description of the keyboard/project
|
||||||
|
|
||||||
|
Keyboard Maintainer: [kakunpc](https://github.com/kakunpc)
|
||||||
|
Hardware Supported: The PCBs, controllers supported
|
||||||
|
Hardware Availability: links to where you can find this hardware
|
||||||
|
|
||||||
|
Make example for this keyboard (after setting up your build environment):
|
||||||
|
|
||||||
|
make business_card:default
|
||||||
|
|
||||||
|
See the [build environment setup](https://docs.qmk.fm/#/getting_started_build_tools) and the [make instructions](https://docs.qmk.fm/#/getting_started_make_guide) for more information. Brand new to QMK? Start with our [Complete Newbs Guide](https://docs.qmk.fm/#/newbs).
|
||||||
@@ -0,0 +1,83 @@
|
|||||||
|
# MCU name
|
||||||
|
#MCU = at90usb1286
|
||||||
|
MCU = atmega32u4
|
||||||
|
|
||||||
|
# Processor frequency.
|
||||||
|
# This will define a symbol, F_CPU, in all source code files equal to the
|
||||||
|
# processor frequency in Hz. You can then use this symbol in your source code to
|
||||||
|
# calculate timings. Do NOT tack on a 'UL' at the end, this will be done
|
||||||
|
# automatically to create a 32-bit value in your source code.
|
||||||
|
#
|
||||||
|
# This will be an integer division of F_USB below, as it is sourced by
|
||||||
|
# F_USB after it has run through any CPU prescalers. Note that this value
|
||||||
|
# does not *change* the processor frequency - it should merely be updated to
|
||||||
|
# reflect the processor speed set externally so that the code can use accurate
|
||||||
|
# software delays.
|
||||||
|
F_CPU = 16000000
|
||||||
|
|
||||||
|
|
||||||
|
#
|
||||||
|
# LUFA specific
|
||||||
|
#
|
||||||
|
# Target architecture (see library "Board Types" documentation).
|
||||||
|
ARCH = AVR8
|
||||||
|
|
||||||
|
# Input clock frequency.
|
||||||
|
# This will define a symbol, F_USB, in all source code files equal to the
|
||||||
|
# input clock frequency (before any prescaling is performed) in Hz. This value may
|
||||||
|
# differ from F_CPU if prescaling is used on the latter, and is required as the
|
||||||
|
# raw input clock is fed directly to the PLL sections of the AVR for high speed
|
||||||
|
# clock generation for the USB and other AVR subsections. Do NOT tack on a 'UL'
|
||||||
|
# at the end, this will be done automatically to create a 32-bit value in your
|
||||||
|
# source code.
|
||||||
|
#
|
||||||
|
# If no clock division is performed on the input clock inside the AVR (via the
|
||||||
|
# CPU clock adjust registers or the clock division fuses), this will be equal to F_CPU.
|
||||||
|
F_USB = $(F_CPU)
|
||||||
|
|
||||||
|
# Interrupt driven control endpoint task(+60)
|
||||||
|
OPT_DEFS += -DINTERRUPT_CONTROL_ENDPOINT
|
||||||
|
|
||||||
|
|
||||||
|
# Bootloader selection
|
||||||
|
# Teensy halfkay
|
||||||
|
# Pro Micro caterina
|
||||||
|
# Atmel DFU atmel-dfu
|
||||||
|
# LUFA DFU lufa-dfu
|
||||||
|
# QMK DFU qmk-dfu
|
||||||
|
# atmega32a bootloadHID
|
||||||
|
BOOTLOADER = atmel-dfu
|
||||||
|
|
||||||
|
|
||||||
|
# If you don't know the bootloader type, then you can specify the
|
||||||
|
# Boot Section Size in *bytes* by uncommenting out the OPT_DEFS line
|
||||||
|
# Teensy halfKay 512
|
||||||
|
# Teensy++ halfKay 1024
|
||||||
|
# Atmel DFU loader 4096
|
||||||
|
# LUFA bootloader 4096
|
||||||
|
# USBaspLoader 2048
|
||||||
|
# OPT_DEFS += -DBOOTLOADER_SIZE=4096
|
||||||
|
|
||||||
|
|
||||||
|
# Build Options
|
||||||
|
# change yes to no to disable
|
||||||
|
#
|
||||||
|
BOOTMAGIC_ENABLE = no # Virtual DIP switch configuration(+1000)
|
||||||
|
MOUSEKEY_ENABLE = no # Mouse keys(+4700)
|
||||||
|
EXTRAKEY_ENABLE = no # Audio control and System control(+450)
|
||||||
|
CONSOLE_ENABLE = no # Console for debug(+400)
|
||||||
|
COMMAND_ENABLE = no # Commands for debug and configuration
|
||||||
|
# Do not enable SLEEP_LED_ENABLE. it uses the same timer as BACKLIGHT_ENABLE
|
||||||
|
SLEEP_LED_ENABLE = no # Breathing sleep LED during USB suspend
|
||||||
|
# if this doesn't work, see here: https://github.com/tmk/tmk_keyboard/wiki/FAQ#nkro-doesnt-work
|
||||||
|
NKRO_ENABLE = no # USB Nkey Rollover
|
||||||
|
BACKLIGHT_ENABLE = no # Enable keyboard backlight functionality on B7 by default
|
||||||
|
RGBLIGHT_ENABLE = yes # Enable keyboard RGB underglow
|
||||||
|
MIDI_ENABLE = no # MIDI support (+2400 to 4200, depending on config)
|
||||||
|
UNICODE_ENABLE = no # Unicode
|
||||||
|
BLUETOOTH_ENABLE = no # Enable Bluetooth with the Adafruit EZ-Key HID
|
||||||
|
AUDIO_ENABLE = no # Audio output on port C6
|
||||||
|
FAUXCLICKY_ENABLE = no # Use buzzer to emulate clicky switches
|
||||||
|
HD44780_ENABLE = no # Enable support for HD44780 based LCDs (+400)
|
||||||
|
|
||||||
|
DEFAULT_FOLDER = business_card/beta
|
||||||
@@ -1,5 +1,5 @@
|
|||||||
SRC += matrix.c \
|
SRC += matrix.c \
|
||||||
../../../drivers/avr/i2c_slave.c
|
i2c_slave.c
|
||||||
|
|
||||||
# MCU name
|
# MCU name
|
||||||
#MCU = at90usb1286
|
#MCU = at90usb1286
|
||||||
|
|||||||
@@ -1,5 +1,5 @@
|
|||||||
SRC += matrix.c \
|
SRC += matrix.c \
|
||||||
../../../drivers/avr/i2c_master.c
|
i2c_master.c
|
||||||
|
|
||||||
# MCU name
|
# MCU name
|
||||||
#MCU = at90usb1286
|
#MCU = at90usb1286
|
||||||
|
|||||||
@@ -1,5 +1,5 @@
|
|||||||
SRC += matrix.c \
|
SRC += matrix.c \
|
||||||
../../../drivers/avr/i2c_slave.c
|
i2c_slave.c
|
||||||
|
|
||||||
# MCU name
|
# MCU name
|
||||||
#MCU = at90usb1286
|
#MCU = at90usb1286
|
||||||
|
|||||||
@@ -1,5 +1,5 @@
|
|||||||
SRC += matrix.c \
|
SRC += matrix.c \
|
||||||
../../../drivers/avr/i2c_slave.c
|
i2c_slave.c
|
||||||
|
|
||||||
# MCU name
|
# MCU name
|
||||||
#MCU = at90usb1286
|
#MCU = at90usb1286
|
||||||
|
|||||||
@@ -0,0 +1,38 @@
|
|||||||
|
{
|
||||||
|
"keyboard_name": "CO60",
|
||||||
|
"url": "https://github.com/jmdaly/CO60",
|
||||||
|
"maintainer": "qmk",
|
||||||
|
"width": 15,
|
||||||
|
"height": 5,
|
||||||
|
"layouts": {
|
||||||
|
"LAYOUT_all": {
|
||||||
|
"key_count": 68,
|
||||||
|
"layout": [{"label":"Esc", "x":0, "y":0}, {"label":"!", "x":1, "y":0}, {"label":"@", "x":2, "y":0}, {"label":"#", "x":3, "y":0}, {"label":"$", "x":4, "y":0}, {"label":"%", "x":5, "y":0}, {"label":"^", "x":6, "y":0}, {"label":"&", "x":7, "y":0}, {"label":"*", "x":8, "y":0}, {"label":"(", "x":9, "y":0}, {"label":")", "x":10, "y":0}, {"label":"_", "x":11, "y":0}, {"label":"+", "x":12, "y":0}, {"label":"~", "x":13, "y":0}, {"label":"Del", "x":14, "y":0}, {"label":"Tab", "x":0, "y":1, "w":1.5}, {"label":"Q", "x":1.5, "y":1}, {"label":"W", "x":2.5, "y":1}, {"label":"E", "x":3.5, "y":1}, {"label":"R", "x":4.5, "y":1}, {"label":"T", "x":5.5, "y":1}, {"label":"Y", "x":6.5, "y":1}, {"label":"U", "x":7.5, "y":1}, {"label":"I", "x":8.5, "y":1}, {"label":"O", "x":9.5, "y":1}, {"label":"P", "x":10.5, "y":1}, {"label":"{", "x":11.5, "y":1}, {"label":"}", "x":12.5, "y":1}, {"label":"|", "x":13.5, "y":1, "w":1.5}, {"label":"Caps Lock", "x":0, "y":2, "w":1.75}, {"label":"A", "x":1.75, "y":2}, {"label":"S", "x":2.75, "y":2}, {"label":"D", "x":3.75, "y":2}, {"label":"F", "x":4.75, "y":2}, {"label":"G", "x":5.75, "y":2}, {"label":"H", "x":6.75, "y":2}, {"label":"J", "x":7.75, "y":2}, {"label":"K", "x":8.75, "y":2}, {"label":"L", "x":9.75, "y":2}, {"label":":", "x":10.75, "y":2}, {"label":"\"", "x":11.75, "y":2}, {"x":12.75, "y":2}, {"label":"Enter", "x":13.75, "y":2, "w":1.25}, {"label":"Shift", "x":0, "y":3, "w":1.25}, {"x":1.25, "y":3}, {"label":"Z", "x":2.25, "y":3}, {"label":"X", "x":3.25, "y":3}, {"label":"C", "x":4.25, "y":3}, {"label":"V", "x":5.25, "y":3}, {"label":"B", "x":6.25, "y":3}, {"label":"N", "x":7.25, "y":3}, {"label":"M", "x":8.25, "y":3}, {"label":"<", "x":9.25, "y":3}, {"label":">", "x":10.25, "y":3}, {"label":"?", "x":11.25, "y":3}, {"label":"Shift", "x":12.25, "y":3, "w":1.75}, {"label":"Fn", "x":14, "y":3}, {"label":"Ctrl", "x":0, "y":4, "w":1.25}, {"label":"Win", "x":1.25, "y":4, "w":1.25}, {"label":"Alt", "x":2.5, "y":4, "w":1.25}, {"label":"LSpace", "x":3.75, "y":4, "w":2.25}, {"label":"Fn", "x":6, "y":4, "w":1.25}, {"label":"RSpace", "x":7.25, "y":4, "w":2.75}, {"label":"Alt", "x":10, "y":4, "w":1}, {"label":"Win", "x":11, "y":4, "w":1}, {"label":"Menu", "x":12, "y":4, "w":1}, {"label":"Ctrl", "x":13, "y":4, "w":1}, {"label":"Fn", "x":14, "y":4, "w":1}]
|
||||||
|
},
|
||||||
|
"LAYOUT_60_ansi": {
|
||||||
|
"key_count": 61,
|
||||||
|
"layout": [{"label":"~", "x":0, "y":0}, {"label":"!", "x":1, "y":0}, {"label":"@", "x":2, "y":0}, {"label":"#", "x":3, "y":0}, {"label":"$", "x":4, "y":0}, {"label":"%", "x":5, "y":0}, {"label":"^", "x":6, "y":0}, {"label":"&", "x":7, "y":0}, {"label":"*", "x":8, "y":0}, {"label":"(", "x":9, "y":0}, {"label":")", "x":10, "y":0}, {"label":"_", "x":11, "y":0}, {"label":"+", "x":12, "y":0}, {"label":"Backspace", "x":13, "y":0, "w":2}, {"label":"Tab", "x":0, "y":1, "w":1.5}, {"label":"Q", "x":1.5, "y":1}, {"label":"W", "x":2.5, "y":1}, {"label":"E", "x":3.5, "y":1}, {"label":"R", "x":4.5, "y":1}, {"label":"T", "x":5.5, "y":1}, {"label":"Y", "x":6.5, "y":1}, {"label":"U", "x":7.5, "y":1}, {"label":"I", "x":8.5, "y":1}, {"label":"O", "x":9.5, "y":1}, {"label":"P", "x":10.5, "y":1}, {"label":"{", "x":11.5, "y":1}, {"label":"}", "x":12.5, "y":1}, {"label":"|", "x":13.5, "y":1, "w":1.5}, {"label":"CapsLock", "x":0, "y":2, "w":1.75}, {"label":"A", "x":1.75, "y":2}, {"label":"S", "x":2.75, "y":2}, {"label":"D", "x":3.75, "y":2}, {"label":"F", "x":4.75, "y":2}, {"label":"G", "x":5.75, "y":2}, {"label":"H", "x":6.75, "y":2}, {"label":"J", "x":7.75, "y":2}, {"label":"K", "x":8.75, "y":2}, {"label":"L", "x":9.75, "y":2}, {"label":":", "x":10.75, "y":2}, {"label":"\"", "x":11.75, "y":2}, {"label":"Enter", "x":12.75, "y":2, "w":2.25}, {"label":"Shift", "x":0, "y":3, "w":2.25}, {"label":"Z", "x":2.25, "y":3}, {"label":"X", "x":3.25, "y":3}, {"label":"C", "x":4.25, "y":3}, {"label":"V", "x":5.25, "y":3}, {"label":"B", "x":6.25, "y":3}, {"label":"N", "x":7.25, "y":3}, {"label":"M", "x":8.25, "y":3}, {"label":"<", "x":9.25, "y":3}, {"label":">", "x":10.25, "y":3}, {"label":"?", "x":11.25, "y":3}, {"label":"Shift", "x":12.25, "y":3, "w":2.75}, {"label":"Ctrl", "x":0, "y":4, "w":1.25}, {"label":"Win", "x":1.25, "y":4, "w":1.25}, {"label":"Alt", "x":2.5, "y":4, "w":1.25}, {"x":3.75, "y":4, "w":6.25}, {"label":"Alt", "x":10, "y":4, "w":1.25}, {"label":"Win", "x":11.25, "y":4, "w":1.25}, {"label":"Menu", "x":12.5, "y":4, "w":1.25}, {"label":"Ctrl", "x":13.75, "y":4, "w":1.25}]
|
||||||
|
},
|
||||||
|
"LAYOUT_60_ansi_split_bs_rshift": {
|
||||||
|
"key_count": 63,
|
||||||
|
"layout": [{"label":"Esc", "x":0, "y":0}, {"label":"!", "x":1, "y":0}, {"label":"@", "x":2, "y":0}, {"label":"#", "x":3, "y":0}, {"label":"$", "x":4, "y":0}, {"label":"%", "x":5, "y":0}, {"label":"^", "x":6, "y":0}, {"label":"&", "x":7, "y":0}, {"label":"*", "x":8, "y":0}, {"label":"(", "x":9, "y":0}, {"label":")", "x":10, "y":0}, {"label":"_", "x":11, "y":0}, {"label":"+", "x":12, "y":0}, {"label":"~", "x":13, "y":0, "w":1}, {"label":"Del", "x":14, "y":0, "w":1}, {"label":"Tab", "x":0, "y":1, "w":1.5}, {"label":"Q", "x":1.5, "y":1}, {"label":"W", "x":2.5, "y":1}, {"label":"E", "x":3.5, "y":1}, {"label":"R", "x":4.5, "y":1}, {"label":"T", "x":5.5, "y":1}, {"label":"Y", "x":6.5, "y":1}, {"label":"U", "x":7.5, "y":1}, {"label":"I", "x":8.5, "y":1}, {"label":"O", "x":9.5, "y":1}, {"label":"P", "x":10.5, "y":1}, {"label":"{", "x":11.5, "y":1}, {"label":"}", "x":12.5, "y":1}, {"label":"|", "x":13.5, "y":1, "w":1.5}, {"label":"CapsLock", "x":0, "y":2, "w":1.75}, {"label":"A", "x":1.75, "y":2}, {"label":"S", "x":2.75, "y":2}, {"label":"D", "x":3.75, "y":2}, {"label":"F", "x":4.75, "y":2}, {"label":"G", "x":5.75, "y":2}, {"label":"H", "x":6.75, "y":2}, {"label":"J", "x":7.75, "y":2}, {"label":"K", "x":8.75, "y":2}, {"label":"L", "x":9.75, "y":2}, {"label":":", "x":10.75, "y":2}, {"label":"\"", "x":11.75, "y":2}, {"label":"Enter", "x":12.75, "y":2, "w":2.25}, {"label":"Shift", "x":0, "y":3, "w":2.25}, {"label":"Z", "x":2.25, "y":3}, {"label":"X", "x":3.25, "y":3}, {"label":"C", "x":4.25, "y":3}, {"label":"V", "x":5.25, "y":3}, {"label":"B", "x":6.25, "y":3}, {"label":"N", "x":7.25, "y":3}, {"label":"M", "x":8.25, "y":3}, {"label":"<", "x":9.25, "y":3}, {"label":">", "x":10.25, "y":3}, {"label":"?", "x":11.25, "y":3}, {"label":"Shift", "x":12.25, "y":3, "w":1.75}, {"label":"Fn", "x":14, "y":3, "w":1}, {"label":"Ctrl", "x":0, "y":4, "w":1.25}, {"label":"Win", "x":1.25, "y":4, "w":1.25}, {"label":"Alt", "x":2.5, "y":4, "w":1.25}, {"x":3.75, "y":4, "w":6.25}, {"label":"Alt", "x":10, "y":4, "w":1.25}, {"label":"Win", "x":11.25, "y":4, "w":1.25}, {"label":"Menu", "x":12.5, "y":4, "w":1.25}, {"label":"Ctrl", "x":13.75, "y":4, "w":1.25}]
|
||||||
|
},
|
||||||
|
"LAYOUT_60_iso": {
|
||||||
|
"key_count": 62,
|
||||||
|
"layout": [{"label":"Esc", "x":0, "y":0}, {"label":"!", "x":1, "y":0}, {"label":"\"", "x":2, "y":0}, {"label":"£", "x":3, "y":0}, {"label":"$", "x":4, "y":0}, {"label":"%", "x":5, "y":0}, {"label":"^", "x":6, "y":0}, {"label":"&", "x":7, "y":0}, {"label":"*", "x":8, "y":0}, {"label":"(", "x":9, "y":0}, {"label":")", "x":10, "y":0}, {"label":"_", "x":11, "y":0}, {"label":"+", "x":12, "y":0}, {"label":"Backspace", "x":13, "y":0, "w":2}, {"label":"Tab", "x":0, "y":1, "w":1.5}, {"label":"Q", "x":1.5, "y":1}, {"label":"W", "x":2.5, "y":1}, {"label":"E", "x":3.5, "y":1}, {"label":"R", "x":4.5, "y":1}, {"label":"T", "x":5.5, "y":1}, {"label":"Y", "x":6.5, "y":1}, {"label":"U", "x":7.5, "y":1}, {"label":"I", "x":8.5, "y":1}, {"label":"O", "x":9.5, "y":1}, {"label":"P", "x":10.5, "y":1}, {"label":"[", "x":11.5, "y":1}, {"label":"]", "x":12.5, "y":1}, {"label":"CapsLock", "x":0, "y":2, "w":1.75}, {"label":"A", "x":1.75, "y":2}, {"label":"S", "x":2.75, "y":2}, {"label":"D", "x":3.75, "y":2}, {"label":"F", "x":4.75, "y":2}, {"label":"G", "x":5.75, "y":2}, {"label":"H", "x":6.75, "y":2}, {"label":"J", "x":7.75, "y":2}, {"label":"K", "x":8.75, "y":2}, {"label":"L", "x":9.75, "y":2}, {"label":":", "x":10.75, "y":2}, {"label":"@", "x":11.75, "y":2}, {"label":"~", "x":12.75, "y":2}, {"label":"Enter", "x":13.75, "y":1, "w":1.25, "h":2}, {"label":"Shift", "x":0, "y":3, "w":1.25}, {"label":"|", "x":1.25, "y":3}, {"label":"Z", "x":2.25, "y":3}, {"label":"X", "x":3.25, "y":3}, {"label":"C", "x":4.25, "y":3}, {"label":"V", "x":5.25, "y":3}, {"label":"B", "x":6.25, "y":3}, {"label":"N", "x":7.25, "y":3}, {"label":"M", "x":8.25, "y":3}, {"label":"<", "x":9.25, "y":3}, {"label":">", "x":10.25, "y":3}, {"label":"?", "x":11.25, "y":3}, {"label":"Shift", "x":12.25, "y":3, "w":2.75}, {"label":"Ctrl", "x":0, "y":4, "w":1.25}, {"label":"Win", "x":1.25, "y":4, "w":1.25}, {"label":"Alt", "x":2.5, "y":4, "w":1.25}, {"x":3.75, "y":4, "w":6.25}, {"label":"AltGr", "x":10, "y":4, "w":1.25}, {"label":"Win", "x":11.25, "y":4, "w":1.25}, {"label":"Menu", "x":12.5, "y":4, "w":1.25}, {"label":"Ctrl", "x":13.75, "y":4, "w":1.25}]
|
||||||
|
},
|
||||||
|
"LAYOUT_60_hhkb": {
|
||||||
|
"key_count": 60,
|
||||||
|
"layout": [{"label":"Esc", "x":0, "y":0}, {"label":"!", "x":1, "y":0}, {"label":"@", "x":2, "y":0}, {"label":"#", "x":3, "y":0}, {"label":"$", "x":4, "y":0}, {"label":"%", "x":5, "y":0}, {"label":"^", "x":6, "y":0}, {"label":"&", "x":7, "y":0}, {"label":"*", "x":8, "y":0}, {"label":"(", "x":9, "y":0}, {"label":")", "x":10, "y":0}, {"label":"_", "x":11, "y":0}, {"label":"+", "x":12, "y":0}, {"label":"~", "x":13, "y":0}, {"label":"Del", "x":14, "y":0}, {"label":"Tab", "x":0, "y":1, "w":1.5}, {"label":"Q", "x":1.5, "y":1}, {"label":"W", "x":2.5, "y":1}, {"label":"E", "x":3.5, "y":1}, {"label":"R", "x":4.5, "y":1}, {"label":"T", "x":5.5, "y":1}, {"label":"Y", "x":6.5, "y":1}, {"label":"U", "x":7.5, "y":1}, {"label":"I", "x":8.5, "y":1}, {"label":"O", "x":9.5, "y":1}, {"label":"P", "x":10.5, "y":1}, {"label":"[", "x":11.5, "y":1}, {"label":"]", "x":12.5, "y":1}, {"label":"Backspace", "x":13.5, "y":1, "w":1.5}, {"label":"CapsLock", "x":0, "y":2, "w":1.75}, {"label":"A", "x":1.75, "y":2}, {"label":"S", "x":2.75, "y":2}, {"label":"D", "x":3.75, "y":2}, {"label":"F", "x":4.75, "y":2}, {"label":"G", "x":5.75, "y":2}, {"label":"H", "x":6.75, "y":2}, {"label":"J", "x":7.75, "y":2}, {"label":"K", "x":8.75, "y":2}, {"label":"L", "x":9.75, "y":2}, {"label":":", "x":10.75, "y":2}, {"label":"\"", "x":11.75, "y":2}, {"label":"Enter", "x":12.75, "y":2, "w":2.25}, {"label":"Shift", "x":0, "y":3, "w":2.25}, {"label":"Z", "x":2.25, "y":3}, {"label":"X", "x":3.25, "y":3}, {"label":"C", "x":4.25, "y":3}, {"label":"V", "x":5.25, "y":3}, {"label":"B", "x":6.25, "y":3}, {"label":"N", "x":7.25, "y":3}, {"label":"M", "x":8.25, "y":3}, {"label":"<", "x":9.25, "y":3}, {"label":">", "x":10.25, "y":3}, {"label":"?", "x":11.25, "y":3}, {"label":"Shift", "x":12.25, "y":3, "w":1.75},{"label":"Fn", "x":14, "y":3}, {"label":"Win", "x":1.5, "y":4}, {"label":"Alt", "x":2.5, "y":4, "w":1.5}, {"label":"Space", "x":4, "y":4, "w":7}, {"label":"Alt", "x":11, "y":4, "w":1.5}, {"label":"Win", "x":12.5, "y":4}]
|
||||||
|
},
|
||||||
|
"LAYOUT_60_hhkb_split_space": {
|
||||||
|
"key_count": 62,
|
||||||
|
"layout": [{"label":"Esc", "x":0, "y":0}, {"label":"!", "x":1, "y":0}, {"label":"@", "x":2, "y":0}, {"label":"#", "x":3, "y":0}, {"label":"$", "x":4, "y":0}, {"label":"%", "x":5, "y":0}, {"label":"^", "x":6, "y":0}, {"label":"&", "x":7, "y":0}, {"label":"*", "x":8, "y":0}, {"label":"(", "x":9, "y":0}, {"label":")", "x":10, "y":0}, {"label":"_", "x":11, "y":0}, {"label":"+", "x":12, "y":0}, {"label":"~", "x":13, "y":0}, {"label":"Del", "x":14, "y":0}, {"label":"Tab", "x":0, "y":1, "w":1.5}, {"label":"Q", "x":1.5, "y":1}, {"label":"W", "x":2.5, "y":1}, {"label":"E", "x":3.5, "y":1}, {"label":"R", "x":4.5, "y":1}, {"label":"T", "x":5.5, "y":1}, {"label":"Y", "x":6.5, "y":1}, {"label":"U", "x":7.5, "y":1}, {"label":"I", "x":8.5, "y":1}, {"label":"O", "x":9.5, "y":1}, {"label":"P", "x":10.5, "y":1}, {"label":"[", "x":11.5, "y":1}, {"label":"]", "x":12.5, "y":1}, {"label":"Backspace", "x":13.5, "y":1, "w":1.5}, {"label":"CapsLock", "x":0, "y":2, "w":1.75}, {"label":"A", "x":1.75, "y":2}, {"label":"S", "x":2.75, "y":2}, {"label":"D", "x":3.75, "y":2}, {"label":"F", "x":4.75, "y":2}, {"label":"G", "x":5.75, "y":2}, {"label":"H", "x":6.75, "y":2}, {"label":"J", "x":7.75, "y":2}, {"label":"K", "x":8.75, "y":2}, {"label":"L", "x":9.75, "y":2}, {"label":":", "x":10.75, "y":2}, {"label":"\"", "x":11.75, "y":2}, {"label":"Enter", "x":12.75, "y":2, "w":2.25}, {"label":"Shift", "x":0, "y":3, "w":2.25}, {"label":"Z", "x":2.25, "y":3}, {"label":"X", "x":3.25, "y":3}, {"label":"C", "x":4.25, "y":3}, {"label":"V", "x":5.25, "y":3}, {"label":"B", "x":6.25, "y":3}, {"label":"N", "x":7.25, "y":3}, {"label":"M", "x":8.25, "y":3}, {"label":"<", "x":9.25, "y":3}, {"label":">", "x":10.25, "y":3}, {"label":"?", "x":11.25, "y":3}, {"label":"Shift", "x":12.25, "y":3, "w":1.75},{"label":"Fn", "x":14, "y":3}, {"label":"Win", "x":1.5, "y":4}, {"label":"Alt", "x":2.5, "y":4, "w":1.5}, {"label":"LSpace", "x":4, "y":4, "w":2.75}, {"label":"Fn", "x":6.75, "y":4, "w":1.5}, {"label":"RSpace", "x":8.25, "y":4, "w":2.75}, {"label":"Alt", "x":11, "y":4, "w":1.5}, {"label":"Win", "x":12.5, "y":4}]
|
||||||
|
},
|
||||||
|
"LAYOUT_60_hhkb_split_625u_space": {
|
||||||
|
"key_count": 63,
|
||||||
|
"layout": [{"label":"Esc", "x":0, "y":0}, {"label":"!", "x":1, "y":0}, {"label":"@", "x":2, "y":0}, {"label":"#", "x":3, "y":0}, {"label":"$", "x":4, "y":0}, {"label":"%", "x":5, "y":0}, {"label":"^", "x":6, "y":0}, {"label":"&", "x":7, "y":0}, {"label":"*", "x":8, "y":0}, {"label":"(", "x":9, "y":0}, {"label":")", "x":10, "y":0}, {"label":"_", "x":11, "y":0}, {"label":"+", "x":12, "y":0}, {"label":"~", "x":13, "y":0}, {"label":"Del", "x":14, "y":0}, {"label":"Tab", "x":0, "y":1, "w":1.5}, {"label":"Q", "x":1.5, "y":1}, {"label":"W", "x":2.5, "y":1}, {"label":"E", "x":3.5, "y":1}, {"label":"R", "x":4.5, "y":1}, {"label":"T", "x":5.5, "y":1}, {"label":"Y", "x":6.5, "y":1}, {"label":"U", "x":7.5, "y":1}, {"label":"I", "x":8.5, "y":1}, {"label":"O", "x":9.5, "y":1}, {"label":"P", "x":10.5, "y":1}, {"label":"[", "x":11.5, "y":1}, {"label":"]", "x":12.5, "y":1}, {"label":"Backspace", "x":13.5, "y":1, "w":1.5}, {"label":"CapsLock", "x":0, "y":2, "w":1.75}, {"label":"A", "x":1.75, "y":2}, {"label":"S", "x":2.75, "y":2}, {"label":"D", "x":3.75, "y":2}, {"label":"F", "x":4.75, "y":2}, {"label":"G", "x":5.75, "y":2}, {"label":"H", "x":6.75, "y":2}, {"label":"J", "x":7.75, "y":2}, {"label":"K", "x":8.75, "y":2}, {"label":"L", "x":9.75, "y":2}, {"label":":", "x":10.75, "y":2}, {"label":"\"", "x":11.75, "y":2}, {"label":"Enter", "x":12.75, "y":2, "w":2.25}, {"label":"Shift", "x":0, "y":3, "w":2.25}, {"label":"Z", "x":2.25, "y":3}, {"label":"X", "x":3.25, "y":3}, {"label":"C", "x":4.25, "y":3}, {"label":"V", "x":5.25, "y":3}, {"label":"B", "x":6.25, "y":3}, {"label":"N", "x":7.25, "y":3}, {"label":"M", "x":8.25, "y":3}, {"label":"<", "x":9.25, "y":3}, {"label":">", "x":10.25, "y":3}, {"label":"?", "x":11.25, "y":3}, {"label":"Shift", "x":12.25, "y":3, "w":1.75},{"label":"Fn", "x":14, "y":3}, {"label":"Win", "x":1.5, "y":4}, {"label":"Alt", "x":2.5, "y":4, "w":1.25}, {"label":"LSpace", "x":3.75, "y":4, "w":2.25}, {"label":"Fn", "x":6, "y":4, "w":1.25}, {"label":"RSpace", "x":7.25, "y":4, "w":2.75}, {"label":"Menu", "x":10, "y":4, "w":1.25}, {"label":"Alt", "x":11.25, "y":4, "w":1.25}, {"label":"Win", "x":12.5, "y":4}]
|
||||||
|
}
|
||||||
|
}
|
||||||
|
}
|
||||||
|
|
||||||
@@ -0,0 +1,20 @@
|
|||||||
|
/* Copyright 2019 John M Daly <[email protected]>
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
|
||||||
|
#pragma once
|
||||||
|
|
||||||
|
|
||||||
|
// place overrides here
|
||||||
@@ -0,0 +1,48 @@
|
|||||||
|
/* Copyright 2019 John M Daly <[email protected]>
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#include QMK_KEYBOARD_H
|
||||||
|
|
||||||
|
|
||||||
|
enum co60_layers {
|
||||||
|
_L1,
|
||||||
|
_L2
|
||||||
|
};
|
||||||
|
|
||||||
|
const uint16_t PROGMEM keymaps[][MATRIX_ROWS][MATRIX_COLS] = {
|
||||||
|
[_L1] = LAYOUT_all( /* Base */
|
||||||
|
KC_ESC, KC_1, KC_2, KC_3, KC_4, KC_5, KC_6, KC_7, KC_8, KC_9, KC_0, KC_MINS, KC_EQL, KC_GRV, KC_DEL,
|
||||||
|
KC_TAB, KC_Q, KC_W, KC_E, KC_R, KC_T, KC_Y, KC_U, KC_I, KC_O, KC_P, KC_LBRC, KC_RBRC, KC_BSLS,
|
||||||
|
KC_CAPS, KC_A, KC_S, KC_D, KC_F, KC_G, KC_H, KC_J, KC_K, KC_L, KC_SCLN, KC_QUOT, KC_NUHS, KC_ENT,
|
||||||
|
KC_LSFT, KC_NUBS, KC_Z, KC_X, KC_C, KC_V, KC_B, KC_N, KC_M, KC_COMM, KC_DOT, KC_SLSH, KC_RSFT, KC_LSFT,
|
||||||
|
KC_LCTL, KC_LGUI, KC_LALT, KC_ENT, KC_HOME, KC_END, KC_INS, KC_RALT, KC_RGUI, KC_RIGHT, KC_RCTL
|
||||||
|
)
|
||||||
|
};
|
||||||
|
|
||||||
|
void matrix_init_user(void) {
|
||||||
|
|
||||||
|
}
|
||||||
|
|
||||||
|
void matrix_scan_user(void) {
|
||||||
|
|
||||||
|
}
|
||||||
|
|
||||||
|
bool process_record_user(uint16_t keycode, keyrecord_t *record) {
|
||||||
|
return true;
|
||||||
|
}
|
||||||
|
|
||||||
|
void led_set_user(uint8_t usb_led) {
|
||||||
|
|
||||||
|
}
|
||||||
@@ -0,0 +1,5 @@
|
|||||||
|
# Keymap that uses all possible switches
|
||||||
|
|
||||||
|
This is in part to test all of the switches,
|
||||||
|
but also it may be useful if anyone ever makes a
|
||||||
|
layout that requires all switch positions.
|
||||||
@@ -0,0 +1,19 @@
|
|||||||
|
/* Copyright 2018 John M Daly
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
|
||||||
|
#pragma once
|
||||||
|
|
||||||
|
// place overrides here
|
||||||
@@ -0,0 +1,54 @@
|
|||||||
|
/* Copyright 2019 John M Daly <[email protected]>
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#include QMK_KEYBOARD_H
|
||||||
|
|
||||||
|
enum co60_layers {
|
||||||
|
_L1,
|
||||||
|
_L2
|
||||||
|
};
|
||||||
|
|
||||||
|
const uint16_t PROGMEM keymaps[][MATRIX_ROWS][MATRIX_COLS] = {
|
||||||
|
[_L1] = LAYOUT_60_ansi( /* Base */
|
||||||
|
KC_ESC, KC_1, KC_2, KC_3, KC_4, KC_5, KC_6, KC_7, KC_8, KC_9, KC_0, KC_MINS, KC_EQL, KC_BSPC,
|
||||||
|
KC_TAB, KC_Q, KC_W, KC_E, KC_R, KC_T, KC_Y, KC_U, KC_I, KC_O, KC_P, KC_LBRC, KC_RBRC, KC_BSLS,
|
||||||
|
KC_CAPS, KC_A, KC_S, KC_D, KC_F, KC_G, KC_H, KC_J, KC_K, KC_L, KC_SCLN, KC_QUOT, KC_ENT,
|
||||||
|
KC_LSFT, KC_Z, KC_X, KC_C, KC_V, KC_B, KC_N, KC_M, KC_COMM, KC_DOT, KC_SLSH, KC_RSFT,
|
||||||
|
KC_LCTL, KC_LGUI, KC_LALT, KC_SPC, KC_RALT, KC_RGUI, MO(_L2), KC_RCTL
|
||||||
|
),
|
||||||
|
[_L2] = LAYOUT_60_ansi( /* Base */
|
||||||
|
RESET, KC_F1, KC_F2, KC_F3, KC_F4, KC_F5, KC_F6, KC_F7, KC_F8, KC_F9, KC_F10, KC_F11, KC_F12, KC_GRV,
|
||||||
|
_______, BL_TOGG, BL_INC, _______, _______, _______, _______, _______, _______, _______, _______, KC_PGUP, _______, KC_INSERT,
|
||||||
|
_______, _______, _______, _______, _______, _______, KC_LEFT, KC_DOWN, KC_UP, KC_RIGHT, KC_HOME, KC_END, _______,
|
||||||
|
_______, BL_DEC, _______, _______, _______, _______, _______, _______, _______, _______, KC_PGDOWN, _______,
|
||||||
|
_______, _______, _______, _______, _______, _______, _______, _______
|
||||||
|
)
|
||||||
|
};
|
||||||
|
|
||||||
|
void matrix_init_user(void) {
|
||||||
|
|
||||||
|
}
|
||||||
|
|
||||||
|
void matrix_scan_user(void) {
|
||||||
|
|
||||||
|
}
|
||||||
|
|
||||||
|
bool process_record_user(uint16_t keycode, keyrecord_t *record) {
|
||||||
|
return true;
|
||||||
|
}
|
||||||
|
|
||||||
|
void led_set_user(uint8_t usb_led) {
|
||||||
|
|
||||||
|
}
|
||||||
@@ -0,0 +1 @@
|
|||||||
|
# The default keymap for co60
|
||||||
@@ -0,0 +1,21 @@
|
|||||||
|
/* Copyright 2019 John M Daly <[email protected]>
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
|
||||||
|
#pragma once
|
||||||
|
|
||||||
|
#define LEADER_TIMEOUT 300
|
||||||
|
|
||||||
|
// place overrides here
|
||||||
@@ -0,0 +1,137 @@
|
|||||||
|
/* Copyright 2019 John M Daly <[email protected]>
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#include QMK_KEYBOARD_H
|
||||||
|
|
||||||
|
enum co60_layers {
|
||||||
|
_L1,
|
||||||
|
_L2,
|
||||||
|
_L3
|
||||||
|
};
|
||||||
|
|
||||||
|
const uint16_t PROGMEM keymaps[][MATRIX_ROWS][MATRIX_COLS] = {
|
||||||
|
// Default base layer. Except for the bottom row, this
|
||||||
|
// is close to a standard HHKB layout.
|
||||||
|
[_L1] = LAYOUT_60_hhkb_split_625u_space( /* Base */
|
||||||
|
KC_ESC, KC_1, KC_2, KC_3, KC_4, KC_5, KC_6, KC_7, KC_8, KC_9, KC_0, KC_MINS, KC_EQL, KC_BSLS, KC_GRV,
|
||||||
|
KC_TAB, KC_Q, KC_W, KC_E, KC_R, KC_T, KC_Y, KC_U, KC_I, KC_O, KC_P, KC_LBRC, KC_RBRC, KC_BSPC,
|
||||||
|
CTL_T(KC_ESC), KC_A, KC_S, KC_D, KC_F, KC_G, KC_H, KC_J, KC_K, KC_L, KC_SCLN, KC_QUOT, KC_ENT,
|
||||||
|
KC_LSPO, KC_Z, KC_X, KC_C, KC_V, KC_B, KC_N, KC_M, KC_COMM, KC_DOT, KC_SLSH, KC_RSPC, MO(_L3),
|
||||||
|
KC_LALT, KC_LGUI, KC_ENT, MO(_L3), KC_SPC, KC_LEAD, KC_RGUI, KC_RALT
|
||||||
|
),
|
||||||
|
// My preferred base layout. This doesn't match the caps
|
||||||
|
// on my boards, so I don't make it default.
|
||||||
|
[_L2] = LAYOUT_60_hhkb_split_625u_space( /* Base */
|
||||||
|
KC_GRV, KC_1, KC_2, KC_3, KC_4, KC_5, KC_6, KC_7, KC_8, KC_9, KC_0, KC_MINS, KC_EQL, KC_BSLS, KC_DEL,
|
||||||
|
KC_TAB, KC_Q, KC_W, KC_E, KC_R, KC_T, KC_Y, KC_U, KC_I, KC_O, KC_P, KC_LBRC, KC_RBRC, KC_BSPC,
|
||||||
|
CTL_T(KC_ESC), KC_A, KC_S, KC_D, KC_F, KC_G, KC_H, KC_J, KC_K, KC_L, KC_SCLN, KC_QUOT, KC_ENT,
|
||||||
|
KC_LSPO, KC_Z, KC_X, KC_C, KC_V, KC_B, KC_N, KC_M, KC_COMM, KC_DOT, KC_SLSH, KC_RSPC, MO(_L3),
|
||||||
|
KC_LALT, KC_LGUI, KC_ENT, MO(_L3), KC_SPC, KC_LEAD, KC_RGUI, KC_RALT
|
||||||
|
),
|
||||||
|
[_L3] = LAYOUT_60_hhkb_split_625u_space( /* Function */
|
||||||
|
RESET, KC_F1, KC_F2, KC_F3, KC_F4, KC_F5, KC_F6, KC_F7, KC_F8, KC_F9, KC_F10, KC_F11, KC_F12, _______, _______,
|
||||||
|
BL_BRTG, BL_TOGG, BL_INC, BL_DEC, BL_ON, BL_OFF, _______, _______, _______, _______, _______, KC_PGUP, KC_INSERT, KC_DEL,
|
||||||
|
_______, RGB_TOG, RGB_MOD, RGB_RMOD, _______, _______, KC_LEFT, KC_DOWN, KC_UP, KC_RIGHT, KC_HOME, KC_END, _______,
|
||||||
|
_______, BL_DEC, _______, _______, _______, _______, _______, DF(_L1), DF(_L2), _______, KC_PGDOWN, _______, _______,
|
||||||
|
_______, _______, _______, _______, _______, _______, _______, _______
|
||||||
|
)
|
||||||
|
};
|
||||||
|
|
||||||
|
void matrix_init_user(void) {
|
||||||
|
|
||||||
|
}
|
||||||
|
|
||||||
|
LEADER_EXTERNS();
|
||||||
|
|
||||||
|
void matrix_scan_user(void) {
|
||||||
|
|
||||||
|
LEADER_DICTIONARY() {
|
||||||
|
leading = false;
|
||||||
|
leader_end();
|
||||||
|
|
||||||
|
// Close a program in i3wm
|
||||||
|
SEQ_ONE_KEY(KC_Q) {
|
||||||
|
register_code(KC_LGUI);
|
||||||
|
register_code(KC_LSHIFT);
|
||||||
|
register_code(KC_Q);
|
||||||
|
unregister_code(KC_Q);
|
||||||
|
unregister_code(KC_LSHIFT);
|
||||||
|
unregister_code(KC_LGUI);
|
||||||
|
}
|
||||||
|
// Exit i3wm
|
||||||
|
SEQ_ONE_KEY(KC_E) {
|
||||||
|
register_code(KC_LGUI);
|
||||||
|
register_code(KC_LSHIFT);
|
||||||
|
register_code(KC_E);
|
||||||
|
unregister_code(KC_E);
|
||||||
|
unregister_code(KC_LSHIFT);
|
||||||
|
unregister_code(KC_LGUI);
|
||||||
|
}
|
||||||
|
// Copy selected text in suckless terminal
|
||||||
|
SEQ_ONE_KEY(KC_C) {
|
||||||
|
register_code(KC_LCTL);
|
||||||
|
register_code(KC_LSHIFT);
|
||||||
|
register_code(KC_C);
|
||||||
|
unregister_code(KC_C);
|
||||||
|
unregister_code(KC_LSHIFT);
|
||||||
|
unregister_code(KC_LCTL);
|
||||||
|
}
|
||||||
|
// Paste text in suckless terminal
|
||||||
|
SEQ_ONE_KEY(KC_V) {
|
||||||
|
register_code(KC_LCTL);
|
||||||
|
register_code(KC_LSHIFT);
|
||||||
|
register_code(KC_V);
|
||||||
|
unregister_code(KC_V);
|
||||||
|
unregister_code(KC_LSHIFT);
|
||||||
|
unregister_code(KC_LCTL);
|
||||||
|
}
|
||||||
|
// FZF shortcut to fuzzy switch directories
|
||||||
|
SEQ_ONE_KEY(KC_D) {
|
||||||
|
register_code(KC_LALT);
|
||||||
|
register_code(KC_C);
|
||||||
|
unregister_code(KC_C);
|
||||||
|
unregister_code(KC_LALT);
|
||||||
|
}
|
||||||
|
// Send keys to bring up fuzzy process kill
|
||||||
|
SEQ_ONE_KEY(KC_K) {
|
||||||
|
SEND_STRING("kill " SS_TAP(X_TAB));
|
||||||
|
}
|
||||||
|
// Send keys to start neovim and fuzzy search for filename
|
||||||
|
SEQ_ONE_KEY(KC_T) {
|
||||||
|
SEND_STRING("nvim ");
|
||||||
|
register_code(KC_LCTL);
|
||||||
|
register_code(KC_T);
|
||||||
|
unregister_code(KC_T);
|
||||||
|
unregister_code(KC_LCTL);
|
||||||
|
}
|
||||||
|
// Switch between windows in tmux
|
||||||
|
SEQ_ONE_KEY(KC_L) {
|
||||||
|
register_code(KC_LCTL);
|
||||||
|
register_code(KC_B);
|
||||||
|
unregister_code(KC_B);
|
||||||
|
unregister_code(KC_LCTL);
|
||||||
|
register_code(KC_L);
|
||||||
|
unregister_code(KC_L);
|
||||||
|
}
|
||||||
|
}
|
||||||
|
}
|
||||||
|
|
||||||
|
bool process_record_user(uint16_t keycode, keyrecord_t *record) {
|
||||||
|
return true;
|
||||||
|
}
|
||||||
|
|
||||||
|
void led_set_user(uint8_t usb_led) {
|
||||||
|
|
||||||
|
}
|
||||||
@@ -0,0 +1,6 @@
|
|||||||
|
# The split-space HHKB keymap for co60
|
||||||
|
|
||||||
|
This keymap implements a modified MX HHKB layout, but in addition to 7u space,
|
||||||
|
this layout supports a number of split spacebar bottom rows. The full set of
|
||||||
|
layout options is found
|
||||||
|
[here](http://www.keyboard-layout-editor.com/#/gists/b488496b3a71c8192113c07e298be340).
|
||||||
@@ -0,0 +1,26 @@
|
|||||||
|
# co60
|
||||||
|
|
||||||
|
The CO60 is a 60% PCB that aims to meet the following goals:
|
||||||
|
|
||||||
|
* Switches oriented such that the LEDs are South-facing, for
|
||||||
|
compatibility with Cherry profile keycaps.
|
||||||
|
* USB Type-C support in both A to C and C to C configurations.
|
||||||
|
* QMK support.
|
||||||
|
* A variety of split spacebar configurations, including split 6.25U
|
||||||
|
space and split 7U space.
|
||||||
|
* ESD protection circuitry, including data line protection and a
|
||||||
|
polyfuse on the VCC line.
|
||||||
|
* Support for per-switch LED backlighting.
|
||||||
|
* Fits in standard 60% keyboard cases.
|
||||||
|
|
||||||
|
More info on the project, including all of the design files, can be found [here](https://github.com/jmdaly/CO60).
|
||||||
|
|
||||||
|
Keyboard Maintainer: [jmdaly](https://github.com/jmdaly)
|
||||||
|
Hardware Supported: Supports the CO60 PCB rev1, rev6, rev7
|
||||||
|
Hardware Availability: Through group buys.
|
||||||
|
|
||||||
|
Make example for this keyboard (after setting up your build environment):
|
||||||
|
|
||||||
|
make handwired/co60/rev7:default
|
||||||
|
|
||||||
|
See the [build environment setup](https://docs.qmk.fm/#/getting_started_build_tools) and the [make instructions](https://docs.qmk.fm/#/getting_started_make_guide) for more information. Brand new to QMK? Start with our [Complete Newbs Guide](https://docs.qmk.fm/#/newbs).
|
||||||
@@ -0,0 +1,161 @@
|
|||||||
|
/*
|
||||||
|
Copyright 2018 John M Daly <[email protected]>
|
||||||
|
|
||||||
|
This program is free software: you can redistribute it and/or modify
|
||||||
|
it under the terms of the GNU General Public License as published by
|
||||||
|
the Free Software Foundation, either version 2 of the License, or
|
||||||
|
(at your option) any later version.
|
||||||
|
|
||||||
|
This program is distributed in the hope that it will be useful,
|
||||||
|
but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
GNU General Public License for more details.
|
||||||
|
|
||||||
|
You should have received a copy of the GNU General Public License
|
||||||
|
along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
|
||||||
|
#pragma once
|
||||||
|
|
||||||
|
#include "config_common.h"
|
||||||
|
|
||||||
|
/* USB Device descriptor parameter */
|
||||||
|
#define VENDOR_ID 0xFEED
|
||||||
|
#define PRODUCT_ID 0x0000
|
||||||
|
#define DEVICE_VER 0x0001
|
||||||
|
#define MANUFACTURER John M Daly
|
||||||
|
#define PRODUCT CO60
|
||||||
|
#define DESCRIPTION An open hardware sixty percent PCB
|
||||||
|
|
||||||
|
/* key matrix size */
|
||||||
|
#define MATRIX_ROWS 5
|
||||||
|
#define MATRIX_COLS 15
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Keyboard Matrix Assignments
|
||||||
|
*
|
||||||
|
* Change this to how you wired your keyboard
|
||||||
|
* COLS: AVR pins used for columns, left to right
|
||||||
|
* ROWS: AVR pins used for rows, top to bottom
|
||||||
|
* DIODE_DIRECTION: COL2ROW = COL = Anode (+), ROW = Cathode (-, marked on diode)
|
||||||
|
* ROW2COL = ROW = Anode (+), COL = Cathode (-, marked on diode)
|
||||||
|
*
|
||||||
|
*/
|
||||||
|
#define MATRIX_ROW_PINS { D0, D1, D2, D3, D5 }
|
||||||
|
#define MATRIX_COL_PINS { F0, F1, E6, C7, C6, B6, D4, B1, B2, B5, B4, D7, D6, B3, B0 }
|
||||||
|
#define UNUSED_PINS
|
||||||
|
|
||||||
|
/* COL2ROW, ROW2COL, or CUSTOM_MATRIX */
|
||||||
|
#define DIODE_DIRECTION COL2ROW
|
||||||
|
|
||||||
|
#ifdef __AVR__
|
||||||
|
#define BACKLIGHT_PIN B7
|
||||||
|
#define BACKLIGHT_BREATHING
|
||||||
|
#endif
|
||||||
|
#define BACKLIGHT_LEVELS 3
|
||||||
|
|
||||||
|
|
||||||
|
/* Debounce reduces chatter (unintended double-presses) - set 0 if debouncing is not needed */
|
||||||
|
#define DEBOUNCE 5
|
||||||
|
|
||||||
|
/* define if matrix has ghost (lacks anti-ghosting diodes) */
|
||||||
|
//#define MATRIX_HAS_GHOST
|
||||||
|
|
||||||
|
/* number of backlight levels */
|
||||||
|
|
||||||
|
/* Mechanical locking support. Use KC_LCAP, KC_LNUM or KC_LSCR instead in keymap */
|
||||||
|
// #define LOCKING_SUPPORT_ENABLE
|
||||||
|
/* Locking resynchronize hack */
|
||||||
|
#define LOCKING_RESYNC_ENABLE
|
||||||
|
|
||||||
|
/* If defined, GRAVE_ESC will always act as ESC when CTRL is held.
|
||||||
|
* This is userful for the Windows task manager shortcut (ctrl+shift+esc).
|
||||||
|
*/
|
||||||
|
// #define GRAVE_ESC_CTRL_OVERRIDE
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Force NKRO
|
||||||
|
*
|
||||||
|
* Force NKRO (nKey Rollover) to be enabled by default, regardless of the saved
|
||||||
|
* state in the bootmagic EEPROM settings. (Note that NKRO must be enabled in the
|
||||||
|
* makefile for this to work.)
|
||||||
|
*
|
||||||
|
* If forced on, NKRO can be disabled via magic key (default = LShift+RShift+N)
|
||||||
|
* until the next keyboard reset.
|
||||||
|
*
|
||||||
|
* NKRO may prevent your keystrokes from being detected in the BIOS, but it is
|
||||||
|
* fully operational during normal computer usage.
|
||||||
|
*
|
||||||
|
* For a less heavy-handed approach, enable NKRO via magic key (LShift+RShift+N)
|
||||||
|
* or via bootmagic (hold SPACE+N while plugging in the keyboard). Once set by
|
||||||
|
* bootmagic, NKRO mode will always be enabled until it is toggled again during a
|
||||||
|
* power-up.
|
||||||
|
*
|
||||||
|
*/
|
||||||
|
//#define FORCE_NKRO
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Magic Key Options
|
||||||
|
*
|
||||||
|
* Magic keys are hotkey commands that allow control over firmware functions of
|
||||||
|
* the keyboard. They are best used in combination with the HID Listen program,
|
||||||
|
* found here: https://www.pjrc.com/teensy/hid_listen.html
|
||||||
|
*
|
||||||
|
* The options below allow the magic key functionality to be changed. This is
|
||||||
|
* useful if your keyboard/keypad is missing keys and you want magic key support.
|
||||||
|
*
|
||||||
|
*/
|
||||||
|
|
||||||
|
/* control how magic key switches layers */
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_FKEYS true
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_NKEYS true
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_CUSTOM false
|
||||||
|
|
||||||
|
/* override magic key keymap */
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_FKEYS
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_NKEYS
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_CUSTOM
|
||||||
|
//#define MAGIC_KEY_HELP1 H
|
||||||
|
//#define MAGIC_KEY_HELP2 SLASH
|
||||||
|
//#define MAGIC_KEY_DEBUG D
|
||||||
|
//#define MAGIC_KEY_DEBUG_MATRIX X
|
||||||
|
//#define MAGIC_KEY_DEBUG_KBD K
|
||||||
|
//#define MAGIC_KEY_DEBUG_MOUSE M
|
||||||
|
//#define MAGIC_KEY_VERSION V
|
||||||
|
//#define MAGIC_KEY_STATUS S
|
||||||
|
//#define MAGIC_KEY_CONSOLE C
|
||||||
|
//#define MAGIC_KEY_LAYER0_ALT1 ESC
|
||||||
|
//#define MAGIC_KEY_LAYER0_ALT2 GRAVE
|
||||||
|
//#define MAGIC_KEY_LAYER0 0
|
||||||
|
//#define MAGIC_KEY_LAYER1 1
|
||||||
|
//#define MAGIC_KEY_LAYER2 2
|
||||||
|
//#define MAGIC_KEY_LAYER3 3
|
||||||
|
//#define MAGIC_KEY_LAYER4 4
|
||||||
|
//#define MAGIC_KEY_LAYER5 5
|
||||||
|
//#define MAGIC_KEY_LAYER6 6
|
||||||
|
//#define MAGIC_KEY_LAYER7 7
|
||||||
|
//#define MAGIC_KEY_LAYER8 8
|
||||||
|
//#define MAGIC_KEY_LAYER9 9
|
||||||
|
//#define MAGIC_KEY_BOOTLOADER PAUSE
|
||||||
|
//#define MAGIC_KEY_LOCK CAPS
|
||||||
|
//#define MAGIC_KEY_EEPROM E
|
||||||
|
//#define MAGIC_KEY_NKRO N
|
||||||
|
//#define MAGIC_KEY_SLEEP_LED Z
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Feature disable options
|
||||||
|
* These options are also useful to firmware size reduction.
|
||||||
|
*/
|
||||||
|
|
||||||
|
/* disable debug print */
|
||||||
|
//#define NO_DEBUG
|
||||||
|
|
||||||
|
/* disable print */
|
||||||
|
//#define NO_PRINT
|
||||||
|
|
||||||
|
/* disable action features */
|
||||||
|
//#define NO_ACTION_LAYER
|
||||||
|
//#define NO_ACTION_TAPPING
|
||||||
|
//#define NO_ACTION_ONESHOT
|
||||||
|
//#define NO_ACTION_MACRO
|
||||||
|
//#define NO_ACTION_FUNCTION
|
||||||
@@ -0,0 +1,46 @@
|
|||||||
|
/* Copyright 2018 John M Daly
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#include "rev1.h"
|
||||||
|
|
||||||
|
__attribute__ ((weak))
|
||||||
|
void matrix_init_kb(void) {
|
||||||
|
// put your keyboard start-up code here
|
||||||
|
// runs once when the firmware starts up
|
||||||
|
|
||||||
|
matrix_init_user();
|
||||||
|
}
|
||||||
|
|
||||||
|
__attribute__ ((weak))
|
||||||
|
void matrix_scan_kb(void) {
|
||||||
|
// put your looping keyboard code here
|
||||||
|
// runs every cycle (a lot)
|
||||||
|
|
||||||
|
matrix_scan_user();
|
||||||
|
}
|
||||||
|
|
||||||
|
bool process_record_kb(uint16_t keycode, keyrecord_t *record) {
|
||||||
|
// put your per-action keyboard code here
|
||||||
|
// runs for every action, just before processing by the firmware
|
||||||
|
|
||||||
|
return process_record_user(keycode, record);
|
||||||
|
}
|
||||||
|
|
||||||
|
__attribute__ ((weak))
|
||||||
|
void led_set_kb(uint8_t usb_led) {
|
||||||
|
// put your keyboard LED indicator (ex: Caps Lock LED) toggling code here
|
||||||
|
|
||||||
|
led_set_user(usb_led);
|
||||||
|
}
|
||||||
@@ -0,0 +1,127 @@
|
|||||||
|
/* Copyright 2018 John M Daly
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#pragma once
|
||||||
|
|
||||||
|
#include "quantum.h"
|
||||||
|
|
||||||
|
// This a shortcut to help you visually see your layout.
|
||||||
|
// The following is a layout that uses all available switch positions.
|
||||||
|
// The first section contains all of the arguments
|
||||||
|
// The second converts the arguments into a two-dimensional array
|
||||||
|
#define LAYOUT_all( \
|
||||||
|
K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014, \
|
||||||
|
K100, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114, \
|
||||||
|
K200, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K213, K214, \
|
||||||
|
K300, K301, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, K313, K314, \
|
||||||
|
K400, K401, K402, K404, K406, K408, K410, K411, K412, K413, K414 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014 }, \
|
||||||
|
{ K100, KC_NO, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114 }, \
|
||||||
|
{ K200, KC_NO, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K213, K214 }, \
|
||||||
|
{ K300, K301, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, KC_NO, K313, K314 }, \
|
||||||
|
{ K400, K401, K402, KC_NO, K404, KC_NO, K406, KC_NO, K408, KC_NO, K410, K411, K412, K413, K414 }, \
|
||||||
|
}
|
||||||
|
|
||||||
|
#define LAYOUT_60_ansi( \
|
||||||
|
K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K014, \
|
||||||
|
K100, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114, \
|
||||||
|
K200, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K214, \
|
||||||
|
K300, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, K313, \
|
||||||
|
K400, K401, K402, K406, K410, K411, K413, K414 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, KC_NO, K014 }, \
|
||||||
|
{ K100, KC_NO, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114 }, \
|
||||||
|
{ K200, KC_NO, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, KC_NO, K214 }, \
|
||||||
|
{ K300, KC_NO, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, KC_NO, K313, KC_NO }, \
|
||||||
|
{ K400, K401, K402, KC_NO, KC_NO, KC_NO, K406, KC_NO, KC_NO, KC_NO, K410, K411, KC_NO, K413, K414 }, \
|
||||||
|
}
|
||||||
|
|
||||||
|
#define LAYOUT_60_ansi_split_bs_rshift( \
|
||||||
|
K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014, \
|
||||||
|
K100, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114, \
|
||||||
|
K200, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K214, \
|
||||||
|
K300, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, K313, K314, \
|
||||||
|
K400, K401, K402, K406, K410, K411, K413, K414 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014 }, \
|
||||||
|
{ K100, KC_NO, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114 }, \
|
||||||
|
{ K200, KC_NO, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, KC_NO, K214 }, \
|
||||||
|
{ K300, KC_NO, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, KC_NO, K313, K314 }, \
|
||||||
|
{ K400, K401, K402, KC_NO, KC_NO, KC_NO, K406, KC_NO, KC_NO, KC_NO, K410, K411, KC_NO, K413, K414 }, \
|
||||||
|
}
|
||||||
|
|
||||||
|
#define LAYOUT_60_iso( \
|
||||||
|
K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K014, \
|
||||||
|
K100, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, \
|
||||||
|
K200, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K213, K214, \
|
||||||
|
K300, K301, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, K313, \
|
||||||
|
K400, K401, K402, K406, K410, K411, K413, K414 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, KC_NO, K014 }, \
|
||||||
|
{ K100, KC_NO, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, KC_NO }, \
|
||||||
|
{ K200, KC_NO, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K213, K214 }, \
|
||||||
|
{ K300, K301, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, KC_NO, K313, KC_NO }, \
|
||||||
|
{ K400, K401, K402, KC_NO, KC_NO, KC_NO, K406, KC_NO, KC_NO, KC_NO, K410, K411, KC_NO, K413, K414 }, \
|
||||||
|
}
|
||||||
|
|
||||||
|
#define LAYOUT_60_hhkb( \
|
||||||
|
K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014, \
|
||||||
|
K100, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114, \
|
||||||
|
K200, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K214, \
|
||||||
|
K300, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, K313, K314, \
|
||||||
|
K401, K402, K406, K411, K413 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014 }, \
|
||||||
|
{ K100, KC_NO, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114 }, \
|
||||||
|
{ K200, KC_NO, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, KC_NO, K214 }, \
|
||||||
|
{ K300, KC_NO, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, KC_NO, K313, K314 }, \
|
||||||
|
{ KC_NO, K401, K402, KC_NO, KC_NO, KC_NO, K406, KC_NO, KC_NO, KC_NO, KC_NO, K411, KC_NO, K413, KC_NO }, \
|
||||||
|
}
|
||||||
|
|
||||||
|
#define LAYOUT_60_hhkb_split_space( \
|
||||||
|
K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014, \
|
||||||
|
K100, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114, \
|
||||||
|
K200, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K214, \
|
||||||
|
K300, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, K313, K314, \
|
||||||
|
K401, K402, K404, K406, K408, K411, K413 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014 }, \
|
||||||
|
{ K100, KC_NO, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114 }, \
|
||||||
|
{ K200, KC_NO, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, KC_NO, K214 }, \
|
||||||
|
{ K300, KC_NO, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, KC_NO, K313, K314 }, \
|
||||||
|
{ KC_NO, K401, K402, KC_NO, K404, KC_NO, K406, KC_NO, K408, KC_NO, KC_NO, K411, KC_NO, K413, KC_NO }, \
|
||||||
|
}
|
||||||
|
|
||||||
|
#define LAYOUT_60_hhkb_split_625u_space( \
|
||||||
|
K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014, \
|
||||||
|
K100, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114, \
|
||||||
|
K200, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K214, \
|
||||||
|
K300, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, K313, K314, \
|
||||||
|
K401, K402, K404, K406, K408, K410, K411, K413 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014 }, \
|
||||||
|
{ K100, KC_NO, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114 }, \
|
||||||
|
{ K200, KC_NO, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, KC_NO, K214 }, \
|
||||||
|
{ K300, KC_NO, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, KC_NO, K313, K314 }, \
|
||||||
|
{ KC_NO, K401, K402, KC_NO, K404, KC_NO, K406, KC_NO, K408, KC_NO, K410, K411, KC_NO, K413, KC_NO }, \
|
||||||
|
}
|
||||||
@@ -0,0 +1,70 @@
|
|||||||
|
# MCU name
|
||||||
|
MCU = atmega32u4
|
||||||
|
|
||||||
|
# Processor frequency.
|
||||||
|
# This will define a symbol, F_CPU, in all source code files equal to the
|
||||||
|
# processor frequency in Hz. You can then use this symbol in your source code to
|
||||||
|
# calculate timings. Do NOT tack on a 'UL' at the end, this will be done
|
||||||
|
# automatically to create a 32-bit value in your source code.
|
||||||
|
#
|
||||||
|
# This will be an integer division of F_USB below, as it is sourced by
|
||||||
|
# F_USB after it has run through any CPU prescalers. Note that this value
|
||||||
|
# does not *change* the processor frequency - it should merely be updated to
|
||||||
|
# reflect the processor speed set externally so that the code can use accurate
|
||||||
|
# software delays.
|
||||||
|
F_CPU = 16000000
|
||||||
|
|
||||||
|
|
||||||
|
#
|
||||||
|
# LUFA specific
|
||||||
|
#
|
||||||
|
# Target architecture (see library "Board Types" documentation).
|
||||||
|
ARCH = AVR8
|
||||||
|
|
||||||
|
# Input clock frequency.
|
||||||
|
# This will define a symbol, F_USB, in all source code files equal to the
|
||||||
|
# input clock frequency (before any prescaling is performed) in Hz. This value may
|
||||||
|
# differ from F_CPU if prescaling is used on the latter, and is required as the
|
||||||
|
# raw input clock is fed directly to the PLL sections of the AVR for high speed
|
||||||
|
# clock generation for the USB and other AVR subsections. Do NOT tack on a 'UL'
|
||||||
|
# at the end, this will be done automatically to create a 32-bit value in your
|
||||||
|
# source code.
|
||||||
|
#
|
||||||
|
# If no clock division is performed on the input clock inside the AVR (via the
|
||||||
|
# CPU clock adjust registers or the clock division fuses), this will be equal to F_CPU.
|
||||||
|
F_USB = $(F_CPU)
|
||||||
|
|
||||||
|
# Interrupt driven control endpoint task(+60)
|
||||||
|
OPT_DEFS += -DINTERRUPT_CONTROL_ENDPOINT
|
||||||
|
|
||||||
|
# Bootloader selection
|
||||||
|
# Teensy halfkay
|
||||||
|
# Pro Micro caterina
|
||||||
|
# Atmel DFU atmel-dfu
|
||||||
|
# LUFA DFU lufa-dfu
|
||||||
|
# QMK DFU qmk-dfu
|
||||||
|
# atmega32a bootloadHID
|
||||||
|
BOOTLOADER = atmel-dfu
|
||||||
|
|
||||||
|
# Build Options
|
||||||
|
# change yes to no to disable
|
||||||
|
#
|
||||||
|
BOOTMAGIC_ENABLE = yes # Virtual DIP switch configuration(+1000)
|
||||||
|
MOUSEKEY_ENABLE = yes # Mouse keys(+4700)
|
||||||
|
EXTRAKEY_ENABLE = yes # Audio control and System control(+450)
|
||||||
|
CONSOLE_ENABLE = no # Console for debug(+400)
|
||||||
|
COMMAND_ENABLE = no # Commands for debug and configuration
|
||||||
|
# Do not enable SLEEP_LED_ENABLE. it uses the same timer as BACKLIGHT_ENABLE
|
||||||
|
SLEEP_LED_ENABLE = no # Breathing sleep LED during USB suspend
|
||||||
|
# if this doesn't work, see here: https://github.com/tmk/tmk_keyboard/wiki/FAQ#nkro-doesnt-work
|
||||||
|
NKRO_ENABLE = yes # USB Nkey Rollover
|
||||||
|
BACKLIGHT_ENABLE = yes # Enable keyboard backlight functionality on B7 by default
|
||||||
|
MIDI_ENABLE = no # MIDI support (+2400 to 4200, depending on config)
|
||||||
|
UNICODE_ENABLE = no # Unicode
|
||||||
|
BLUETOOTH_ENABLE = no # Enable Bluetooth with the Adafruit EZ-Key HID
|
||||||
|
AUDIO_ENABLE = no # Audio output on port C6
|
||||||
|
FAUXCLICKY_ENABLE = no # Use buzzer to emulate clicky switches
|
||||||
|
LEADER_ENABLE = yes # Turn on leader support
|
||||||
|
|
||||||
|
# Layouts supported by this PCB:
|
||||||
|
LAYOUTS = 60_ansi 60_iso 60_ansi_split_bs_rshift 60_hhkb
|
||||||
@@ -0,0 +1,520 @@
|
|||||||
|
/*
|
||||||
|
ChibiOS - Copyright (C) 2006..2016 Giovanni Di Sirio
|
||||||
|
|
||||||
|
Licensed under the Apache License, Version 2.0 (the "License");
|
||||||
|
you may not use this file except in compliance with the License.
|
||||||
|
You may obtain a copy of the License at
|
||||||
|
|
||||||
|
http://www.apache.org/licenses/LICENSE-2.0
|
||||||
|
|
||||||
|
Unless required by applicable law or agreed to in writing, software
|
||||||
|
distributed under the License is distributed on an "AS IS" BASIS,
|
||||||
|
WITHOUT WARRANTIES OR CONDITIONS OF ANY KIND, either express or implied.
|
||||||
|
See the License for the specific language governing permissions and
|
||||||
|
limitations under the License.
|
||||||
|
*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @file templates/chconf.h
|
||||||
|
* @brief Configuration file template.
|
||||||
|
* @details A copy of this file must be placed in each project directory, it
|
||||||
|
* contains the application specific kernel settings.
|
||||||
|
*
|
||||||
|
* @addtogroup config
|
||||||
|
* @details Kernel related settings and hooks.
|
||||||
|
* @{
|
||||||
|
*/
|
||||||
|
|
||||||
|
#ifndef CHCONF_H
|
||||||
|
#define CHCONF_H
|
||||||
|
|
||||||
|
#define _CHIBIOS_RT_CONF_
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/**
|
||||||
|
* @name System timers settings
|
||||||
|
* @{
|
||||||
|
*/
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief System time counter resolution.
|
||||||
|
* @note Allowed values are 16 or 32 bits.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_ST_RESOLUTION 32
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief System tick frequency.
|
||||||
|
* @details Frequency of the system timer that drives the system ticks. This
|
||||||
|
* setting also defines the system tick time unit.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_ST_FREQUENCY 100000
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Time delta constant for the tick-less mode.
|
||||||
|
* @note If this value is zero then the system uses the classic
|
||||||
|
* periodic tick. This value represents the minimum number
|
||||||
|
* of ticks that is safe to specify in a timeout directive.
|
||||||
|
* The value one is not valid, timeouts are rounded up to
|
||||||
|
* this value.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_ST_TIMEDELTA 2
|
||||||
|
|
||||||
|
/** @} */
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/**
|
||||||
|
* @name Kernel parameters and options
|
||||||
|
* @{
|
||||||
|
*/
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Round robin interval.
|
||||||
|
* @details This constant is the number of system ticks allowed for the
|
||||||
|
* threads before preemption occurs. Setting this value to zero
|
||||||
|
* disables the preemption for threads with equal priority and the
|
||||||
|
* round robin becomes cooperative. Note that higher priority
|
||||||
|
* threads can still preempt, the kernel is always preemptive.
|
||||||
|
* @note Disabling the round robin preemption makes the kernel more compact
|
||||||
|
* and generally faster.
|
||||||
|
* @note The round robin preemption is not supported in tickless mode and
|
||||||
|
* must be set to zero in that case.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_TIME_QUANTUM 0
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Managed RAM size.
|
||||||
|
* @details Size of the RAM area to be managed by the OS. If set to zero
|
||||||
|
* then the whole available RAM is used. The core memory is made
|
||||||
|
* available to the heap allocator and/or can be used directly through
|
||||||
|
* the simplified core memory allocator.
|
||||||
|
*
|
||||||
|
* @note In order to let the OS manage the whole RAM the linker script must
|
||||||
|
* provide the @p __heap_base__ and @p __heap_end__ symbols.
|
||||||
|
* @note Requires @p CH_CFG_USE_MEMCORE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_MEMCORE_SIZE 0
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Idle thread automatic spawn suppression.
|
||||||
|
* @details When this option is activated the function @p chSysInit()
|
||||||
|
* does not spawn the idle thread. The application @p main()
|
||||||
|
* function becomes the idle thread and must implement an
|
||||||
|
* infinite loop.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_NO_IDLE_THREAD FALSE
|
||||||
|
|
||||||
|
/** @} */
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/**
|
||||||
|
* @name Performance options
|
||||||
|
* @{
|
||||||
|
*/
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief OS optimization.
|
||||||
|
* @details If enabled then time efficient rather than space efficient code
|
||||||
|
* is used when two possible implementations exist.
|
||||||
|
*
|
||||||
|
* @note This is not related to the compiler optimization options.
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_OPTIMIZE_SPEED TRUE
|
||||||
|
|
||||||
|
/** @} */
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/**
|
||||||
|
* @name Subsystem options
|
||||||
|
* @{
|
||||||
|
*/
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Time Measurement APIs.
|
||||||
|
* @details If enabled then the time measurement APIs are included in
|
||||||
|
* the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_TM TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Threads registry APIs.
|
||||||
|
* @details If enabled then the registry APIs are included in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_REGISTRY TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Threads synchronization APIs.
|
||||||
|
* @details If enabled then the @p chThdWait() function is included in
|
||||||
|
* the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_WAITEXIT TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Semaphores APIs.
|
||||||
|
* @details If enabled then the Semaphores APIs are included in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_SEMAPHORES TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Semaphores queuing mode.
|
||||||
|
* @details If enabled then the threads are enqueued on semaphores by
|
||||||
|
* priority rather than in FIFO order.
|
||||||
|
*
|
||||||
|
* @note The default is @p FALSE. Enable this if you have special
|
||||||
|
* requirements.
|
||||||
|
* @note Requires @p CH_CFG_USE_SEMAPHORES.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_SEMAPHORES_PRIORITY FALSE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Mutexes APIs.
|
||||||
|
* @details If enabled then the mutexes APIs are included in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_MUTEXES TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables recursive behavior on mutexes.
|
||||||
|
* @note Recursive mutexes are heavier and have an increased
|
||||||
|
* memory footprint.
|
||||||
|
*
|
||||||
|
* @note The default is @p FALSE.
|
||||||
|
* @note Requires @p CH_CFG_USE_MUTEXES.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_MUTEXES_RECURSIVE FALSE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Conditional Variables APIs.
|
||||||
|
* @details If enabled then the conditional variables APIs are included
|
||||||
|
* in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
* @note Requires @p CH_CFG_USE_MUTEXES.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_CONDVARS TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Conditional Variables APIs with timeout.
|
||||||
|
* @details If enabled then the conditional variables APIs with timeout
|
||||||
|
* specification are included in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
* @note Requires @p CH_CFG_USE_CONDVARS.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_CONDVARS_TIMEOUT TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Events Flags APIs.
|
||||||
|
* @details If enabled then the event flags APIs are included in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_EVENTS TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Events Flags APIs with timeout.
|
||||||
|
* @details If enabled then the events APIs with timeout specification
|
||||||
|
* are included in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
* @note Requires @p CH_CFG_USE_EVENTS.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_EVENTS_TIMEOUT TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Synchronous Messages APIs.
|
||||||
|
* @details If enabled then the synchronous messages APIs are included
|
||||||
|
* in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_MESSAGES TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Synchronous Messages queuing mode.
|
||||||
|
* @details If enabled then messages are served by priority rather than in
|
||||||
|
* FIFO order.
|
||||||
|
*
|
||||||
|
* @note The default is @p FALSE. Enable this if you have special
|
||||||
|
* requirements.
|
||||||
|
* @note Requires @p CH_CFG_USE_MESSAGES.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_MESSAGES_PRIORITY TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Mailboxes APIs.
|
||||||
|
* @details If enabled then the asynchronous messages (mailboxes) APIs are
|
||||||
|
* included in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
* @note Requires @p CH_CFG_USE_SEMAPHORES.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_MAILBOXES TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Core Memory Manager APIs.
|
||||||
|
* @details If enabled then the core memory manager APIs are included
|
||||||
|
* in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_MEMCORE TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Heap Allocator APIs.
|
||||||
|
* @details If enabled then the memory heap allocator APIs are included
|
||||||
|
* in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
* @note Requires @p CH_CFG_USE_MEMCORE and either @p CH_CFG_USE_MUTEXES or
|
||||||
|
* @p CH_CFG_USE_SEMAPHORES.
|
||||||
|
* @note Mutexes are recommended.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_HEAP TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Memory Pools Allocator APIs.
|
||||||
|
* @details If enabled then the memory pools allocator APIs are included
|
||||||
|
* in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_MEMPOOLS TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Dynamic Threads APIs.
|
||||||
|
* @details If enabled then the dynamic threads creation APIs are included
|
||||||
|
* in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
* @note Requires @p CH_CFG_USE_WAITEXIT.
|
||||||
|
* @note Requires @p CH_CFG_USE_HEAP and/or @p CH_CFG_USE_MEMPOOLS.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_DYNAMIC TRUE
|
||||||
|
|
||||||
|
/** @} */
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/**
|
||||||
|
* @name Debug options
|
||||||
|
* @{
|
||||||
|
*/
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Debug option, kernel statistics.
|
||||||
|
*
|
||||||
|
* @note The default is @p FALSE.
|
||||||
|
*/
|
||||||
|
#define CH_DBG_STATISTICS FALSE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Debug option, system state check.
|
||||||
|
* @details If enabled the correct call protocol for system APIs is checked
|
||||||
|
* at runtime.
|
||||||
|
*
|
||||||
|
* @note The default is @p FALSE.
|
||||||
|
*/
|
||||||
|
#define CH_DBG_SYSTEM_STATE_CHECK FALSE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Debug option, parameters checks.
|
||||||
|
* @details If enabled then the checks on the API functions input
|
||||||
|
* parameters are activated.
|
||||||
|
*
|
||||||
|
* @note The default is @p FALSE.
|
||||||
|
*/
|
||||||
|
#define CH_DBG_ENABLE_CHECKS FALSE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Debug option, consistency checks.
|
||||||
|
* @details If enabled then all the assertions in the kernel code are
|
||||||
|
* activated. This includes consistency checks inside the kernel,
|
||||||
|
* runtime anomalies and port-defined checks.
|
||||||
|
*
|
||||||
|
* @note The default is @p FALSE.
|
||||||
|
*/
|
||||||
|
#define CH_DBG_ENABLE_ASSERTS FALSE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Debug option, trace buffer.
|
||||||
|
* @details If enabled then the trace buffer is activated.
|
||||||
|
*
|
||||||
|
* @note The default is @p CH_DBG_TRACE_MASK_DISABLED.
|
||||||
|
*/
|
||||||
|
#define CH_DBG_TRACE_MASK CH_DBG_TRACE_MASK_DISABLED
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Trace buffer entries.
|
||||||
|
* @note The trace buffer is only allocated if @p CH_DBG_TRACE_MASK is
|
||||||
|
* different from @p CH_DBG_TRACE_MASK_DISABLED.
|
||||||
|
*/
|
||||||
|
#define CH_DBG_TRACE_BUFFER_SIZE 128
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Debug option, stack checks.
|
||||||
|
* @details If enabled then a runtime stack check is performed.
|
||||||
|
*
|
||||||
|
* @note The default is @p FALSE.
|
||||||
|
* @note The stack check is performed in a architecture/port dependent way.
|
||||||
|
* It may not be implemented or some ports.
|
||||||
|
* @note The default failure mode is to halt the system with the global
|
||||||
|
* @p panic_msg variable set to @p NULL.
|
||||||
|
*/
|
||||||
|
#define CH_DBG_ENABLE_STACK_CHECK TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Debug option, stacks initialization.
|
||||||
|
* @details If enabled then the threads working area is filled with a byte
|
||||||
|
* value when a thread is created. This can be useful for the
|
||||||
|
* runtime measurement of the used stack.
|
||||||
|
*
|
||||||
|
* @note The default is @p FALSE.
|
||||||
|
*/
|
||||||
|
#define CH_DBG_FILL_THREADS FALSE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Debug option, threads profiling.
|
||||||
|
* @details If enabled then a field is added to the @p thread_t structure that
|
||||||
|
* counts the system ticks occurred while executing the thread.
|
||||||
|
*
|
||||||
|
* @note The default is @p FALSE.
|
||||||
|
* @note This debug option is not currently compatible with the
|
||||||
|
* tickless mode.
|
||||||
|
*/
|
||||||
|
#define CH_DBG_THREADS_PROFILING FALSE
|
||||||
|
|
||||||
|
/** @} */
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/**
|
||||||
|
* @name Kernel hooks
|
||||||
|
* @{
|
||||||
|
*/
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Threads descriptor structure extension.
|
||||||
|
* @details User fields added to the end of the @p thread_t structure.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_THREAD_EXTRA_FIELDS \
|
||||||
|
/* Add threads custom fields here.*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Threads initialization hook.
|
||||||
|
* @details User initialization code added to the @p chThdInit() API.
|
||||||
|
*
|
||||||
|
* @note It is invoked from within @p chThdInit() and implicitly from all
|
||||||
|
* the threads creation APIs.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_THREAD_INIT_HOOK(tp) { \
|
||||||
|
/* Add threads initialization code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Threads finalization hook.
|
||||||
|
* @details User finalization code added to the @p chThdExit() API.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_THREAD_EXIT_HOOK(tp) { \
|
||||||
|
/* Add threads finalization code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Context switch hook.
|
||||||
|
* @details This hook is invoked just before switching between threads.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_CONTEXT_SWITCH_HOOK(ntp, otp) { \
|
||||||
|
/* Context switch code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief ISR enter hook.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_IRQ_PROLOGUE_HOOK() { \
|
||||||
|
/* IRQ prologue code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief ISR exit hook.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_IRQ_EPILOGUE_HOOK() { \
|
||||||
|
/* IRQ epilogue code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Idle thread enter hook.
|
||||||
|
* @note This hook is invoked within a critical zone, no OS functions
|
||||||
|
* should be invoked from here.
|
||||||
|
* @note This macro can be used to activate a power saving mode.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_IDLE_ENTER_HOOK() { \
|
||||||
|
/* Idle-enter code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Idle thread leave hook.
|
||||||
|
* @note This hook is invoked within a critical zone, no OS functions
|
||||||
|
* should be invoked from here.
|
||||||
|
* @note This macro can be used to deactivate a power saving mode.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_IDLE_LEAVE_HOOK() { \
|
||||||
|
/* Idle-leave code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Idle Loop hook.
|
||||||
|
* @details This hook is continuously invoked by the idle thread loop.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_IDLE_LOOP_HOOK() { \
|
||||||
|
/* Idle loop code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief System tick event hook.
|
||||||
|
* @details This hook is invoked in the system tick handler immediately
|
||||||
|
* after processing the virtual timers queue.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_SYSTEM_TICK_HOOK() { \
|
||||||
|
/* System tick event code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief System halt hook.
|
||||||
|
* @details This hook is invoked in case to a system halting error before
|
||||||
|
* the system is halted.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_SYSTEM_HALT_HOOK(reason) { \
|
||||||
|
/* System halt code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Trace hook.
|
||||||
|
* @details This hook is invoked each time a new record is written in the
|
||||||
|
* trace buffer.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_TRACE_HOOK(tep) { \
|
||||||
|
/* Trace code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/** @} */
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* Port-specific settings (override port settings defaulted in chcore.h). */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
#endif /* CHCONF_H */
|
||||||
|
|
||||||
|
/** @} */
|
||||||
@@ -0,0 +1,60 @@
|
|||||||
|
/*
|
||||||
|
* Copyright 2019 John M Daly <[email protected]>
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#pragma once
|
||||||
|
|
||||||
|
#include "config_common.h"
|
||||||
|
|
||||||
|
/* USB Device descriptor parameter */
|
||||||
|
#define VENDOR_ID 0xFEED
|
||||||
|
#define PRODUCT_ID 0x0000
|
||||||
|
#define DEVICE_VER 0x0001
|
||||||
|
#define MANUFACTURER John M Daly
|
||||||
|
#define PRODUCT CO60 rev6
|
||||||
|
#define DESCRIPTION An open hardware sixty percent PCB
|
||||||
|
|
||||||
|
/* Address for jumping to bootloader on STM32 chips. */
|
||||||
|
/* It is chip dependent, the correct number can be looked up here:
|
||||||
|
* http://www.st.com/web/en/resource/technical/document/application_note/CD00167594.pdf
|
||||||
|
*/
|
||||||
|
#define STM32_BOOTLOADER_ADDRESS 0x1FFFD800
|
||||||
|
|
||||||
|
/* key matrix size */
|
||||||
|
#define MATRIX_ROWS 5
|
||||||
|
#define MATRIX_COLS 15
|
||||||
|
|
||||||
|
/* ROWS: Top to bottom, COLS: Left to right
|
||||||
|
*/
|
||||||
|
#define MATRIX_ROW_PINS { B0, B1, B2, A15, A10 }
|
||||||
|
#define MATRIX_COL_PINS { A2, A3, A6, B14, B15, A8, A9, A7, B3, B4, C14, C15, C13, B5, B6 }
|
||||||
|
|
||||||
|
/* COL2ROW, ROW2COL, or CUSTOM_MATRIX */
|
||||||
|
#define DIODE_DIRECTION COL2ROW
|
||||||
|
|
||||||
|
/* Debounce reduces chatter (unintended double-presses) - set 0 if debouncing is not needed */
|
||||||
|
#define DEBOUNCE 5
|
||||||
|
|
||||||
|
/* Mechanical locking support. Use KC_LCAP, KC_LNUM or KC_LSCR instead in keymap */
|
||||||
|
#define LOCKING_SUPPORT_ENABLE
|
||||||
|
/* Locking resynchronize hack */
|
||||||
|
#define LOCKING_RESYNC_ENABLE
|
||||||
|
|
||||||
|
/* Backlight configuration
|
||||||
|
* Backlight LEDs on B8
|
||||||
|
*/
|
||||||
|
#define BACKLIGHT_LEVELS 24
|
||||||
|
#define BACKLIGHT_BREATHING
|
||||||
|
#define BREATHING_PERIOD 6
|
||||||
@@ -0,0 +1,388 @@
|
|||||||
|
/*
|
||||||
|
ChibiOS - Copyright (C) 2006..2016 Giovanni Di Sirio
|
||||||
|
|
||||||
|
Licensed under the Apache License, Version 2.0 (the "License");
|
||||||
|
you may not use this file except in compliance with the License.
|
||||||
|
You may obtain a copy of the License at
|
||||||
|
|
||||||
|
http://www.apache.org/licenses/LICENSE-2.0
|
||||||
|
|
||||||
|
Unless required by applicable law or agreed to in writing, software
|
||||||
|
distributed under the License is distributed on an "AS IS" BASIS,
|
||||||
|
WITHOUT WARRANTIES OR CONDITIONS OF ANY KIND, either express or implied.
|
||||||
|
See the License for the specific language governing permissions and
|
||||||
|
limitations under the License.
|
||||||
|
*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @file templates/halconf.h
|
||||||
|
* @brief HAL configuration header.
|
||||||
|
* @details HAL configuration file, this file allows to enable or disable the
|
||||||
|
* various device drivers from your application. You may also use
|
||||||
|
* this file in order to override the device drivers default settings.
|
||||||
|
*
|
||||||
|
* @addtogroup HAL_CONF
|
||||||
|
* @{
|
||||||
|
*/
|
||||||
|
|
||||||
|
#ifndef HALCONF_H
|
||||||
|
#define HALCONF_H
|
||||||
|
|
||||||
|
#include "mcuconf.h"
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the PAL subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_PAL) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_PAL TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the ADC subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_ADC) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_ADC FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the CAN subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_CAN) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_CAN FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the DAC subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_DAC) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_DAC TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the EXT subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_EXT) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_EXT FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the GPT subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_GPT) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_GPT TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the I2C subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_I2C) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_I2C FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the I2S subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_I2S) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_I2S FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the ICU subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_ICU) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_ICU FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the MAC subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_MAC) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_MAC FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the MMC_SPI subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_MMC_SPI) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_MMC_SPI FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the PWM subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_PWM) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_PWM TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the QSPI subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_QSPI) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_QSPI FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the RTC subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_RTC) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_RTC FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the SDC subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_SDC) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_SDC FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the SERIAL subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_SERIAL) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_SERIAL FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the SERIAL over USB subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_SERIAL_USB) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_SERIAL_USB TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the SPI subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_SPI) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_SPI FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the UART subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_UART) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_UART FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the USB subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_USB) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_USB TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the WDG subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_WDG) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_WDG FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* ADC driver related settings. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables synchronous APIs.
|
||||||
|
* @note Disabling this option saves both code and data space.
|
||||||
|
*/
|
||||||
|
#if !defined(ADC_USE_WAIT) || defined(__DOXYGEN__)
|
||||||
|
#define ADC_USE_WAIT TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the @p adcAcquireBus() and @p adcReleaseBus() APIs.
|
||||||
|
* @note Disabling this option saves both code and data space.
|
||||||
|
*/
|
||||||
|
#if !defined(ADC_USE_MUTUAL_EXCLUSION) || defined(__DOXYGEN__)
|
||||||
|
#define ADC_USE_MUTUAL_EXCLUSION TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* CAN driver related settings. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Sleep mode related APIs inclusion switch.
|
||||||
|
*/
|
||||||
|
#if !defined(CAN_USE_SLEEP_MODE) || defined(__DOXYGEN__)
|
||||||
|
#define CAN_USE_SLEEP_MODE TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* I2C driver related settings. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the mutual exclusion APIs on the I2C bus.
|
||||||
|
*/
|
||||||
|
#if !defined(I2C_USE_MUTUAL_EXCLUSION) || defined(__DOXYGEN__)
|
||||||
|
#define I2C_USE_MUTUAL_EXCLUSION TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* MAC driver related settings. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables an event sources for incoming packets.
|
||||||
|
*/
|
||||||
|
#if !defined(MAC_USE_ZERO_COPY) || defined(__DOXYGEN__)
|
||||||
|
#define MAC_USE_ZERO_COPY FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables an event sources for incoming packets.
|
||||||
|
*/
|
||||||
|
#if !defined(MAC_USE_EVENTS) || defined(__DOXYGEN__)
|
||||||
|
#define MAC_USE_EVENTS TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* MMC_SPI driver related settings. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Delays insertions.
|
||||||
|
* @details If enabled this options inserts delays into the MMC waiting
|
||||||
|
* routines releasing some extra CPU time for the threads with
|
||||||
|
* lower priority, this may slow down the driver a bit however.
|
||||||
|
* This option is recommended also if the SPI driver does not
|
||||||
|
* use a DMA channel and heavily loads the CPU.
|
||||||
|
*/
|
||||||
|
#if !defined(MMC_NICE_WAITING) || defined(__DOXYGEN__)
|
||||||
|
#define MMC_NICE_WAITING TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* SDC driver related settings. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Number of initialization attempts before rejecting the card.
|
||||||
|
* @note Attempts are performed at 10mS intervals.
|
||||||
|
*/
|
||||||
|
#if !defined(SDC_INIT_RETRY) || defined(__DOXYGEN__)
|
||||||
|
#define SDC_INIT_RETRY 100
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Include support for MMC cards.
|
||||||
|
* @note MMC support is not yet implemented so this option must be kept
|
||||||
|
* at @p FALSE.
|
||||||
|
*/
|
||||||
|
#if !defined(SDC_MMC_SUPPORT) || defined(__DOXYGEN__)
|
||||||
|
#define SDC_MMC_SUPPORT FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Delays insertions.
|
||||||
|
* @details If enabled this options inserts delays into the MMC waiting
|
||||||
|
* routines releasing some extra CPU time for the threads with
|
||||||
|
* lower priority, this may slow down the driver a bit however.
|
||||||
|
*/
|
||||||
|
#if !defined(SDC_NICE_WAITING) || defined(__DOXYGEN__)
|
||||||
|
#define SDC_NICE_WAITING TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* SERIAL driver related settings. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Default bit rate.
|
||||||
|
* @details Configuration parameter, this is the baud rate selected for the
|
||||||
|
* default configuration.
|
||||||
|
*/
|
||||||
|
#if !defined(SERIAL_DEFAULT_BITRATE) || defined(__DOXYGEN__)
|
||||||
|
#define SERIAL_DEFAULT_BITRATE 38400
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Serial buffers size.
|
||||||
|
* @details Configuration parameter, you can change the depth of the queue
|
||||||
|
* buffers depending on the requirements of your application.
|
||||||
|
* @note The default is 16 bytes for both the transmission and receive
|
||||||
|
* buffers.
|
||||||
|
*/
|
||||||
|
#if !defined(SERIAL_BUFFERS_SIZE) || defined(__DOXYGEN__)
|
||||||
|
#define SERIAL_BUFFERS_SIZE 16
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* SERIAL_USB driver related setting. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Serial over USB buffers size.
|
||||||
|
* @details Configuration parameter, the buffer size must be a multiple of
|
||||||
|
* the USB data endpoint maximum packet size.
|
||||||
|
* @note The default is 256 bytes for both the transmission and receive
|
||||||
|
* buffers.
|
||||||
|
*/
|
||||||
|
#if !defined(SERIAL_USB_BUFFERS_SIZE) || defined(__DOXYGEN__)
|
||||||
|
#define SERIAL_USB_BUFFERS_SIZE 1
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Serial over USB number of buffers.
|
||||||
|
* @note The default is 2 buffers.
|
||||||
|
*/
|
||||||
|
#if !defined(SERIAL_USB_BUFFERS_NUMBER) || defined(__DOXYGEN__)
|
||||||
|
#define SERIAL_USB_BUFFERS_NUMBER 2
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* SPI driver related settings. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables synchronous APIs.
|
||||||
|
* @note Disabling this option saves both code and data space.
|
||||||
|
*/
|
||||||
|
#if !defined(SPI_USE_WAIT) || defined(__DOXYGEN__)
|
||||||
|
#define SPI_USE_WAIT TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the @p spiAcquireBus() and @p spiReleaseBus() APIs.
|
||||||
|
* @note Disabling this option saves both code and data space.
|
||||||
|
*/
|
||||||
|
#if !defined(SPI_USE_MUTUAL_EXCLUSION) || defined(__DOXYGEN__)
|
||||||
|
#define SPI_USE_MUTUAL_EXCLUSION TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* UART driver related settings. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables synchronous APIs.
|
||||||
|
* @note Disabling this option saves both code and data space.
|
||||||
|
*/
|
||||||
|
#if !defined(UART_USE_WAIT) || defined(__DOXYGEN__)
|
||||||
|
#define UART_USE_WAIT FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the @p uartAcquireBus() and @p uartReleaseBus() APIs.
|
||||||
|
* @note Disabling this option saves both code and data space.
|
||||||
|
*/
|
||||||
|
#if !defined(UART_USE_MUTUAL_EXCLUSION) || defined(__DOXYGEN__)
|
||||||
|
#define UART_USE_MUTUAL_EXCLUSION FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* USB driver related settings. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables synchronous APIs.
|
||||||
|
* @note Disabling this option saves both code and data space.
|
||||||
|
*/
|
||||||
|
#if !defined(USB_USE_WAIT) || defined(__DOXYGEN__)
|
||||||
|
#define USB_USE_WAIT TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
#endif /* HALCONF_H */
|
||||||
|
|
||||||
|
/** @} */
|
||||||
@@ -0,0 +1,240 @@
|
|||||||
|
/*
|
||||||
|
Copyright 2012 Jun Wako <[email protected]>
|
||||||
|
|
||||||
|
This program is free software: you can redistribute it and/or modify
|
||||||
|
it under the terms of the GNU General Public License as published by
|
||||||
|
the Free Software Foundation, either version 2 of the License, or
|
||||||
|
(at your option) any later version.
|
||||||
|
|
||||||
|
This program is distributed in the hope that it will be useful,
|
||||||
|
but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
GNU General Public License for more details.
|
||||||
|
|
||||||
|
You should have received a copy of the GNU General Public License
|
||||||
|
along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
|
||||||
|
#include "hal.h"
|
||||||
|
#include "led_custom.h"
|
||||||
|
#include "rev6.h"
|
||||||
|
#include "printf.h"
|
||||||
|
|
||||||
|
static void breathing_callback(PWMDriver *pwmp);
|
||||||
|
|
||||||
|
static PWMConfig pwmCFG = {
|
||||||
|
0xFFFF, /* PWM clock frequency */
|
||||||
|
256, /* PWM period (in ticks) 1S (1/10kHz=0.1mS 0.1ms*10000 ticks=1S) */
|
||||||
|
NULL, /* No Callback */
|
||||||
|
{
|
||||||
|
{PWM_OUTPUT_DISABLED, NULL},
|
||||||
|
{PWM_OUTPUT_DISABLED, NULL},
|
||||||
|
{PWM_OUTPUT_ACTIVE_HIGH, NULL}, /* Enable Channel 3 */
|
||||||
|
{PWM_OUTPUT_DISABLED, NULL}
|
||||||
|
},
|
||||||
|
0, /* HW dependent part.*/
|
||||||
|
0
|
||||||
|
};
|
||||||
|
|
||||||
|
static PWMConfig pwmCFG_breathing = {
|
||||||
|
0xFFFF, /* 10kHz PWM clock frequency */
|
||||||
|
256, /* PWM period (in ticks) 1S (1/10kHz=0.1mS 0.1ms*10000 ticks=1S) */
|
||||||
|
breathing_callback, /* Breathing Callback */
|
||||||
|
{
|
||||||
|
{PWM_OUTPUT_DISABLED, NULL},
|
||||||
|
{PWM_OUTPUT_DISABLED, NULL},
|
||||||
|
{PWM_OUTPUT_ACTIVE_HIGH, NULL}, /* Enable Channel 3 */
|
||||||
|
{PWM_OUTPUT_DISABLED, NULL}
|
||||||
|
},
|
||||||
|
0, /* HW dependent part.*/
|
||||||
|
0
|
||||||
|
};
|
||||||
|
|
||||||
|
// See http://jared.geek.nz/2013/feb/linear-led-pwm
|
||||||
|
static uint16_t cie_lightness(uint16_t v) {
|
||||||
|
if (v <= 5243) // if below 8% of max
|
||||||
|
return v / 9; // same as dividing by 900%
|
||||||
|
else {
|
||||||
|
uint32_t y = (((uint32_t)v + 10486) << 8) / (10486 + 0xFFFFUL); // add 16% of max and compare
|
||||||
|
// to get a useful result with integer division, we shift left in the expression above
|
||||||
|
// and revert what we've done again after squaring.
|
||||||
|
y = y * y * y >> 8;
|
||||||
|
if (y > 0xFFFFUL) // prevent overflow
|
||||||
|
return 0xFFFFU;
|
||||||
|
else
|
||||||
|
return (uint16_t)y;
|
||||||
|
}
|
||||||
|
}
|
||||||
|
|
||||||
|
void backlight_init_ports(void) {
|
||||||
|
palSetPadMode(GPIOB, 8, PAL_MODE_ALTERNATE(2));
|
||||||
|
pwmStart(&PWMD4, &pwmCFG);
|
||||||
|
if (kb_backlight_config.enable) {
|
||||||
|
if (kb_backlight_config.breathing) {
|
||||||
|
breathing_enable();
|
||||||
|
} else {
|
||||||
|
backlight_set(kb_backlight_config.level);
|
||||||
|
}
|
||||||
|
} else {
|
||||||
|
backlight_set(0);
|
||||||
|
}
|
||||||
|
}
|
||||||
|
|
||||||
|
void backlight_set(uint8_t level) {
|
||||||
|
uint32_t duty = (uint32_t)(cie_lightness(0xFFFF * (uint32_t)level / BACKLIGHT_LEVELS));
|
||||||
|
if (level == 0) {
|
||||||
|
// Turn backlight off
|
||||||
|
// Disable channel 3 on PWM4
|
||||||
|
pwmDisableChannel(&PWMD4, 2);
|
||||||
|
} else {
|
||||||
|
// Turn backlight on
|
||||||
|
if (!is_breathing()) {
|
||||||
|
// Enable channel 3 on PWM4
|
||||||
|
pwmEnableChannel(&PWMD4, 2, PWM_FRACTION_TO_WIDTH(&PWMD4, 0xFFFF, duty));
|
||||||
|
}
|
||||||
|
}
|
||||||
|
}
|
||||||
|
|
||||||
|
uint8_t backlight_tick = 0;
|
||||||
|
|
||||||
|
void backlight_task(void) {
|
||||||
|
}
|
||||||
|
|
||||||
|
#define BREATHING_NO_HALT 0
|
||||||
|
#define BREATHING_HALT_OFF 1
|
||||||
|
#define BREATHING_HALT_ON 2
|
||||||
|
#define BREATHING_STEPS 128
|
||||||
|
|
||||||
|
static uint8_t breathing_period = BREATHING_PERIOD;
|
||||||
|
static uint8_t breathing_halt = BREATHING_NO_HALT;
|
||||||
|
static uint16_t breathing_counter = 0;
|
||||||
|
|
||||||
|
bool is_breathing(void) {
|
||||||
|
return PWMD4.config == &pwmCFG_breathing;
|
||||||
|
}
|
||||||
|
|
||||||
|
#define breathing_min() do {breathing_counter = 0;} while (0)
|
||||||
|
#define breathing_max() do {breathing_counter = breathing_period * 256 / 2;} while (0)
|
||||||
|
|
||||||
|
|
||||||
|
void breathing_interrupt_enable(void){
|
||||||
|
pwmStop(&PWMD4);
|
||||||
|
pwmStart(&PWMD4, &pwmCFG_breathing);
|
||||||
|
chSysLockFromISR();
|
||||||
|
pwmEnablePeriodicNotification(&PWMD4);
|
||||||
|
pwmEnableChannelI(
|
||||||
|
&PWMD4,
|
||||||
|
2,
|
||||||
|
PWM_FRACTION_TO_WIDTH(
|
||||||
|
&PWMD4,
|
||||||
|
0xFFFF,
|
||||||
|
0xFFFF
|
||||||
|
)
|
||||||
|
);
|
||||||
|
chSysUnlockFromISR();
|
||||||
|
}
|
||||||
|
|
||||||
|
void breathing_interrupt_disable(void){
|
||||||
|
pwmStop(&PWMD4);
|
||||||
|
pwmStart(&PWMD4, &pwmCFG);
|
||||||
|
}
|
||||||
|
|
||||||
|
void breathing_enable(void)
|
||||||
|
{
|
||||||
|
breathing_counter = 0;
|
||||||
|
breathing_halt = BREATHING_NO_HALT;
|
||||||
|
breathing_interrupt_enable();
|
||||||
|
}
|
||||||
|
|
||||||
|
void breathing_pulse(void)
|
||||||
|
{
|
||||||
|
if (kb_backlight_config.level == 0)
|
||||||
|
breathing_min();
|
||||||
|
else
|
||||||
|
breathing_max();
|
||||||
|
breathing_halt = BREATHING_HALT_ON;
|
||||||
|
breathing_interrupt_enable();
|
||||||
|
}
|
||||||
|
|
||||||
|
void breathing_disable(void)
|
||||||
|
{
|
||||||
|
breathing_interrupt_disable();
|
||||||
|
// Restore backlight level
|
||||||
|
backlight_set(kb_backlight_config.level);
|
||||||
|
}
|
||||||
|
|
||||||
|
void breathing_self_disable(void)
|
||||||
|
{
|
||||||
|
if (kb_backlight_config.level == 0)
|
||||||
|
breathing_halt = BREATHING_HALT_OFF;
|
||||||
|
else
|
||||||
|
breathing_halt = BREATHING_HALT_ON;
|
||||||
|
}
|
||||||
|
|
||||||
|
void breathing_toggle(void) {
|
||||||
|
if (is_breathing()){
|
||||||
|
breathing_disable();
|
||||||
|
} else {
|
||||||
|
breathing_enable();
|
||||||
|
}
|
||||||
|
}
|
||||||
|
|
||||||
|
void breathing_period_set(uint8_t value)
|
||||||
|
{
|
||||||
|
if (!value)
|
||||||
|
value = 1;
|
||||||
|
breathing_period = value;
|
||||||
|
}
|
||||||
|
|
||||||
|
void breathing_period_default(void) {
|
||||||
|
breathing_period_set(BREATHING_PERIOD);
|
||||||
|
}
|
||||||
|
|
||||||
|
void breathing_period_inc(void)
|
||||||
|
{
|
||||||
|
breathing_period_set(breathing_period+1);
|
||||||
|
}
|
||||||
|
|
||||||
|
void breathing_period_dec(void)
|
||||||
|
{
|
||||||
|
breathing_period_set(breathing_period-1);
|
||||||
|
}
|
||||||
|
|
||||||
|
/* To generate breathing curve in python:
|
||||||
|
* from math import sin, pi; [int(sin(x/128.0*pi)**4*255) for x in range(128)]
|
||||||
|
*/
|
||||||
|
static const uint8_t breathing_table[BREATHING_STEPS] = {0, 0, 0, 0, 0, 0, 0, 0, 0, 0, 0, 1, 1, 2, 3, 4, 5, 6, 8, 10, 12, 15, 17, 20, 24, 28, 32, 36, 41, 46, 51, 57, 63, 70, 76, 83, 91, 98, 106, 113, 121, 129, 138, 146, 154, 162, 170, 178, 185, 193, 200, 207, 213, 220, 225, 231, 235, 240, 244, 247, 250, 252, 253, 254, 255, 254, 253, 252, 250, 247, 244, 240, 235, 231, 225, 220, 213, 207, 200, 193, 185, 178, 170, 162, 154, 146, 138, 129, 121, 113, 106, 98, 91, 83, 76, 70, 63, 57, 51, 46, 41, 36, 32, 28, 24, 20, 17, 15, 12, 10, 8, 6, 5, 4, 3, 2, 1, 1, 0, 0, 0, 0, 0, 0, 0, 0, 0, 0};
|
||||||
|
|
||||||
|
// Use this before the cie_lightness function.
|
||||||
|
static inline uint16_t scale_backlight(uint16_t v) {
|
||||||
|
return v / BACKLIGHT_LEVELS * kb_backlight_config.level;
|
||||||
|
}
|
||||||
|
|
||||||
|
static void breathing_callback(PWMDriver *pwmp)
|
||||||
|
{
|
||||||
|
(void)pwmp;
|
||||||
|
uint16_t interval = (uint16_t) breathing_period * 256 / BREATHING_STEPS;
|
||||||
|
// resetting after one period to prevent ugly reset at overflow.
|
||||||
|
breathing_counter = (breathing_counter + 1) % (breathing_period * 256);
|
||||||
|
uint8_t index = breathing_counter / interval % BREATHING_STEPS;
|
||||||
|
|
||||||
|
if (((breathing_halt == BREATHING_HALT_ON) && (index == BREATHING_STEPS / 2)) ||
|
||||||
|
((breathing_halt == BREATHING_HALT_OFF) && (index == BREATHING_STEPS - 1)))
|
||||||
|
{
|
||||||
|
breathing_interrupt_disable();
|
||||||
|
}
|
||||||
|
|
||||||
|
uint32_t duty = cie_lightness(scale_backlight(breathing_table[index] * 256));
|
||||||
|
|
||||||
|
chSysLockFromISR();
|
||||||
|
pwmEnableChannelI(
|
||||||
|
&PWMD4,
|
||||||
|
2,
|
||||||
|
PWM_FRACTION_TO_WIDTH(
|
||||||
|
&PWMD4,
|
||||||
|
0xFFFF,
|
||||||
|
duty
|
||||||
|
)
|
||||||
|
);
|
||||||
|
chSysUnlockFromISR();
|
||||||
|
}
|
||||||
@@ -0,0 +1,22 @@
|
|||||||
|
/*
|
||||||
|
* Copyright 2019 John M Daly <[email protected]>
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
|
||||||
|
#pragma once
|
||||||
|
|
||||||
|
void backlight_task(void);
|
||||||
|
void breathing_interrupt_disable(void);
|
||||||
|
void breathing_interrupt_enable(void);
|
||||||
@@ -0,0 +1,257 @@
|
|||||||
|
/*
|
||||||
|
ChibiOS - Copyright (C) 2006..2016 Giovanni Di Sirio
|
||||||
|
|
||||||
|
Licensed under the Apache License, Version 2.0 (the "License");
|
||||||
|
you may not use this file except in compliance with the License.
|
||||||
|
You may obtain a copy of the License at
|
||||||
|
|
||||||
|
http://www.apache.org/licenses/LICENSE-2.0
|
||||||
|
|
||||||
|
Unless required by applicable law or agreed to in writing, software
|
||||||
|
distributed under the License is distributed on an "AS IS" BASIS,
|
||||||
|
WITHOUT WARRANTIES OR CONDITIONS OF ANY KIND, either express or implied.
|
||||||
|
See the License for the specific language governing permissions and
|
||||||
|
limitations under the License.
|
||||||
|
*/
|
||||||
|
|
||||||
|
#ifndef MCUCONF_H
|
||||||
|
#define MCUCONF_H
|
||||||
|
|
||||||
|
/*
|
||||||
|
* STM32F3xx drivers configuration.
|
||||||
|
* The following settings override the default settings present in
|
||||||
|
* the various device driver implementation headers.
|
||||||
|
* Note that the settings for each driver only have effect if the whole
|
||||||
|
* driver is enabled in halconf.h.
|
||||||
|
*
|
||||||
|
* IRQ priorities:
|
||||||
|
* 15...0 Lowest...Highest.
|
||||||
|
*
|
||||||
|
* DMA priorities:
|
||||||
|
* 0...3 Lowest...Highest.
|
||||||
|
*/
|
||||||
|
|
||||||
|
#define STM32F3xx_MCUCONF
|
||||||
|
|
||||||
|
/*
|
||||||
|
* HAL driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_NO_INIT FALSE
|
||||||
|
#define STM32_PVD_ENABLE FALSE
|
||||||
|
#define STM32_PLS STM32_PLS_LEV0
|
||||||
|
#define STM32_HSI_ENABLED TRUE
|
||||||
|
#define STM32_LSI_ENABLED TRUE
|
||||||
|
#define STM32_HSE_ENABLED TRUE
|
||||||
|
#define STM32_LSE_ENABLED FALSE
|
||||||
|
#define STM32_SW STM32_SW_PLL
|
||||||
|
#define STM32_PLLSRC STM32_PLLSRC_HSE
|
||||||
|
#define STM32_PREDIV_VALUE 1
|
||||||
|
#define STM32_PLLMUL_VALUE 9
|
||||||
|
#define STM32_HPRE STM32_HPRE_DIV1
|
||||||
|
#define STM32_PPRE1 STM32_PPRE1_DIV2
|
||||||
|
#define STM32_PPRE2 STM32_PPRE2_DIV2
|
||||||
|
#define STM32_MCOSEL STM32_MCOSEL_NOCLOCK
|
||||||
|
#define STM32_ADC12PRES STM32_ADC12PRES_DIV1
|
||||||
|
#define STM32_ADC34PRES STM32_ADC34PRES_DIV1
|
||||||
|
#define STM32_USART1SW STM32_USART1SW_PCLK
|
||||||
|
#define STM32_USART2SW STM32_USART2SW_PCLK
|
||||||
|
#define STM32_USART3SW STM32_USART3SW_PCLK
|
||||||
|
#define STM32_UART4SW STM32_UART4SW_PCLK
|
||||||
|
#define STM32_UART5SW STM32_UART5SW_PCLK
|
||||||
|
#define STM32_I2C1SW STM32_I2C1SW_SYSCLK
|
||||||
|
#define STM32_I2C2SW STM32_I2C2SW_SYSCLK
|
||||||
|
#define STM32_TIM1SW STM32_TIM1SW_PCLK2
|
||||||
|
#define STM32_TIM8SW STM32_TIM8SW_PCLK2
|
||||||
|
#define STM32_RTCSEL STM32_RTCSEL_LSI
|
||||||
|
#define STM32_USB_CLOCK_REQUIRED TRUE
|
||||||
|
#define STM32_USBPRE STM32_USBPRE_DIV1P5
|
||||||
|
|
||||||
|
#undef STM32_HSE_BYPASS
|
||||||
|
// #error "oh no"
|
||||||
|
// #endif
|
||||||
|
|
||||||
|
/*
|
||||||
|
* ADC driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_ADC_DUAL_MODE FALSE
|
||||||
|
#define STM32_ADC_COMPACT_SAMPLES FALSE
|
||||||
|
#define STM32_ADC_USE_ADC1 FALSE
|
||||||
|
#define STM32_ADC_USE_ADC2 FALSE
|
||||||
|
#define STM32_ADC_USE_ADC3 FALSE
|
||||||
|
#define STM32_ADC_USE_ADC4 FALSE
|
||||||
|
#define STM32_ADC_ADC1_DMA_STREAM STM32_DMA_STREAM_ID(1, 1)
|
||||||
|
#define STM32_ADC_ADC2_DMA_STREAM STM32_DMA_STREAM_ID(2, 1)
|
||||||
|
#define STM32_ADC_ADC3_DMA_STREAM STM32_DMA_STREAM_ID(2, 5)
|
||||||
|
#define STM32_ADC_ADC4_DMA_STREAM STM32_DMA_STREAM_ID(2, 2)
|
||||||
|
#define STM32_ADC_ADC1_DMA_PRIORITY 2
|
||||||
|
#define STM32_ADC_ADC2_DMA_PRIORITY 2
|
||||||
|
#define STM32_ADC_ADC3_DMA_PRIORITY 2
|
||||||
|
#define STM32_ADC_ADC4_DMA_PRIORITY 2
|
||||||
|
#define STM32_ADC_ADC12_IRQ_PRIORITY 5
|
||||||
|
#define STM32_ADC_ADC3_IRQ_PRIORITY 5
|
||||||
|
#define STM32_ADC_ADC4_IRQ_PRIORITY 5
|
||||||
|
#define STM32_ADC_ADC1_DMA_IRQ_PRIORITY 5
|
||||||
|
#define STM32_ADC_ADC2_DMA_IRQ_PRIORITY 5
|
||||||
|
#define STM32_ADC_ADC3_DMA_IRQ_PRIORITY 5
|
||||||
|
#define STM32_ADC_ADC4_DMA_IRQ_PRIORITY 5
|
||||||
|
#define STM32_ADC_ADC12_CLOCK_MODE ADC_CCR_CKMODE_AHB_DIV1
|
||||||
|
#define STM32_ADC_ADC34_CLOCK_MODE ADC_CCR_CKMODE_AHB_DIV1
|
||||||
|
|
||||||
|
/*
|
||||||
|
* CAN driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_CAN_USE_CAN1 FALSE
|
||||||
|
#define STM32_CAN_CAN1_IRQ_PRIORITY 11
|
||||||
|
|
||||||
|
/*
|
||||||
|
* DAC driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_DAC_DUAL_MODE FALSE
|
||||||
|
#define STM32_DAC_USE_DAC1_CH1 TRUE
|
||||||
|
#define STM32_DAC_USE_DAC1_CH2 TRUE
|
||||||
|
#define STM32_DAC_DAC1_CH1_IRQ_PRIORITY 10
|
||||||
|
#define STM32_DAC_DAC1_CH2_IRQ_PRIORITY 10
|
||||||
|
#define STM32_DAC_DAC1_CH1_DMA_PRIORITY 2
|
||||||
|
#define STM32_DAC_DAC1_CH2_DMA_PRIORITY 2
|
||||||
|
|
||||||
|
/*
|
||||||
|
* EXT driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_EXT_EXTI0_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI1_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI2_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI3_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI4_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI5_9_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI10_15_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI16_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI17_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI18_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI19_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI20_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI21_22_29_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI30_32_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI33_IRQ_PRIORITY 6
|
||||||
|
|
||||||
|
/*
|
||||||
|
* GPT driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_GPT_USE_TIM1 FALSE
|
||||||
|
#define STM32_GPT_USE_TIM2 FALSE
|
||||||
|
#define STM32_GPT_USE_TIM3 FALSE
|
||||||
|
#define STM32_GPT_USE_TIM4 FALSE
|
||||||
|
#define STM32_GPT_USE_TIM6 TRUE
|
||||||
|
#define STM32_GPT_USE_TIM7 TRUE
|
||||||
|
#define STM32_GPT_USE_TIM8 TRUE
|
||||||
|
#define STM32_GPT_TIM1_IRQ_PRIORITY 7
|
||||||
|
#define STM32_GPT_TIM2_IRQ_PRIORITY 7
|
||||||
|
#define STM32_GPT_TIM3_IRQ_PRIORITY 7
|
||||||
|
#define STM32_GPT_TIM4_IRQ_PRIORITY 7
|
||||||
|
#define STM32_GPT_TIM6_IRQ_PRIORITY 7
|
||||||
|
#define STM32_GPT_TIM7_IRQ_PRIORITY 7
|
||||||
|
#define STM32_GPT_TIM8_IRQ_PRIORITY 7
|
||||||
|
|
||||||
|
/*
|
||||||
|
* I2C driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_I2C_USE_I2C1 FALSE
|
||||||
|
#define STM32_I2C_USE_I2C2 FALSE
|
||||||
|
#define STM32_I2C_BUSY_TIMEOUT 50
|
||||||
|
#define STM32_I2C_I2C1_IRQ_PRIORITY 10
|
||||||
|
#define STM32_I2C_I2C2_IRQ_PRIORITY 10
|
||||||
|
#define STM32_I2C_USE_DMA TRUE
|
||||||
|
#define STM32_I2C_I2C1_DMA_PRIORITY 1
|
||||||
|
#define STM32_I2C_I2C2_DMA_PRIORITY 1
|
||||||
|
#define STM32_I2C_DMA_ERROR_HOOK(i2cp) osalSysHalt("DMA failure")
|
||||||
|
|
||||||
|
/*
|
||||||
|
* ICU driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_ICU_USE_TIM1 FALSE
|
||||||
|
#define STM32_ICU_USE_TIM2 FALSE
|
||||||
|
#define STM32_ICU_USE_TIM3 FALSE
|
||||||
|
#define STM32_ICU_USE_TIM4 FALSE
|
||||||
|
#define STM32_ICU_USE_TIM8 FALSE
|
||||||
|
#define STM32_ICU_TIM1_IRQ_PRIORITY 7
|
||||||
|
#define STM32_ICU_TIM2_IRQ_PRIORITY 7
|
||||||
|
#define STM32_ICU_TIM3_IRQ_PRIORITY 7
|
||||||
|
#define STM32_ICU_TIM4_IRQ_PRIORITY 7
|
||||||
|
#define STM32_ICU_TIM8_IRQ_PRIORITY 7
|
||||||
|
|
||||||
|
/*
|
||||||
|
* PWM driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_PWM_USE_ADVANCED FALSE
|
||||||
|
#define STM32_PWM_USE_TIM1 FALSE
|
||||||
|
#define STM32_PWM_USE_TIM2 FALSE
|
||||||
|
#define STM32_PWM_USE_TIM3 FALSE
|
||||||
|
#define STM32_PWM_USE_TIM4 TRUE
|
||||||
|
#define STM32_PWM_USE_TIM8 FALSE
|
||||||
|
#define STM32_PWM_TIM1_IRQ_PRIORITY 7
|
||||||
|
#define STM32_PWM_TIM2_IRQ_PRIORITY 7
|
||||||
|
#define STM32_PWM_TIM3_IRQ_PRIORITY 7
|
||||||
|
#define STM32_PWM_TIM4_IRQ_PRIORITY 7
|
||||||
|
#define STM32_PWM_TIM8_IRQ_PRIORITY 7
|
||||||
|
|
||||||
|
/*
|
||||||
|
* SERIAL driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_SERIAL_USE_USART1 FALSE
|
||||||
|
#define STM32_SERIAL_USE_USART2 TRUE
|
||||||
|
#define STM32_SERIAL_USE_USART3 FALSE
|
||||||
|
#define STM32_SERIAL_USE_UART4 FALSE
|
||||||
|
#define STM32_SERIAL_USE_UART5 FALSE
|
||||||
|
#define STM32_SERIAL_USART1_PRIORITY 12
|
||||||
|
#define STM32_SERIAL_USART2_PRIORITY 12
|
||||||
|
#define STM32_SERIAL_USART3_PRIORITY 12
|
||||||
|
#define STM32_SERIAL_UART4_PRIORITY 12
|
||||||
|
#define STM32_SERIAL_UART5_PRIORITY 12
|
||||||
|
|
||||||
|
/*
|
||||||
|
* SPI driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_SPI_USE_SPI1 FALSE
|
||||||
|
#define STM32_SPI_USE_SPI2 FALSE
|
||||||
|
#define STM32_SPI_USE_SPI3 FALSE
|
||||||
|
#define STM32_SPI_SPI1_DMA_PRIORITY 1
|
||||||
|
#define STM32_SPI_SPI2_DMA_PRIORITY 1
|
||||||
|
#define STM32_SPI_SPI3_DMA_PRIORITY 1
|
||||||
|
#define STM32_SPI_SPI1_IRQ_PRIORITY 10
|
||||||
|
#define STM32_SPI_SPI2_IRQ_PRIORITY 10
|
||||||
|
#define STM32_SPI_SPI3_IRQ_PRIORITY 10
|
||||||
|
#define STM32_SPI_DMA_ERROR_HOOK(spip) osalSysHalt("DMA failure")
|
||||||
|
|
||||||
|
/*
|
||||||
|
* ST driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_ST_IRQ_PRIORITY 8
|
||||||
|
#define STM32_ST_USE_TIMER 2
|
||||||
|
|
||||||
|
/*
|
||||||
|
* UART driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_UART_USE_USART1 FALSE
|
||||||
|
#define STM32_UART_USE_USART2 FALSE
|
||||||
|
#define STM32_UART_USE_USART3 FALSE
|
||||||
|
#define STM32_UART_USART1_IRQ_PRIORITY 12
|
||||||
|
#define STM32_UART_USART2_IRQ_PRIORITY 12
|
||||||
|
#define STM32_UART_USART3_IRQ_PRIORITY 12
|
||||||
|
#define STM32_UART_USART1_DMA_PRIORITY 0
|
||||||
|
#define STM32_UART_USART2_DMA_PRIORITY 0
|
||||||
|
#define STM32_UART_USART3_DMA_PRIORITY 0
|
||||||
|
#define STM32_UART_DMA_ERROR_HOOK(uartp) osalSysHalt("DMA failure")
|
||||||
|
|
||||||
|
/*
|
||||||
|
* USB driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_USB_USE_USB1 TRUE
|
||||||
|
#define STM32_USB_LOW_POWER_ON_SUSPEND FALSE
|
||||||
|
#define STM32_USB_USB1_HP_IRQ_PRIORITY 13
|
||||||
|
#define STM32_USB_USB1_LP_IRQ_PRIORITY 14
|
||||||
|
|
||||||
|
/*
|
||||||
|
* WDG driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_WDG_USE_IWDG FALSE
|
||||||
|
|
||||||
|
#endif /* MCUCONF_H */
|
||||||
@@ -0,0 +1,39 @@
|
|||||||
|
/* Copyright 2019 John M Daly <[email protected]>
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#include "rev6.h"
|
||||||
|
|
||||||
|
#include "backlight.h"
|
||||||
|
#include "led.h"
|
||||||
|
#include "printf.h"
|
||||||
|
|
||||||
|
backlight_levels_config_t kb_backlight_config = {
|
||||||
|
.enable = true,
|
||||||
|
.breathing = true,
|
||||||
|
.level = BACKLIGHT_LEVELS
|
||||||
|
};
|
||||||
|
|
||||||
|
uint8_t *o_fb;
|
||||||
|
|
||||||
|
uint16_t counterst = 0;
|
||||||
|
|
||||||
|
void matrix_init_kb(void) {
|
||||||
|
matrix_init_user();
|
||||||
|
backlight_init_ports();
|
||||||
|
}
|
||||||
|
|
||||||
|
void matrix_scan_kb(void) {
|
||||||
|
matrix_scan_user();
|
||||||
|
}
|
||||||
@@ -0,0 +1,146 @@
|
|||||||
|
/* Copyright 2019 John M Daly <[email protected]>
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#pragma once
|
||||||
|
|
||||||
|
#include "quantum.h"
|
||||||
|
|
||||||
|
// This a shortcut to help you visually see your layout.
|
||||||
|
// The following is a layout that uses all available switch positions.
|
||||||
|
// The first section contains all of the arguments
|
||||||
|
// The second converts the arguments into a two-dimensional array
|
||||||
|
#define LAYOUT_all( \
|
||||||
|
K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014, \
|
||||||
|
K100, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114, \
|
||||||
|
K200, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K213, K214, \
|
||||||
|
K300, K301, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, K313, K314, \
|
||||||
|
K400, K401, K402, K404, K406, K408, K410, K411, K412, K413, K414 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014 }, \
|
||||||
|
{ K100, KC_NO, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114 }, \
|
||||||
|
{ K200, KC_NO, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K213, K214 }, \
|
||||||
|
{ K300, K301, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, KC_NO, K313, K314 }, \
|
||||||
|
{ K400, K401, K402, KC_NO, K404, KC_NO, K406, KC_NO, K408, KC_NO, K410, K411, K412, K413, K414 }, \
|
||||||
|
}
|
||||||
|
|
||||||
|
#define LAYOUT_60_ansi( \
|
||||||
|
K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K014, \
|
||||||
|
K100, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114, \
|
||||||
|
K200, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K214, \
|
||||||
|
K300, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, K313, \
|
||||||
|
K400, K401, K402, K406, K410, K411, K413, K414 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, KC_NO, K014 }, \
|
||||||
|
{ K100, KC_NO, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114 }, \
|
||||||
|
{ K200, KC_NO, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, KC_NO, K214 }, \
|
||||||
|
{ K300, KC_NO, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, KC_NO, K313, KC_NO }, \
|
||||||
|
{ K400, K401, K402, KC_NO, KC_NO, KC_NO, K406, KC_NO, KC_NO, KC_NO, K410, K411, KC_NO, K413, K414 }, \
|
||||||
|
}
|
||||||
|
|
||||||
|
#define LAYOUT_60_ansi_split_bs_rshift( \
|
||||||
|
K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014, \
|
||||||
|
K100, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114, \
|
||||||
|
K200, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K214, \
|
||||||
|
K300, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, K313, K314, \
|
||||||
|
K400, K401, K402, K406, K410, K411, K413, K414 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014 }, \
|
||||||
|
{ K100, KC_NO, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114 }, \
|
||||||
|
{ K200, KC_NO, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, KC_NO, K214 }, \
|
||||||
|
{ K300, KC_NO, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, KC_NO, K313, K314 }, \
|
||||||
|
{ K400, K401, K402, KC_NO, KC_NO, KC_NO, K406, KC_NO, KC_NO, KC_NO, K410, K411, KC_NO, K413, K414 }, \
|
||||||
|
}
|
||||||
|
|
||||||
|
#define LAYOUT_60_iso( \
|
||||||
|
K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K014, \
|
||||||
|
K100, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, \
|
||||||
|
K200, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K213, K214, \
|
||||||
|
K300, K301, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, K313, \
|
||||||
|
K400, K401, K402, K406, K410, K411, K413, K414 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, KC_NO, K014 }, \
|
||||||
|
{ K100, KC_NO, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, KC_NO }, \
|
||||||
|
{ K200, KC_NO, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K213, K214 }, \
|
||||||
|
{ K300, K301, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, KC_NO, K313, KC_NO }, \
|
||||||
|
{ K400, K401, K402, KC_NO, KC_NO, KC_NO, K406, KC_NO, KC_NO, KC_NO, K410, K411, KC_NO, K413, K414 }, \
|
||||||
|
}
|
||||||
|
|
||||||
|
#define LAYOUT_60_hhkb( \
|
||||||
|
K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014, \
|
||||||
|
K100, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114, \
|
||||||
|
K200, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K214, \
|
||||||
|
K300, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, K313, K314, \
|
||||||
|
K401, K402, K406, K411, K413 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014 }, \
|
||||||
|
{ K100, KC_NO, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114 }, \
|
||||||
|
{ K200, KC_NO, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, KC_NO, K214 }, \
|
||||||
|
{ K300, KC_NO, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, KC_NO, K313, K314 }, \
|
||||||
|
{ KC_NO, K401, K402, KC_NO, KC_NO, KC_NO, K406, KC_NO, KC_NO, KC_NO, KC_NO, K411, KC_NO, K413, KC_NO }, \
|
||||||
|
}
|
||||||
|
|
||||||
|
#define LAYOUT_60_hhkb_split_space( \
|
||||||
|
K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014, \
|
||||||
|
K100, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114, \
|
||||||
|
K200, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K214, \
|
||||||
|
K300, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, K313, K314, \
|
||||||
|
K401, K402, K404, K406, K408, K411, K413 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014 }, \
|
||||||
|
{ K100, KC_NO, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114 }, \
|
||||||
|
{ K200, KC_NO, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, KC_NO, K214 }, \
|
||||||
|
{ K300, KC_NO, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, KC_NO, K313, K314 }, \
|
||||||
|
{ KC_NO, K401, K402, KC_NO, K404, KC_NO, K406, KC_NO, K408, KC_NO, KC_NO, K411, KC_NO, K413, KC_NO }, \
|
||||||
|
}
|
||||||
|
|
||||||
|
#define LAYOUT_60_hhkb_split_625u_space( \
|
||||||
|
K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014, \
|
||||||
|
K100, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114, \
|
||||||
|
K200, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K214, \
|
||||||
|
K300, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, K313, K314, \
|
||||||
|
K401, K402, K404, K406, K408, K410, K411, K413 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014 }, \
|
||||||
|
{ K100, KC_NO, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114 }, \
|
||||||
|
{ K200, KC_NO, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, KC_NO, K214 }, \
|
||||||
|
{ K300, KC_NO, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, KC_NO, K313, K314 }, \
|
||||||
|
{ KC_NO, K401, K402, KC_NO, K404, KC_NO, K406, KC_NO, K408, KC_NO, K410, K411, KC_NO, K413, KC_NO }, \
|
||||||
|
}
|
||||||
|
|
||||||
|
// Backlighting
|
||||||
|
typedef union {
|
||||||
|
uint8_t raw;
|
||||||
|
struct {
|
||||||
|
bool enable :1;
|
||||||
|
bool breathing : 1;
|
||||||
|
uint8_t level :6;
|
||||||
|
};
|
||||||
|
} backlight_levels_config_t;
|
||||||
|
|
||||||
|
extern backlight_levels_config_t kb_backlight_config;
|
||||||
|
extern bool kb_backlight_breathing;
|
||||||
|
|
||||||
|
void backlight_init_ports(void);
|
||||||
|
void backlight_set(uint8_t level);
|
||||||
|
bool is_breathing(void);
|
||||||
|
void breathing_enable(void);
|
||||||
|
void breathing_disable(void);
|
||||||
@@ -0,0 +1,59 @@
|
|||||||
|
# project specific files
|
||||||
|
|
||||||
|
## chip/board settings
|
||||||
|
# - the next two should match the directories in
|
||||||
|
# <chibios>/os/hal/ports/$(MCU_FAMILY)/$(MCU_SERIES)
|
||||||
|
MCU_FAMILY = STM32
|
||||||
|
MCU_SERIES = STM32F3xx
|
||||||
|
|
||||||
|
# Linker script to use
|
||||||
|
# - it should exist either in <chibios>/os/common/ports/ARMCMx/compilers/GCC/ld/
|
||||||
|
# or <this_dir>/ld/
|
||||||
|
MCU_LDSCRIPT = STM32F303xC
|
||||||
|
|
||||||
|
# Startup code to use
|
||||||
|
# - it should exist in <chibios>/os/common/startup/ARMCMx/compilers/GCC/mk/
|
||||||
|
MCU_STARTUP = stm32f3xx
|
||||||
|
|
||||||
|
# Board: it should exist either in <chibios>/os/hal/boards/
|
||||||
|
# or <this_dir>/boards
|
||||||
|
BOARD = GENERIC_STM32_F303XC
|
||||||
|
|
||||||
|
# Cortex version
|
||||||
|
MCU = cortex-m4
|
||||||
|
|
||||||
|
# ARM version, CORTEX-M0/M1 are 6, CORTEX-M3/M4/M7 are 7
|
||||||
|
ARMV = 7
|
||||||
|
|
||||||
|
USE_FPU = yes
|
||||||
|
|
||||||
|
# Vector table for application
|
||||||
|
# 0x00000000-0x00001000 area is occupied by bootlaoder.*/
|
||||||
|
# The CORTEX_VTOR... is needed only for MCHCK/Infinity KB
|
||||||
|
# OPT_DEFS = -DCORTEX_VTOR_INIT=0x08005000
|
||||||
|
|
||||||
|
# Options to pass to dfu-util when flashing
|
||||||
|
DFU_ARGS = -d 0483:df11 -a 0 -s 0x08000000:leave
|
||||||
|
DFU_SUFFIX_ARGS = -v 0483 -p df11
|
||||||
|
|
||||||
|
# Code for backlight breathing:
|
||||||
|
SRC += led.c
|
||||||
|
|
||||||
|
# Build Options
|
||||||
|
# comment out to disable the options.
|
||||||
|
#
|
||||||
|
BACKLIGHT_ENABLE = yes
|
||||||
|
BOOTMAGIC_ENABLE = no # Virtual DIP switch configuration(+1000)
|
||||||
|
MOUSEKEY_ENABLE = yes # Mouse keys(+4700)
|
||||||
|
EXTRAKEY_ENABLE = yes # Audio control and System control(+450)
|
||||||
|
CONSOLE_ENABLE = no # Console for debug(+400)
|
||||||
|
COMMAND_ENABLE = no # Commands for debug and configuration
|
||||||
|
NKRO_ENABLE = yes # USB Nkey Rollover - if this doesn't work, see here: https://github.com/tmk/tmk_keyboard/wiki/FAQ#nkro-doesnt-work
|
||||||
|
AUDIO_ENABLE = no
|
||||||
|
RGBLIGHT_ENABLE = no # Enable keyboard underlight functionality
|
||||||
|
MIDI_ENABLE = no # MIDI controls
|
||||||
|
UNICODE_ENABLE = no # Unicode
|
||||||
|
BLUETOOTH_ENABLE = no # Enable Bluetooth with the Adafruit EZ-Key HID
|
||||||
|
LEADER_ENABLE = yes
|
||||||
|
|
||||||
|
LAYOUTS += 60_ansi 60_ansi_split_bs_rshift 60_iso 60_hhkb
|
||||||
@@ -0,0 +1,520 @@
|
|||||||
|
/*
|
||||||
|
ChibiOS - Copyright (C) 2006..2016 Giovanni Di Sirio
|
||||||
|
|
||||||
|
Licensed under the Apache License, Version 2.0 (the "License");
|
||||||
|
you may not use this file except in compliance with the License.
|
||||||
|
You may obtain a copy of the License at
|
||||||
|
|
||||||
|
http://www.apache.org/licenses/LICENSE-2.0
|
||||||
|
|
||||||
|
Unless required by applicable law or agreed to in writing, software
|
||||||
|
distributed under the License is distributed on an "AS IS" BASIS,
|
||||||
|
WITHOUT WARRANTIES OR CONDITIONS OF ANY KIND, either express or implied.
|
||||||
|
See the License for the specific language governing permissions and
|
||||||
|
limitations under the License.
|
||||||
|
*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @file templates/chconf.h
|
||||||
|
* @brief Configuration file template.
|
||||||
|
* @details A copy of this file must be placed in each project directory, it
|
||||||
|
* contains the application specific kernel settings.
|
||||||
|
*
|
||||||
|
* @addtogroup config
|
||||||
|
* @details Kernel related settings and hooks.
|
||||||
|
* @{
|
||||||
|
*/
|
||||||
|
|
||||||
|
#ifndef CHCONF_H
|
||||||
|
#define CHCONF_H
|
||||||
|
|
||||||
|
#define _CHIBIOS_RT_CONF_
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/**
|
||||||
|
* @name System timers settings
|
||||||
|
* @{
|
||||||
|
*/
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief System time counter resolution.
|
||||||
|
* @note Allowed values are 16 or 32 bits.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_ST_RESOLUTION 32
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief System tick frequency.
|
||||||
|
* @details Frequency of the system timer that drives the system ticks. This
|
||||||
|
* setting also defines the system tick time unit.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_ST_FREQUENCY 100000
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Time delta constant for the tick-less mode.
|
||||||
|
* @note If this value is zero then the system uses the classic
|
||||||
|
* periodic tick. This value represents the minimum number
|
||||||
|
* of ticks that is safe to specify in a timeout directive.
|
||||||
|
* The value one is not valid, timeouts are rounded up to
|
||||||
|
* this value.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_ST_TIMEDELTA 2
|
||||||
|
|
||||||
|
/** @} */
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/**
|
||||||
|
* @name Kernel parameters and options
|
||||||
|
* @{
|
||||||
|
*/
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Round robin interval.
|
||||||
|
* @details This constant is the number of system ticks allowed for the
|
||||||
|
* threads before preemption occurs. Setting this value to zero
|
||||||
|
* disables the preemption for threads with equal priority and the
|
||||||
|
* round robin becomes cooperative. Note that higher priority
|
||||||
|
* threads can still preempt, the kernel is always preemptive.
|
||||||
|
* @note Disabling the round robin preemption makes the kernel more compact
|
||||||
|
* and generally faster.
|
||||||
|
* @note The round robin preemption is not supported in tickless mode and
|
||||||
|
* must be set to zero in that case.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_TIME_QUANTUM 0
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Managed RAM size.
|
||||||
|
* @details Size of the RAM area to be managed by the OS. If set to zero
|
||||||
|
* then the whole available RAM is used. The core memory is made
|
||||||
|
* available to the heap allocator and/or can be used directly through
|
||||||
|
* the simplified core memory allocator.
|
||||||
|
*
|
||||||
|
* @note In order to let the OS manage the whole RAM the linker script must
|
||||||
|
* provide the @p __heap_base__ and @p __heap_end__ symbols.
|
||||||
|
* @note Requires @p CH_CFG_USE_MEMCORE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_MEMCORE_SIZE 0
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Idle thread automatic spawn suppression.
|
||||||
|
* @details When this option is activated the function @p chSysInit()
|
||||||
|
* does not spawn the idle thread. The application @p main()
|
||||||
|
* function becomes the idle thread and must implement an
|
||||||
|
* infinite loop.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_NO_IDLE_THREAD FALSE
|
||||||
|
|
||||||
|
/** @} */
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/**
|
||||||
|
* @name Performance options
|
||||||
|
* @{
|
||||||
|
*/
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief OS optimization.
|
||||||
|
* @details If enabled then time efficient rather than space efficient code
|
||||||
|
* is used when two possible implementations exist.
|
||||||
|
*
|
||||||
|
* @note This is not related to the compiler optimization options.
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_OPTIMIZE_SPEED TRUE
|
||||||
|
|
||||||
|
/** @} */
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/**
|
||||||
|
* @name Subsystem options
|
||||||
|
* @{
|
||||||
|
*/
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Time Measurement APIs.
|
||||||
|
* @details If enabled then the time measurement APIs are included in
|
||||||
|
* the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_TM TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Threads registry APIs.
|
||||||
|
* @details If enabled then the registry APIs are included in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_REGISTRY TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Threads synchronization APIs.
|
||||||
|
* @details If enabled then the @p chThdWait() function is included in
|
||||||
|
* the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_WAITEXIT TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Semaphores APIs.
|
||||||
|
* @details If enabled then the Semaphores APIs are included in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_SEMAPHORES TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Semaphores queuing mode.
|
||||||
|
* @details If enabled then the threads are enqueued on semaphores by
|
||||||
|
* priority rather than in FIFO order.
|
||||||
|
*
|
||||||
|
* @note The default is @p FALSE. Enable this if you have special
|
||||||
|
* requirements.
|
||||||
|
* @note Requires @p CH_CFG_USE_SEMAPHORES.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_SEMAPHORES_PRIORITY FALSE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Mutexes APIs.
|
||||||
|
* @details If enabled then the mutexes APIs are included in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_MUTEXES TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables recursive behavior on mutexes.
|
||||||
|
* @note Recursive mutexes are heavier and have an increased
|
||||||
|
* memory footprint.
|
||||||
|
*
|
||||||
|
* @note The default is @p FALSE.
|
||||||
|
* @note Requires @p CH_CFG_USE_MUTEXES.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_MUTEXES_RECURSIVE FALSE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Conditional Variables APIs.
|
||||||
|
* @details If enabled then the conditional variables APIs are included
|
||||||
|
* in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
* @note Requires @p CH_CFG_USE_MUTEXES.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_CONDVARS TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Conditional Variables APIs with timeout.
|
||||||
|
* @details If enabled then the conditional variables APIs with timeout
|
||||||
|
* specification are included in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
* @note Requires @p CH_CFG_USE_CONDVARS.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_CONDVARS_TIMEOUT TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Events Flags APIs.
|
||||||
|
* @details If enabled then the event flags APIs are included in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_EVENTS TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Events Flags APIs with timeout.
|
||||||
|
* @details If enabled then the events APIs with timeout specification
|
||||||
|
* are included in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
* @note Requires @p CH_CFG_USE_EVENTS.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_EVENTS_TIMEOUT TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Synchronous Messages APIs.
|
||||||
|
* @details If enabled then the synchronous messages APIs are included
|
||||||
|
* in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_MESSAGES TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Synchronous Messages queuing mode.
|
||||||
|
* @details If enabled then messages are served by priority rather than in
|
||||||
|
* FIFO order.
|
||||||
|
*
|
||||||
|
* @note The default is @p FALSE. Enable this if you have special
|
||||||
|
* requirements.
|
||||||
|
* @note Requires @p CH_CFG_USE_MESSAGES.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_MESSAGES_PRIORITY TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Mailboxes APIs.
|
||||||
|
* @details If enabled then the asynchronous messages (mailboxes) APIs are
|
||||||
|
* included in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
* @note Requires @p CH_CFG_USE_SEMAPHORES.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_MAILBOXES TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Core Memory Manager APIs.
|
||||||
|
* @details If enabled then the core memory manager APIs are included
|
||||||
|
* in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_MEMCORE TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Heap Allocator APIs.
|
||||||
|
* @details If enabled then the memory heap allocator APIs are included
|
||||||
|
* in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
* @note Requires @p CH_CFG_USE_MEMCORE and either @p CH_CFG_USE_MUTEXES or
|
||||||
|
* @p CH_CFG_USE_SEMAPHORES.
|
||||||
|
* @note Mutexes are recommended.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_HEAP TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Memory Pools Allocator APIs.
|
||||||
|
* @details If enabled then the memory pools allocator APIs are included
|
||||||
|
* in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_MEMPOOLS TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Dynamic Threads APIs.
|
||||||
|
* @details If enabled then the dynamic threads creation APIs are included
|
||||||
|
* in the kernel.
|
||||||
|
*
|
||||||
|
* @note The default is @p TRUE.
|
||||||
|
* @note Requires @p CH_CFG_USE_WAITEXIT.
|
||||||
|
* @note Requires @p CH_CFG_USE_HEAP and/or @p CH_CFG_USE_MEMPOOLS.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_USE_DYNAMIC TRUE
|
||||||
|
|
||||||
|
/** @} */
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/**
|
||||||
|
* @name Debug options
|
||||||
|
* @{
|
||||||
|
*/
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Debug option, kernel statistics.
|
||||||
|
*
|
||||||
|
* @note The default is @p FALSE.
|
||||||
|
*/
|
||||||
|
#define CH_DBG_STATISTICS FALSE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Debug option, system state check.
|
||||||
|
* @details If enabled the correct call protocol for system APIs is checked
|
||||||
|
* at runtime.
|
||||||
|
*
|
||||||
|
* @note The default is @p FALSE.
|
||||||
|
*/
|
||||||
|
#define CH_DBG_SYSTEM_STATE_CHECK FALSE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Debug option, parameters checks.
|
||||||
|
* @details If enabled then the checks on the API functions input
|
||||||
|
* parameters are activated.
|
||||||
|
*
|
||||||
|
* @note The default is @p FALSE.
|
||||||
|
*/
|
||||||
|
#define CH_DBG_ENABLE_CHECKS FALSE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Debug option, consistency checks.
|
||||||
|
* @details If enabled then all the assertions in the kernel code are
|
||||||
|
* activated. This includes consistency checks inside the kernel,
|
||||||
|
* runtime anomalies and port-defined checks.
|
||||||
|
*
|
||||||
|
* @note The default is @p FALSE.
|
||||||
|
*/
|
||||||
|
#define CH_DBG_ENABLE_ASSERTS FALSE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Debug option, trace buffer.
|
||||||
|
* @details If enabled then the trace buffer is activated.
|
||||||
|
*
|
||||||
|
* @note The default is @p CH_DBG_TRACE_MASK_DISABLED.
|
||||||
|
*/
|
||||||
|
#define CH_DBG_TRACE_MASK CH_DBG_TRACE_MASK_DISABLED
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Trace buffer entries.
|
||||||
|
* @note The trace buffer is only allocated if @p CH_DBG_TRACE_MASK is
|
||||||
|
* different from @p CH_DBG_TRACE_MASK_DISABLED.
|
||||||
|
*/
|
||||||
|
#define CH_DBG_TRACE_BUFFER_SIZE 128
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Debug option, stack checks.
|
||||||
|
* @details If enabled then a runtime stack check is performed.
|
||||||
|
*
|
||||||
|
* @note The default is @p FALSE.
|
||||||
|
* @note The stack check is performed in a architecture/port dependent way.
|
||||||
|
* It may not be implemented or some ports.
|
||||||
|
* @note The default failure mode is to halt the system with the global
|
||||||
|
* @p panic_msg variable set to @p NULL.
|
||||||
|
*/
|
||||||
|
#define CH_DBG_ENABLE_STACK_CHECK TRUE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Debug option, stacks initialization.
|
||||||
|
* @details If enabled then the threads working area is filled with a byte
|
||||||
|
* value when a thread is created. This can be useful for the
|
||||||
|
* runtime measurement of the used stack.
|
||||||
|
*
|
||||||
|
* @note The default is @p FALSE.
|
||||||
|
*/
|
||||||
|
#define CH_DBG_FILL_THREADS FALSE
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Debug option, threads profiling.
|
||||||
|
* @details If enabled then a field is added to the @p thread_t structure that
|
||||||
|
* counts the system ticks occurred while executing the thread.
|
||||||
|
*
|
||||||
|
* @note The default is @p FALSE.
|
||||||
|
* @note This debug option is not currently compatible with the
|
||||||
|
* tickless mode.
|
||||||
|
*/
|
||||||
|
#define CH_DBG_THREADS_PROFILING FALSE
|
||||||
|
|
||||||
|
/** @} */
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/**
|
||||||
|
* @name Kernel hooks
|
||||||
|
* @{
|
||||||
|
*/
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Threads descriptor structure extension.
|
||||||
|
* @details User fields added to the end of the @p thread_t structure.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_THREAD_EXTRA_FIELDS \
|
||||||
|
/* Add threads custom fields here.*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Threads initialization hook.
|
||||||
|
* @details User initialization code added to the @p chThdInit() API.
|
||||||
|
*
|
||||||
|
* @note It is invoked from within @p chThdInit() and implicitly from all
|
||||||
|
* the threads creation APIs.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_THREAD_INIT_HOOK(tp) { \
|
||||||
|
/* Add threads initialization code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Threads finalization hook.
|
||||||
|
* @details User finalization code added to the @p chThdExit() API.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_THREAD_EXIT_HOOK(tp) { \
|
||||||
|
/* Add threads finalization code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Context switch hook.
|
||||||
|
* @details This hook is invoked just before switching between threads.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_CONTEXT_SWITCH_HOOK(ntp, otp) { \
|
||||||
|
/* Context switch code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief ISR enter hook.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_IRQ_PROLOGUE_HOOK() { \
|
||||||
|
/* IRQ prologue code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief ISR exit hook.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_IRQ_EPILOGUE_HOOK() { \
|
||||||
|
/* IRQ epilogue code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Idle thread enter hook.
|
||||||
|
* @note This hook is invoked within a critical zone, no OS functions
|
||||||
|
* should be invoked from here.
|
||||||
|
* @note This macro can be used to activate a power saving mode.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_IDLE_ENTER_HOOK() { \
|
||||||
|
/* Idle-enter code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Idle thread leave hook.
|
||||||
|
* @note This hook is invoked within a critical zone, no OS functions
|
||||||
|
* should be invoked from here.
|
||||||
|
* @note This macro can be used to deactivate a power saving mode.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_IDLE_LEAVE_HOOK() { \
|
||||||
|
/* Idle-leave code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Idle Loop hook.
|
||||||
|
* @details This hook is continuously invoked by the idle thread loop.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_IDLE_LOOP_HOOK() { \
|
||||||
|
/* Idle loop code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief System tick event hook.
|
||||||
|
* @details This hook is invoked in the system tick handler immediately
|
||||||
|
* after processing the virtual timers queue.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_SYSTEM_TICK_HOOK() { \
|
||||||
|
/* System tick event code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief System halt hook.
|
||||||
|
* @details This hook is invoked in case to a system halting error before
|
||||||
|
* the system is halted.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_SYSTEM_HALT_HOOK(reason) { \
|
||||||
|
/* System halt code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Trace hook.
|
||||||
|
* @details This hook is invoked each time a new record is written in the
|
||||||
|
* trace buffer.
|
||||||
|
*/
|
||||||
|
#define CH_CFG_TRACE_HOOK(tep) { \
|
||||||
|
/* Trace code here.*/ \
|
||||||
|
}
|
||||||
|
|
||||||
|
/** @} */
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* Port-specific settings (override port settings defaulted in chcore.h). */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
#endif /* CHCONF_H */
|
||||||
|
|
||||||
|
/** @} */
|
||||||
@@ -0,0 +1,70 @@
|
|||||||
|
/*
|
||||||
|
Copyright 2019 John M Daly <[email protected]>
|
||||||
|
|
||||||
|
This program is free software: you can redistribute it and/or modify
|
||||||
|
it under the terms of the GNU General Public License as published by
|
||||||
|
the Free Software Foundation, either version 2 of the License, or
|
||||||
|
(at your option) any later version.
|
||||||
|
|
||||||
|
This program is distributed in the hope that it will be useful,
|
||||||
|
but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
GNU General Public License for more details.
|
||||||
|
|
||||||
|
You should have received a copy of the GNU General Public License
|
||||||
|
along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
|
||||||
|
#pragma once
|
||||||
|
|
||||||
|
#include "config_common.h"
|
||||||
|
|
||||||
|
/* USB Device descriptor parameter */
|
||||||
|
#define VENDOR_ID 0xFEED
|
||||||
|
#define PRODUCT_ID 0x0000
|
||||||
|
#define DEVICE_VER 0x0001
|
||||||
|
#define MANUFACTURER John M Daly
|
||||||
|
#define PRODUCT CO60 rev7
|
||||||
|
#define DESCRIPTION An open hardware sixty percent PCB
|
||||||
|
|
||||||
|
/* Address for jumping to bootloader on STM32 chips. */
|
||||||
|
/* It is chip dependent, the correct number can be looked up here:
|
||||||
|
* http://www.st.com/web/en/resource/technical/document/application_note/CD00167594.pdf
|
||||||
|
*/
|
||||||
|
#define STM32_BOOTLOADER_ADDRESS 0x1FFFD800
|
||||||
|
|
||||||
|
/* key matrix size */
|
||||||
|
#define MATRIX_ROWS 5
|
||||||
|
#define MATRIX_COLS 15
|
||||||
|
|
||||||
|
/* ROWS: Top to bottom, COLS: Left to right
|
||||||
|
*/
|
||||||
|
#define MATRIX_ROW_PINS { A8, A2, B13, B2, B10 }
|
||||||
|
#define MATRIX_COL_PINS { A10, A9, A3, A4, A5, A6, B0, B1, A15, B3, B4, B5, C13, C14, C15 }
|
||||||
|
#define UNUSED_PINS
|
||||||
|
|
||||||
|
/* COL2ROW, ROW2COL, or CUSTOM_MATRIX */
|
||||||
|
#define DIODE_DIRECTION COL2ROW
|
||||||
|
|
||||||
|
/* Debounce reduces chatter (unintended double-presses) - set 0 if debouncing is not needed */
|
||||||
|
#define DEBOUNCE 5
|
||||||
|
|
||||||
|
/* Mechanical locking support. Use KC_LCAP, KC_LNUM or KC_LSCR instead in keymap */
|
||||||
|
#define LOCKING_SUPPORT_ENABLE
|
||||||
|
/* Locking resynchronize hack */
|
||||||
|
#define LOCKING_RESYNC_ENABLE
|
||||||
|
|
||||||
|
/* Backlight configuration
|
||||||
|
* Backlight LEDs on B8
|
||||||
|
*/
|
||||||
|
#define BACKLIGHT_LEVELS 24
|
||||||
|
#define BACKLIGHT_BREATHING
|
||||||
|
#define BREATHING_PERIOD 6
|
||||||
|
|
||||||
|
#define RGBLIGHT_ANIMATIONS
|
||||||
|
|
||||||
|
#define RGBLED_NUM 16
|
||||||
|
#define RGB_DI_PIN A7
|
||||||
|
#define DRIVER_LED_TOTAL RGBLED_NUM
|
||||||
|
|
||||||
|
#define RGB_MATRIX_KEYPRESSES
|
||||||
@@ -0,0 +1,388 @@
|
|||||||
|
/*
|
||||||
|
ChibiOS - Copyright (C) 2006..2016 Giovanni Di Sirio
|
||||||
|
|
||||||
|
Licensed under the Apache License, Version 2.0 (the "License");
|
||||||
|
you may not use this file except in compliance with the License.
|
||||||
|
You may obtain a copy of the License at
|
||||||
|
|
||||||
|
http://www.apache.org/licenses/LICENSE-2.0
|
||||||
|
|
||||||
|
Unless required by applicable law or agreed to in writing, software
|
||||||
|
distributed under the License is distributed on an "AS IS" BASIS,
|
||||||
|
WITHOUT WARRANTIES OR CONDITIONS OF ANY KIND, either express or implied.
|
||||||
|
See the License for the specific language governing permissions and
|
||||||
|
limitations under the License.
|
||||||
|
*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @file templates/halconf.h
|
||||||
|
* @brief HAL configuration header.
|
||||||
|
* @details HAL configuration file, this file allows to enable or disable the
|
||||||
|
* various device drivers from your application. You may also use
|
||||||
|
* this file in order to override the device drivers default settings.
|
||||||
|
*
|
||||||
|
* @addtogroup HAL_CONF
|
||||||
|
* @{
|
||||||
|
*/
|
||||||
|
|
||||||
|
#ifndef HALCONF_H
|
||||||
|
#define HALCONF_H
|
||||||
|
|
||||||
|
#include "mcuconf.h"
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the PAL subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_PAL) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_PAL TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the ADC subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_ADC) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_ADC FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the CAN subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_CAN) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_CAN FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the DAC subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_DAC) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_DAC TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the EXT subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_EXT) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_EXT FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the GPT subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_GPT) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_GPT TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the I2C subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_I2C) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_I2C FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the I2S subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_I2S) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_I2S FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the ICU subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_ICU) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_ICU FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the MAC subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_MAC) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_MAC FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the MMC_SPI subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_MMC_SPI) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_MMC_SPI FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the PWM subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_PWM) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_PWM TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the QSPI subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_QSPI) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_QSPI FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the RTC subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_RTC) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_RTC FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the SDC subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_SDC) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_SDC FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the SERIAL subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_SERIAL) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_SERIAL FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the SERIAL over USB subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_SERIAL_USB) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_SERIAL_USB TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the SPI subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_SPI) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_SPI FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the UART subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_UART) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_UART FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the USB subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_USB) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_USB TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the WDG subsystem.
|
||||||
|
*/
|
||||||
|
#if !defined(HAL_USE_WDG) || defined(__DOXYGEN__)
|
||||||
|
#define HAL_USE_WDG FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* ADC driver related settings. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables synchronous APIs.
|
||||||
|
* @note Disabling this option saves both code and data space.
|
||||||
|
*/
|
||||||
|
#if !defined(ADC_USE_WAIT) || defined(__DOXYGEN__)
|
||||||
|
#define ADC_USE_WAIT TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the @p adcAcquireBus() and @p adcReleaseBus() APIs.
|
||||||
|
* @note Disabling this option saves both code and data space.
|
||||||
|
*/
|
||||||
|
#if !defined(ADC_USE_MUTUAL_EXCLUSION) || defined(__DOXYGEN__)
|
||||||
|
#define ADC_USE_MUTUAL_EXCLUSION TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* CAN driver related settings. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Sleep mode related APIs inclusion switch.
|
||||||
|
*/
|
||||||
|
#if !defined(CAN_USE_SLEEP_MODE) || defined(__DOXYGEN__)
|
||||||
|
#define CAN_USE_SLEEP_MODE TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* I2C driver related settings. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the mutual exclusion APIs on the I2C bus.
|
||||||
|
*/
|
||||||
|
#if !defined(I2C_USE_MUTUAL_EXCLUSION) || defined(__DOXYGEN__)
|
||||||
|
#define I2C_USE_MUTUAL_EXCLUSION TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* MAC driver related settings. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables an event sources for incoming packets.
|
||||||
|
*/
|
||||||
|
#if !defined(MAC_USE_ZERO_COPY) || defined(__DOXYGEN__)
|
||||||
|
#define MAC_USE_ZERO_COPY FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables an event sources for incoming packets.
|
||||||
|
*/
|
||||||
|
#if !defined(MAC_USE_EVENTS) || defined(__DOXYGEN__)
|
||||||
|
#define MAC_USE_EVENTS TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* MMC_SPI driver related settings. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Delays insertions.
|
||||||
|
* @details If enabled this options inserts delays into the MMC waiting
|
||||||
|
* routines releasing some extra CPU time for the threads with
|
||||||
|
* lower priority, this may slow down the driver a bit however.
|
||||||
|
* This option is recommended also if the SPI driver does not
|
||||||
|
* use a DMA channel and heavily loads the CPU.
|
||||||
|
*/
|
||||||
|
#if !defined(MMC_NICE_WAITING) || defined(__DOXYGEN__)
|
||||||
|
#define MMC_NICE_WAITING TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* SDC driver related settings. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Number of initialization attempts before rejecting the card.
|
||||||
|
* @note Attempts are performed at 10mS intervals.
|
||||||
|
*/
|
||||||
|
#if !defined(SDC_INIT_RETRY) || defined(__DOXYGEN__)
|
||||||
|
#define SDC_INIT_RETRY 100
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Include support for MMC cards.
|
||||||
|
* @note MMC support is not yet implemented so this option must be kept
|
||||||
|
* at @p FALSE.
|
||||||
|
*/
|
||||||
|
#if !defined(SDC_MMC_SUPPORT) || defined(__DOXYGEN__)
|
||||||
|
#define SDC_MMC_SUPPORT FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Delays insertions.
|
||||||
|
* @details If enabled this options inserts delays into the MMC waiting
|
||||||
|
* routines releasing some extra CPU time for the threads with
|
||||||
|
* lower priority, this may slow down the driver a bit however.
|
||||||
|
*/
|
||||||
|
#if !defined(SDC_NICE_WAITING) || defined(__DOXYGEN__)
|
||||||
|
#define SDC_NICE_WAITING TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* SERIAL driver related settings. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Default bit rate.
|
||||||
|
* @details Configuration parameter, this is the baud rate selected for the
|
||||||
|
* default configuration.
|
||||||
|
*/
|
||||||
|
#if !defined(SERIAL_DEFAULT_BITRATE) || defined(__DOXYGEN__)
|
||||||
|
#define SERIAL_DEFAULT_BITRATE 38400
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Serial buffers size.
|
||||||
|
* @details Configuration parameter, you can change the depth of the queue
|
||||||
|
* buffers depending on the requirements of your application.
|
||||||
|
* @note The default is 16 bytes for both the transmission and receive
|
||||||
|
* buffers.
|
||||||
|
*/
|
||||||
|
#if !defined(SERIAL_BUFFERS_SIZE) || defined(__DOXYGEN__)
|
||||||
|
#define SERIAL_BUFFERS_SIZE 16
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* SERIAL_USB driver related setting. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Serial over USB buffers size.
|
||||||
|
* @details Configuration parameter, the buffer size must be a multiple of
|
||||||
|
* the USB data endpoint maximum packet size.
|
||||||
|
* @note The default is 256 bytes for both the transmission and receive
|
||||||
|
* buffers.
|
||||||
|
*/
|
||||||
|
#if !defined(SERIAL_USB_BUFFERS_SIZE) || defined(__DOXYGEN__)
|
||||||
|
#define SERIAL_USB_BUFFERS_SIZE 1
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Serial over USB number of buffers.
|
||||||
|
* @note The default is 2 buffers.
|
||||||
|
*/
|
||||||
|
#if !defined(SERIAL_USB_BUFFERS_NUMBER) || defined(__DOXYGEN__)
|
||||||
|
#define SERIAL_USB_BUFFERS_NUMBER 2
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* SPI driver related settings. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables synchronous APIs.
|
||||||
|
* @note Disabling this option saves both code and data space.
|
||||||
|
*/
|
||||||
|
#if !defined(SPI_USE_WAIT) || defined(__DOXYGEN__)
|
||||||
|
#define SPI_USE_WAIT TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the @p spiAcquireBus() and @p spiReleaseBus() APIs.
|
||||||
|
* @note Disabling this option saves both code and data space.
|
||||||
|
*/
|
||||||
|
#if !defined(SPI_USE_MUTUAL_EXCLUSION) || defined(__DOXYGEN__)
|
||||||
|
#define SPI_USE_MUTUAL_EXCLUSION TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* UART driver related settings. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables synchronous APIs.
|
||||||
|
* @note Disabling this option saves both code and data space.
|
||||||
|
*/
|
||||||
|
#if !defined(UART_USE_WAIT) || defined(__DOXYGEN__)
|
||||||
|
#define UART_USE_WAIT FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables the @p uartAcquireBus() and @p uartReleaseBus() APIs.
|
||||||
|
* @note Disabling this option saves both code and data space.
|
||||||
|
*/
|
||||||
|
#if !defined(UART_USE_MUTUAL_EXCLUSION) || defined(__DOXYGEN__)
|
||||||
|
#define UART_USE_MUTUAL_EXCLUSION FALSE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/*===========================================================================*/
|
||||||
|
/* USB driver related settings. */
|
||||||
|
/*===========================================================================*/
|
||||||
|
|
||||||
|
/**
|
||||||
|
* @brief Enables synchronous APIs.
|
||||||
|
* @note Disabling this option saves both code and data space.
|
||||||
|
*/
|
||||||
|
#if !defined(USB_USE_WAIT) || defined(__DOXYGEN__)
|
||||||
|
#define USB_USE_WAIT TRUE
|
||||||
|
#endif
|
||||||
|
|
||||||
|
#endif /* HALCONF_H */
|
||||||
|
|
||||||
|
/** @} */
|
||||||
@@ -0,0 +1,242 @@
|
|||||||
|
/*
|
||||||
|
Copyright 2012 Jun Wako <[email protected]>
|
||||||
|
|
||||||
|
This program is free software: you can redistribute it and/or modify
|
||||||
|
it under the terms of the GNU General Public License as published by
|
||||||
|
the Free Software Foundation, either version 2 of the License, or
|
||||||
|
(at your option) any later version.
|
||||||
|
|
||||||
|
This program is distributed in the hope that it will be useful,
|
||||||
|
but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
GNU General Public License for more details.
|
||||||
|
|
||||||
|
You should have received a copy of the GNU General Public License
|
||||||
|
along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
|
||||||
|
#include "hal.h"
|
||||||
|
#include "led_custom.h"
|
||||||
|
#include "rev7.h"
|
||||||
|
#include "printf.h"
|
||||||
|
|
||||||
|
static void breathing_callback(PWMDriver *pwmp);
|
||||||
|
|
||||||
|
static PWMConfig pwmCFG = {
|
||||||
|
0xFFFF, /* PWM clock frequency */
|
||||||
|
256, /* PWM period (in ticks) 1S (1/10kHz=0.1mS 0.1ms*10000 ticks=1S) */
|
||||||
|
NULL, /* No Callback */
|
||||||
|
{
|
||||||
|
{PWM_OUTPUT_DISABLED, NULL},
|
||||||
|
{PWM_OUTPUT_DISABLED, NULL},
|
||||||
|
{PWM_OUTPUT_ACTIVE_HIGH, NULL}, /* Enable Channel 3 */
|
||||||
|
{PWM_OUTPUT_DISABLED, NULL}
|
||||||
|
},
|
||||||
|
0, /* HW dependent part.*/
|
||||||
|
0
|
||||||
|
};
|
||||||
|
|
||||||
|
static PWMConfig pwmCFG_breathing = {
|
||||||
|
0xFFFF, /* 10kHz PWM clock frequency */
|
||||||
|
256, /* PWM period (in ticks) 1S (1/10kHz=0.1mS 0.1ms*10000 ticks=1S) */
|
||||||
|
breathing_callback, /* Breathing Callback */
|
||||||
|
{
|
||||||
|
{PWM_OUTPUT_DISABLED, NULL},
|
||||||
|
{PWM_OUTPUT_DISABLED, NULL},
|
||||||
|
{PWM_OUTPUT_ACTIVE_HIGH, NULL}, /* Enable Channel 3 */
|
||||||
|
{PWM_OUTPUT_DISABLED, NULL}
|
||||||
|
},
|
||||||
|
0, /* HW dependent part.*/
|
||||||
|
0
|
||||||
|
};
|
||||||
|
|
||||||
|
// See http://jared.geek.nz/2013/feb/linear-led-pwm
|
||||||
|
static uint16_t cie_lightness(uint16_t v) {
|
||||||
|
if (v <= 5243) // if below 8% of max
|
||||||
|
return v / 9; // same as dividing by 900%
|
||||||
|
else {
|
||||||
|
uint32_t y = (((uint32_t) v + 10486) << 8) / (10486 + 0xFFFFUL); // add 16% of max and compare
|
||||||
|
// to get a useful result with integer division, we shift left in the expression above
|
||||||
|
// and revert what we've done again after squaring.
|
||||||
|
y = y * y * y >> 8;
|
||||||
|
if (y > 0xFFFFUL) // prevent overflow
|
||||||
|
return 0xFFFFU;
|
||||||
|
else
|
||||||
|
return (uint16_t) y;
|
||||||
|
}
|
||||||
|
}
|
||||||
|
|
||||||
|
|
||||||
|
void backlight_init_ports(void) {
|
||||||
|
palSetPadMode(GPIOB, 8, PAL_MODE_ALTERNATE(2));
|
||||||
|
pwmStart(&PWMD4, &pwmCFG);
|
||||||
|
if(kb_backlight_config.enable){
|
||||||
|
if(kb_backlight_config.breathing){
|
||||||
|
breathing_enable();
|
||||||
|
} else{
|
||||||
|
backlight_set(kb_backlight_config.level);
|
||||||
|
}
|
||||||
|
} else {
|
||||||
|
backlight_set(0);
|
||||||
|
}
|
||||||
|
}
|
||||||
|
|
||||||
|
void backlight_set(uint8_t level) {
|
||||||
|
uint32_t duty = (uint32_t)(cie_lightness(0xFFFF * (uint32_t) level / BACKLIGHT_LEVELS));
|
||||||
|
if (level == 0) {
|
||||||
|
// Turn backlight off
|
||||||
|
// Disable channel 3 on PWM4
|
||||||
|
pwmDisableChannel(&PWMD4, 2);
|
||||||
|
} else {
|
||||||
|
// Turn backlight on
|
||||||
|
if(!is_breathing()){
|
||||||
|
// Enable channel 3 on PWM4
|
||||||
|
pwmEnableChannel(&PWMD4, 2, PWM_FRACTION_TO_WIDTH(&PWMD4,0xFFFF,duty));
|
||||||
|
}
|
||||||
|
}
|
||||||
|
}
|
||||||
|
|
||||||
|
|
||||||
|
uint8_t backlight_tick = 0;
|
||||||
|
|
||||||
|
void backlight_task(void) {
|
||||||
|
}
|
||||||
|
|
||||||
|
#define BREATHING_NO_HALT 0
|
||||||
|
#define BREATHING_HALT_OFF 1
|
||||||
|
#define BREATHING_HALT_ON 2
|
||||||
|
#define BREATHING_STEPS 128
|
||||||
|
|
||||||
|
static uint8_t breathing_period = BREATHING_PERIOD;
|
||||||
|
static uint8_t breathing_halt = BREATHING_NO_HALT;
|
||||||
|
static uint16_t breathing_counter = 0;
|
||||||
|
|
||||||
|
bool is_breathing(void) {
|
||||||
|
return PWMD4.config == &pwmCFG_breathing;
|
||||||
|
}
|
||||||
|
|
||||||
|
#define breathing_min() do {breathing_counter = 0;} while (0)
|
||||||
|
#define breathing_max() do {breathing_counter = breathing_period * 256 / 2;} while (0)
|
||||||
|
|
||||||
|
|
||||||
|
void breathing_interrupt_enable(void){
|
||||||
|
pwmStop(&PWMD4);
|
||||||
|
pwmStart(&PWMD4, &pwmCFG_breathing);
|
||||||
|
chSysLockFromISR();
|
||||||
|
pwmEnablePeriodicNotification(&PWMD4);
|
||||||
|
pwmEnableChannelI(
|
||||||
|
&PWMD4,
|
||||||
|
2,
|
||||||
|
PWM_FRACTION_TO_WIDTH(
|
||||||
|
&PWMD4,
|
||||||
|
0xFFFF,
|
||||||
|
0xFFFF
|
||||||
|
)
|
||||||
|
);
|
||||||
|
chSysUnlockFromISR();
|
||||||
|
}
|
||||||
|
|
||||||
|
void breathing_interrupt_disable(void){
|
||||||
|
pwmStop(&PWMD4);
|
||||||
|
pwmStart(&PWMD4, &pwmCFG);
|
||||||
|
}
|
||||||
|
|
||||||
|
void breathing_enable(void)
|
||||||
|
{
|
||||||
|
breathing_counter = 0;
|
||||||
|
breathing_halt = BREATHING_NO_HALT;
|
||||||
|
breathing_interrupt_enable();
|
||||||
|
}
|
||||||
|
|
||||||
|
void breathing_pulse(void)
|
||||||
|
{
|
||||||
|
if (kb_backlight_config.level == 0)
|
||||||
|
breathing_min();
|
||||||
|
else
|
||||||
|
breathing_max();
|
||||||
|
breathing_halt = BREATHING_HALT_ON;
|
||||||
|
breathing_interrupt_enable();
|
||||||
|
}
|
||||||
|
|
||||||
|
void breathing_disable(void)
|
||||||
|
{
|
||||||
|
breathing_interrupt_disable();
|
||||||
|
// Restore backlight level
|
||||||
|
backlight_set(kb_backlight_config.level);
|
||||||
|
}
|
||||||
|
|
||||||
|
void breathing_self_disable(void)
|
||||||
|
{
|
||||||
|
if (kb_backlight_config.level == 0)
|
||||||
|
breathing_halt = BREATHING_HALT_OFF;
|
||||||
|
else
|
||||||
|
breathing_halt = BREATHING_HALT_ON;
|
||||||
|
}
|
||||||
|
|
||||||
|
void breathing_toggle(void) {
|
||||||
|
if (is_breathing()){
|
||||||
|
breathing_disable();
|
||||||
|
} else {
|
||||||
|
breathing_enable();
|
||||||
|
}
|
||||||
|
}
|
||||||
|
|
||||||
|
void breathing_period_set(uint8_t value)
|
||||||
|
{
|
||||||
|
if (!value)
|
||||||
|
value = 1;
|
||||||
|
breathing_period = value;
|
||||||
|
}
|
||||||
|
|
||||||
|
void breathing_period_default(void) {
|
||||||
|
breathing_period_set(BREATHING_PERIOD);
|
||||||
|
}
|
||||||
|
|
||||||
|
void breathing_period_inc(void)
|
||||||
|
{
|
||||||
|
breathing_period_set(breathing_period+1);
|
||||||
|
}
|
||||||
|
|
||||||
|
void breathing_period_dec(void)
|
||||||
|
{
|
||||||
|
breathing_period_set(breathing_period-1);
|
||||||
|
}
|
||||||
|
|
||||||
|
/* To generate breathing curve in python:
|
||||||
|
* from math import sin, pi; [int(sin(x/128.0*pi)**4*255) for x in range(128)]
|
||||||
|
*/
|
||||||
|
static const uint8_t breathing_table[BREATHING_STEPS] = {0, 0, 0, 0, 0, 0, 0, 0, 0, 0, 0, 1, 1, 2, 3, 4, 5, 6, 8, 10, 12, 15, 17, 20, 24, 28, 32, 36, 41, 46, 51, 57, 63, 70, 76, 83, 91, 98, 106, 113, 121, 129, 138, 146, 154, 162, 170, 178, 185, 193, 200, 207, 213, 220, 225, 231, 235, 240, 244, 247, 250, 252, 253, 254, 255, 254, 253, 252, 250, 247, 244, 240, 235, 231, 225, 220, 213, 207, 200, 193, 185, 178, 170, 162, 154, 146, 138, 129, 121, 113, 106, 98, 91, 83, 76, 70, 63, 57, 51, 46, 41, 36, 32, 28, 24, 20, 17, 15, 12, 10, 8, 6, 5, 4, 3, 2, 1, 1, 0, 0, 0, 0, 0, 0, 0, 0, 0, 0};
|
||||||
|
|
||||||
|
// Use this before the cie_lightness function.
|
||||||
|
static inline uint16_t scale_backlight(uint16_t v) {
|
||||||
|
return v / BACKLIGHT_LEVELS * kb_backlight_config.level;
|
||||||
|
}
|
||||||
|
|
||||||
|
static void breathing_callback(PWMDriver *pwmp)
|
||||||
|
{
|
||||||
|
(void)pwmp;
|
||||||
|
uint16_t interval = (uint16_t) breathing_period * 256 / BREATHING_STEPS;
|
||||||
|
// resetting after one period to prevent ugly reset at overflow.
|
||||||
|
breathing_counter = (breathing_counter + 1) % (breathing_period * 256);
|
||||||
|
uint8_t index = breathing_counter / interval % BREATHING_STEPS;
|
||||||
|
|
||||||
|
if (((breathing_halt == BREATHING_HALT_ON) && (index == BREATHING_STEPS / 2)) ||
|
||||||
|
((breathing_halt == BREATHING_HALT_OFF) && (index == BREATHING_STEPS - 1)))
|
||||||
|
{
|
||||||
|
breathing_interrupt_disable();
|
||||||
|
}
|
||||||
|
|
||||||
|
uint32_t duty = cie_lightness(scale_backlight(breathing_table[index] * 256));
|
||||||
|
|
||||||
|
chSysLockFromISR();
|
||||||
|
pwmEnableChannelI(
|
||||||
|
&PWMD4,
|
||||||
|
2,
|
||||||
|
PWM_FRACTION_TO_WIDTH(
|
||||||
|
&PWMD4,
|
||||||
|
0xFFFF,
|
||||||
|
duty
|
||||||
|
)
|
||||||
|
);
|
||||||
|
chSysUnlockFromISR();
|
||||||
|
}
|
||||||
+4
-7
@@ -1,8 +1,5 @@
|
|||||||
/*
|
/*
|
||||||
This is the c configuration file for the keymap
|
Copyright 2019 John M Daly <jmdaly@gmail.com>
|
||||||
|
|
||||||
Copyright 2012 Jun Wako <wakojun@gmail.com>
|
|
||||||
Copyright 2015 Jack Humbert
|
|
||||||
|
|
||||||
This program is free software: you can redistribute it and/or modify
|
This program is free software: you can redistribute it and/or modify
|
||||||
it under the terms of the GNU General Public License as published by
|
it under the terms of the GNU General Public License as published by
|
||||||
@@ -20,6 +17,6 @@ along with this program. If not, see <http://www.gnu.org/licenses/>.
|
|||||||
|
|
||||||
#pragma once
|
#pragma once
|
||||||
|
|
||||||
|
void backlight_task(void);
|
||||||
// place overrides here
|
void breathing_interrupt_disable(void);
|
||||||
|
void breathing_interrupt_enable(void);
|
||||||
@@ -0,0 +1,257 @@
|
|||||||
|
/*
|
||||||
|
ChibiOS - Copyright (C) 2006..2016 Giovanni Di Sirio
|
||||||
|
|
||||||
|
Licensed under the Apache License, Version 2.0 (the "License");
|
||||||
|
you may not use this file except in compliance with the License.
|
||||||
|
You may obtain a copy of the License at
|
||||||
|
|
||||||
|
http://www.apache.org/licenses/LICENSE-2.0
|
||||||
|
|
||||||
|
Unless required by applicable law or agreed to in writing, software
|
||||||
|
distributed under the License is distributed on an "AS IS" BASIS,
|
||||||
|
WITHOUT WARRANTIES OR CONDITIONS OF ANY KIND, either express or implied.
|
||||||
|
See the License for the specific language governing permissions and
|
||||||
|
limitations under the License.
|
||||||
|
*/
|
||||||
|
|
||||||
|
#ifndef MCUCONF_H
|
||||||
|
#define MCUCONF_H
|
||||||
|
|
||||||
|
/*
|
||||||
|
* STM32F3xx drivers configuration.
|
||||||
|
* The following settings override the default settings present in
|
||||||
|
* the various device driver implementation headers.
|
||||||
|
* Note that the settings for each driver only have effect if the whole
|
||||||
|
* driver is enabled in halconf.h.
|
||||||
|
*
|
||||||
|
* IRQ priorities:
|
||||||
|
* 15...0 Lowest...Highest.
|
||||||
|
*
|
||||||
|
* DMA priorities:
|
||||||
|
* 0...3 Lowest...Highest.
|
||||||
|
*/
|
||||||
|
|
||||||
|
#define STM32F3xx_MCUCONF
|
||||||
|
|
||||||
|
/*
|
||||||
|
* HAL driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_NO_INIT FALSE
|
||||||
|
#define STM32_PVD_ENABLE FALSE
|
||||||
|
#define STM32_PLS STM32_PLS_LEV0
|
||||||
|
#define STM32_HSI_ENABLED TRUE
|
||||||
|
#define STM32_LSI_ENABLED TRUE
|
||||||
|
#define STM32_HSE_ENABLED TRUE
|
||||||
|
#define STM32_LSE_ENABLED FALSE
|
||||||
|
#define STM32_SW STM32_SW_PLL
|
||||||
|
#define STM32_PLLSRC STM32_PLLSRC_HSE
|
||||||
|
#define STM32_PREDIV_VALUE 1
|
||||||
|
#define STM32_PLLMUL_VALUE 9
|
||||||
|
#define STM32_HPRE STM32_HPRE_DIV1
|
||||||
|
#define STM32_PPRE1 STM32_PPRE1_DIV2
|
||||||
|
#define STM32_PPRE2 STM32_PPRE2_DIV2
|
||||||
|
#define STM32_MCOSEL STM32_MCOSEL_NOCLOCK
|
||||||
|
#define STM32_ADC12PRES STM32_ADC12PRES_DIV1
|
||||||
|
#define STM32_ADC34PRES STM32_ADC34PRES_DIV1
|
||||||
|
#define STM32_USART1SW STM32_USART1SW_PCLK
|
||||||
|
#define STM32_USART2SW STM32_USART2SW_PCLK
|
||||||
|
#define STM32_USART3SW STM32_USART3SW_PCLK
|
||||||
|
#define STM32_UART4SW STM32_UART4SW_PCLK
|
||||||
|
#define STM32_UART5SW STM32_UART5SW_PCLK
|
||||||
|
#define STM32_I2C1SW STM32_I2C1SW_SYSCLK
|
||||||
|
#define STM32_I2C2SW STM32_I2C2SW_SYSCLK
|
||||||
|
#define STM32_TIM1SW STM32_TIM1SW_PCLK2
|
||||||
|
#define STM32_TIM8SW STM32_TIM8SW_PCLK2
|
||||||
|
#define STM32_RTCSEL STM32_RTCSEL_LSI
|
||||||
|
#define STM32_USB_CLOCK_REQUIRED TRUE
|
||||||
|
#define STM32_USBPRE STM32_USBPRE_DIV1P5
|
||||||
|
|
||||||
|
#undef STM32_HSE_BYPASS
|
||||||
|
// #error "oh no"
|
||||||
|
// #endif
|
||||||
|
|
||||||
|
/*
|
||||||
|
* ADC driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_ADC_DUAL_MODE FALSE
|
||||||
|
#define STM32_ADC_COMPACT_SAMPLES FALSE
|
||||||
|
#define STM32_ADC_USE_ADC1 FALSE
|
||||||
|
#define STM32_ADC_USE_ADC2 FALSE
|
||||||
|
#define STM32_ADC_USE_ADC3 FALSE
|
||||||
|
#define STM32_ADC_USE_ADC4 FALSE
|
||||||
|
#define STM32_ADC_ADC1_DMA_STREAM STM32_DMA_STREAM_ID(1, 1)
|
||||||
|
#define STM32_ADC_ADC2_DMA_STREAM STM32_DMA_STREAM_ID(2, 1)
|
||||||
|
#define STM32_ADC_ADC3_DMA_STREAM STM32_DMA_STREAM_ID(2, 5)
|
||||||
|
#define STM32_ADC_ADC4_DMA_STREAM STM32_DMA_STREAM_ID(2, 2)
|
||||||
|
#define STM32_ADC_ADC1_DMA_PRIORITY 2
|
||||||
|
#define STM32_ADC_ADC2_DMA_PRIORITY 2
|
||||||
|
#define STM32_ADC_ADC3_DMA_PRIORITY 2
|
||||||
|
#define STM32_ADC_ADC4_DMA_PRIORITY 2
|
||||||
|
#define STM32_ADC_ADC12_IRQ_PRIORITY 5
|
||||||
|
#define STM32_ADC_ADC3_IRQ_PRIORITY 5
|
||||||
|
#define STM32_ADC_ADC4_IRQ_PRIORITY 5
|
||||||
|
#define STM32_ADC_ADC1_DMA_IRQ_PRIORITY 5
|
||||||
|
#define STM32_ADC_ADC2_DMA_IRQ_PRIORITY 5
|
||||||
|
#define STM32_ADC_ADC3_DMA_IRQ_PRIORITY 5
|
||||||
|
#define STM32_ADC_ADC4_DMA_IRQ_PRIORITY 5
|
||||||
|
#define STM32_ADC_ADC12_CLOCK_MODE ADC_CCR_CKMODE_AHB_DIV1
|
||||||
|
#define STM32_ADC_ADC34_CLOCK_MODE ADC_CCR_CKMODE_AHB_DIV1
|
||||||
|
|
||||||
|
/*
|
||||||
|
* CAN driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_CAN_USE_CAN1 FALSE
|
||||||
|
#define STM32_CAN_CAN1_IRQ_PRIORITY 11
|
||||||
|
|
||||||
|
/*
|
||||||
|
* DAC driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_DAC_DUAL_MODE FALSE
|
||||||
|
#define STM32_DAC_USE_DAC1_CH1 TRUE
|
||||||
|
#define STM32_DAC_USE_DAC1_CH2 TRUE
|
||||||
|
#define STM32_DAC_DAC1_CH1_IRQ_PRIORITY 10
|
||||||
|
#define STM32_DAC_DAC1_CH2_IRQ_PRIORITY 10
|
||||||
|
#define STM32_DAC_DAC1_CH1_DMA_PRIORITY 2
|
||||||
|
#define STM32_DAC_DAC1_CH2_DMA_PRIORITY 2
|
||||||
|
|
||||||
|
/*
|
||||||
|
* EXT driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_EXT_EXTI0_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI1_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI2_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI3_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI4_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI5_9_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI10_15_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI16_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI17_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI18_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI19_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI20_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI21_22_29_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI30_32_IRQ_PRIORITY 6
|
||||||
|
#define STM32_EXT_EXTI33_IRQ_PRIORITY 6
|
||||||
|
|
||||||
|
/*
|
||||||
|
* GPT driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_GPT_USE_TIM1 FALSE
|
||||||
|
#define STM32_GPT_USE_TIM2 FALSE
|
||||||
|
#define STM32_GPT_USE_TIM3 FALSE
|
||||||
|
#define STM32_GPT_USE_TIM4 FALSE
|
||||||
|
#define STM32_GPT_USE_TIM6 TRUE
|
||||||
|
#define STM32_GPT_USE_TIM7 TRUE
|
||||||
|
#define STM32_GPT_USE_TIM8 TRUE
|
||||||
|
#define STM32_GPT_TIM1_IRQ_PRIORITY 7
|
||||||
|
#define STM32_GPT_TIM2_IRQ_PRIORITY 7
|
||||||
|
#define STM32_GPT_TIM3_IRQ_PRIORITY 7
|
||||||
|
#define STM32_GPT_TIM4_IRQ_PRIORITY 7
|
||||||
|
#define STM32_GPT_TIM6_IRQ_PRIORITY 7
|
||||||
|
#define STM32_GPT_TIM7_IRQ_PRIORITY 7
|
||||||
|
#define STM32_GPT_TIM8_IRQ_PRIORITY 7
|
||||||
|
|
||||||
|
/*
|
||||||
|
* I2C driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_I2C_USE_I2C1 FALSE
|
||||||
|
#define STM32_I2C_USE_I2C2 FALSE
|
||||||
|
#define STM32_I2C_BUSY_TIMEOUT 50
|
||||||
|
#define STM32_I2C_I2C1_IRQ_PRIORITY 10
|
||||||
|
#define STM32_I2C_I2C2_IRQ_PRIORITY 10
|
||||||
|
#define STM32_I2C_USE_DMA TRUE
|
||||||
|
#define STM32_I2C_I2C1_DMA_PRIORITY 1
|
||||||
|
#define STM32_I2C_I2C2_DMA_PRIORITY 1
|
||||||
|
#define STM32_I2C_DMA_ERROR_HOOK(i2cp) osalSysHalt("DMA failure")
|
||||||
|
|
||||||
|
/*
|
||||||
|
* ICU driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_ICU_USE_TIM1 FALSE
|
||||||
|
#define STM32_ICU_USE_TIM2 FALSE
|
||||||
|
#define STM32_ICU_USE_TIM3 FALSE
|
||||||
|
#define STM32_ICU_USE_TIM4 FALSE
|
||||||
|
#define STM32_ICU_USE_TIM8 FALSE
|
||||||
|
#define STM32_ICU_TIM1_IRQ_PRIORITY 7
|
||||||
|
#define STM32_ICU_TIM2_IRQ_PRIORITY 7
|
||||||
|
#define STM32_ICU_TIM3_IRQ_PRIORITY 7
|
||||||
|
#define STM32_ICU_TIM4_IRQ_PRIORITY 7
|
||||||
|
#define STM32_ICU_TIM8_IRQ_PRIORITY 7
|
||||||
|
|
||||||
|
/*
|
||||||
|
* PWM driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_PWM_USE_ADVANCED FALSE
|
||||||
|
#define STM32_PWM_USE_TIM1 FALSE
|
||||||
|
#define STM32_PWM_USE_TIM2 FALSE
|
||||||
|
#define STM32_PWM_USE_TIM3 FALSE
|
||||||
|
#define STM32_PWM_USE_TIM4 TRUE
|
||||||
|
#define STM32_PWM_USE_TIM8 FALSE
|
||||||
|
#define STM32_PWM_TIM1_IRQ_PRIORITY 7
|
||||||
|
#define STM32_PWM_TIM2_IRQ_PRIORITY 7
|
||||||
|
#define STM32_PWM_TIM3_IRQ_PRIORITY 7
|
||||||
|
#define STM32_PWM_TIM4_IRQ_PRIORITY 7
|
||||||
|
#define STM32_PWM_TIM8_IRQ_PRIORITY 7
|
||||||
|
|
||||||
|
/*
|
||||||
|
* SERIAL driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_SERIAL_USE_USART1 FALSE
|
||||||
|
#define STM32_SERIAL_USE_USART2 TRUE
|
||||||
|
#define STM32_SERIAL_USE_USART3 FALSE
|
||||||
|
#define STM32_SERIAL_USE_UART4 FALSE
|
||||||
|
#define STM32_SERIAL_USE_UART5 FALSE
|
||||||
|
#define STM32_SERIAL_USART1_PRIORITY 12
|
||||||
|
#define STM32_SERIAL_USART2_PRIORITY 12
|
||||||
|
#define STM32_SERIAL_USART3_PRIORITY 12
|
||||||
|
#define STM32_SERIAL_UART4_PRIORITY 12
|
||||||
|
#define STM32_SERIAL_UART5_PRIORITY 12
|
||||||
|
|
||||||
|
/*
|
||||||
|
* SPI driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_SPI_USE_SPI1 FALSE
|
||||||
|
#define STM32_SPI_USE_SPI2 FALSE
|
||||||
|
#define STM32_SPI_USE_SPI3 FALSE
|
||||||
|
#define STM32_SPI_SPI1_DMA_PRIORITY 1
|
||||||
|
#define STM32_SPI_SPI2_DMA_PRIORITY 1
|
||||||
|
#define STM32_SPI_SPI3_DMA_PRIORITY 1
|
||||||
|
#define STM32_SPI_SPI1_IRQ_PRIORITY 10
|
||||||
|
#define STM32_SPI_SPI2_IRQ_PRIORITY 10
|
||||||
|
#define STM32_SPI_SPI3_IRQ_PRIORITY 10
|
||||||
|
#define STM32_SPI_DMA_ERROR_HOOK(spip) osalSysHalt("DMA failure")
|
||||||
|
|
||||||
|
/*
|
||||||
|
* ST driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_ST_IRQ_PRIORITY 8
|
||||||
|
#define STM32_ST_USE_TIMER 2
|
||||||
|
|
||||||
|
/*
|
||||||
|
* UART driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_UART_USE_USART1 FALSE
|
||||||
|
#define STM32_UART_USE_USART2 FALSE
|
||||||
|
#define STM32_UART_USE_USART3 FALSE
|
||||||
|
#define STM32_UART_USART1_IRQ_PRIORITY 12
|
||||||
|
#define STM32_UART_USART2_IRQ_PRIORITY 12
|
||||||
|
#define STM32_UART_USART3_IRQ_PRIORITY 12
|
||||||
|
#define STM32_UART_USART1_DMA_PRIORITY 0
|
||||||
|
#define STM32_UART_USART2_DMA_PRIORITY 0
|
||||||
|
#define STM32_UART_USART3_DMA_PRIORITY 0
|
||||||
|
#define STM32_UART_DMA_ERROR_HOOK(uartp) osalSysHalt("DMA failure")
|
||||||
|
|
||||||
|
/*
|
||||||
|
* USB driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_USB_USE_USB1 TRUE
|
||||||
|
#define STM32_USB_LOW_POWER_ON_SUSPEND FALSE
|
||||||
|
#define STM32_USB_USB1_HP_IRQ_PRIORITY 13
|
||||||
|
#define STM32_USB_USB1_LP_IRQ_PRIORITY 14
|
||||||
|
|
||||||
|
/*
|
||||||
|
* WDG driver system settings.
|
||||||
|
*/
|
||||||
|
#define STM32_WDG_USE_IWDG FALSE
|
||||||
|
|
||||||
|
#endif /* MCUCONF_H */
|
||||||
@@ -0,0 +1,39 @@
|
|||||||
|
/* Copyright 2019 John M Daly <[email protected]>
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#include "rev7.h"
|
||||||
|
|
||||||
|
#include "backlight.h"
|
||||||
|
#include "led.h"
|
||||||
|
#include "printf.h"
|
||||||
|
|
||||||
|
backlight_levels_config_t kb_backlight_config = {
|
||||||
|
.enable = true,
|
||||||
|
.breathing = true,
|
||||||
|
.level = BACKLIGHT_LEVELS
|
||||||
|
};
|
||||||
|
|
||||||
|
uint8_t *o_fb;
|
||||||
|
|
||||||
|
uint16_t counterst = 0;
|
||||||
|
|
||||||
|
void matrix_init_kb(void) {
|
||||||
|
matrix_init_user();
|
||||||
|
backlight_init_ports();
|
||||||
|
}
|
||||||
|
|
||||||
|
void matrix_scan_kb(void) {
|
||||||
|
matrix_scan_user();
|
||||||
|
}
|
||||||
@@ -0,0 +1,146 @@
|
|||||||
|
/* Copyright 2019 Jack Humbert <[email protected]>
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#pragma once
|
||||||
|
|
||||||
|
#include "quantum.h"
|
||||||
|
|
||||||
|
// This a shortcut to help you visually see your layout.
|
||||||
|
// The following is a layout that uses all available switch positions.
|
||||||
|
// The first section contains all of the arguments
|
||||||
|
// The second converts the arguments into a two-dimensional array
|
||||||
|
#define LAYOUT_all( \
|
||||||
|
K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014, \
|
||||||
|
K100, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114, \
|
||||||
|
K200, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K213, K214, \
|
||||||
|
K300, K301, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, K313, K314, \
|
||||||
|
K400, K401, K402, K404, K406, K408, K410, K411, K412, K413, K414 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014 }, \
|
||||||
|
{ K100, KC_NO, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114 }, \
|
||||||
|
{ K200, KC_NO, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K213, K214 }, \
|
||||||
|
{ K300, K301, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, KC_NO, K313, K314 }, \
|
||||||
|
{ K400, K401, K402, KC_NO, K404, KC_NO, K406, KC_NO, K408, KC_NO, K410, K411, K412, K413, K414 }, \
|
||||||
|
}
|
||||||
|
|
||||||
|
#define LAYOUT_60_ansi( \
|
||||||
|
K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K014, \
|
||||||
|
K100, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114, \
|
||||||
|
K200, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K214, \
|
||||||
|
K300, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, K313, \
|
||||||
|
K400, K401, K402, K406, K410, K411, K413, K414 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, KC_NO, K014 }, \
|
||||||
|
{ K100, KC_NO, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114 }, \
|
||||||
|
{ K200, KC_NO, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, KC_NO, K214 }, \
|
||||||
|
{ K300, KC_NO, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, KC_NO, K313, KC_NO }, \
|
||||||
|
{ K400, K401, K402, KC_NO, KC_NO, KC_NO, K406, KC_NO, KC_NO, KC_NO, K410, K411, KC_NO, K413, K414 }, \
|
||||||
|
}
|
||||||
|
|
||||||
|
#define LAYOUT_60_ansi_split_bs_rshift( \
|
||||||
|
K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014, \
|
||||||
|
K100, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114, \
|
||||||
|
K200, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K214, \
|
||||||
|
K300, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, K313, K314, \
|
||||||
|
K400, K401, K402, K406, K410, K411, K413, K414 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014 }, \
|
||||||
|
{ K100, KC_NO, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114 }, \
|
||||||
|
{ K200, KC_NO, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, KC_NO, K214 }, \
|
||||||
|
{ K300, KC_NO, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, KC_NO, K313, K314 }, \
|
||||||
|
{ K400, K401, K402, KC_NO, KC_NO, KC_NO, K406, KC_NO, KC_NO, KC_NO, K410, K411, KC_NO, K413, K414 }, \
|
||||||
|
}
|
||||||
|
|
||||||
|
#define LAYOUT_60_iso( \
|
||||||
|
K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K014, \
|
||||||
|
K100, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, \
|
||||||
|
K200, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K213, K214, \
|
||||||
|
K300, K301, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, K313, \
|
||||||
|
K400, K401, K402, K406, K410, K411, K413, K414 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, KC_NO, K014 }, \
|
||||||
|
{ K100, KC_NO, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, KC_NO }, \
|
||||||
|
{ K200, KC_NO, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K213, K214 }, \
|
||||||
|
{ K300, K301, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, KC_NO, K313, KC_NO }, \
|
||||||
|
{ K400, K401, K402, KC_NO, KC_NO, KC_NO, K406, KC_NO, KC_NO, KC_NO, K410, K411, KC_NO, K413, K414 }, \
|
||||||
|
}
|
||||||
|
|
||||||
|
#define LAYOUT_60_hhkb( \
|
||||||
|
K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014, \
|
||||||
|
K100, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114, \
|
||||||
|
K200, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K214, \
|
||||||
|
K300, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, K313, K314, \
|
||||||
|
K401, K402, K406, K411, K413 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014 }, \
|
||||||
|
{ K100, KC_NO, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114 }, \
|
||||||
|
{ K200, KC_NO, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, KC_NO, K214 }, \
|
||||||
|
{ K300, KC_NO, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, KC_NO, K313, K314 }, \
|
||||||
|
{ KC_NO, K401, K402, KC_NO, KC_NO, KC_NO, K406, KC_NO, KC_NO, KC_NO, KC_NO, K411, KC_NO, K413, KC_NO }, \
|
||||||
|
}
|
||||||
|
|
||||||
|
#define LAYOUT_60_hhkb_split_space( \
|
||||||
|
K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014, \
|
||||||
|
K100, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114, \
|
||||||
|
K200, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K214, \
|
||||||
|
K300, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, K313, K314, \
|
||||||
|
K401, K402, K404, K406, K408, K411, K413 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014 }, \
|
||||||
|
{ K100, KC_NO, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114 }, \
|
||||||
|
{ K200, KC_NO, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, KC_NO, K214 }, \
|
||||||
|
{ K300, KC_NO, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, KC_NO, K313, K314 }, \
|
||||||
|
{ KC_NO, K401, K402, KC_NO, K404, KC_NO, K406, KC_NO, K408, KC_NO, KC_NO, K411, KC_NO, K413, KC_NO }, \
|
||||||
|
}
|
||||||
|
|
||||||
|
#define LAYOUT_60_hhkb_split_625u_space( \
|
||||||
|
K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014, \
|
||||||
|
K100, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114, \
|
||||||
|
K200, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, K214, \
|
||||||
|
K300, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, K313, K314, \
|
||||||
|
K401, K402, K404, K406, K408, K410, K411, K413 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008, K009, K010, K011, K012, K013, K014 }, \
|
||||||
|
{ K100, KC_NO, K102, K103, K104, K105, K106, K107, K108, K109, K110, K111, K112, K113, K114 }, \
|
||||||
|
{ K200, KC_NO, K202, K203, K204, K205, K206, K207, K208, K209, K210, K211, K212, KC_NO, K214 }, \
|
||||||
|
{ K300, KC_NO, K302, K303, K304, K305, K306, K307, K308, K309, K310, K311, KC_NO, K313, K314 }, \
|
||||||
|
{ KC_NO, K401, K402, KC_NO, K404, KC_NO, K406, KC_NO, K408, KC_NO, K410, K411, KC_NO, K413, KC_NO }, \
|
||||||
|
}
|
||||||
|
|
||||||
|
// Backlighting
|
||||||
|
typedef union {
|
||||||
|
uint8_t raw;
|
||||||
|
struct {
|
||||||
|
bool enable :1;
|
||||||
|
bool breathing : 1;
|
||||||
|
uint8_t level :6;
|
||||||
|
};
|
||||||
|
} backlight_levels_config_t;
|
||||||
|
|
||||||
|
extern backlight_levels_config_t kb_backlight_config;
|
||||||
|
extern bool kb_backlight_breathing;
|
||||||
|
|
||||||
|
void backlight_init_ports(void);
|
||||||
|
void backlight_set(uint8_t level);
|
||||||
|
bool is_breathing(void);
|
||||||
|
void breathing_enable(void);
|
||||||
|
void breathing_disable(void);
|
||||||
@@ -0,0 +1,59 @@
|
|||||||
|
# project specific files
|
||||||
|
|
||||||
|
## chip/board settings
|
||||||
|
# - the next two should match the directories in
|
||||||
|
# <chibios>/os/hal/ports/$(MCU_FAMILY)/$(MCU_SERIES)
|
||||||
|
MCU_FAMILY = STM32
|
||||||
|
MCU_SERIES = STM32F3xx
|
||||||
|
|
||||||
|
# Linker script to use
|
||||||
|
# - it should exist either in <chibios>/os/common/ports/ARMCMx/compilers/GCC/ld/
|
||||||
|
# or <this_dir>/ld/
|
||||||
|
MCU_LDSCRIPT = STM32F303xC
|
||||||
|
|
||||||
|
# Startup code to use
|
||||||
|
# - it should exist in <chibios>/os/common/startup/ARMCMx/compilers/GCC/mk/
|
||||||
|
MCU_STARTUP = stm32f3xx
|
||||||
|
|
||||||
|
# Board: it should exist either in <chibios>/os/hal/boards/
|
||||||
|
# or <this_dir>/boards
|
||||||
|
BOARD = GENERIC_STM32_F303XC
|
||||||
|
|
||||||
|
# Cortex version
|
||||||
|
MCU = cortex-m4
|
||||||
|
|
||||||
|
# ARM version, CORTEX-M0/M1 are 6, CORTEX-M3/M4/M7 are 7
|
||||||
|
ARMV = 7
|
||||||
|
|
||||||
|
USE_FPU = yes
|
||||||
|
|
||||||
|
# Vector table for application
|
||||||
|
# 0x00000000-0x00001000 area is occupied by bootlaoder.*/
|
||||||
|
# The CORTEX_VTOR... is needed only for MCHCK/Infinity KB
|
||||||
|
# OPT_DEFS = -DCORTEX_VTOR_INIT=0x08005000
|
||||||
|
|
||||||
|
# Options to pass to dfu-util when flashing
|
||||||
|
DFU_ARGS = -d 0483:df11 -a 0 -s 0x08000000:leave
|
||||||
|
DFU_SUFFIX_ARGS = -v 0483 -p df11
|
||||||
|
|
||||||
|
# Code for backlight breathing:
|
||||||
|
SRC += led.c
|
||||||
|
|
||||||
|
# Build Options
|
||||||
|
# comment out to disable the options.
|
||||||
|
#
|
||||||
|
BACKLIGHT_ENABLE = yes
|
||||||
|
BOOTMAGIC_ENABLE = no # Virtual DIP switch configuration(+1000)
|
||||||
|
MOUSEKEY_ENABLE = yes # Mouse keys(+4700)
|
||||||
|
EXTRAKEY_ENABLE = yes # Audio control and System control(+450)
|
||||||
|
CONSOLE_ENABLE = no # Console for debug(+400)
|
||||||
|
COMMAND_ENABLE = no # Commands for debug and configuration
|
||||||
|
NKRO_ENABLE = yes # USB Nkey Rollover - if this doesn't work, see here: https://github.com/tmk/tmk_keyboard/wiki/FAQ#nkro-doesnt-work
|
||||||
|
AUDIO_ENABLE = no
|
||||||
|
RGBLIGHT_ENABLE = no # Enable keyboard underlight functionality
|
||||||
|
MIDI_ENABLE = no # MIDI controls
|
||||||
|
UNICODE_ENABLE = no # Unicode
|
||||||
|
BLUETOOTH_ENABLE = no # Enable Bluetooth with the Adafruit EZ-Key HID
|
||||||
|
LEADER_ENABLE = yes
|
||||||
|
|
||||||
|
LAYOUTS = 60_ansi 60_ansi_split_bs_rshift 60_iso 60_hhkb
|
||||||
@@ -20,11 +20,9 @@
|
|||||||
#define UNUSED_PINS
|
#define UNUSED_PINS
|
||||||
|
|
||||||
/* leds */
|
/* leds */
|
||||||
#define QMK_LED B4
|
#define JOTANCK_LEDS
|
||||||
#define BACKLIGHT_LEVELS 3
|
#define JOTANCK_LED1 B5
|
||||||
#define BACKLIGHT_PIN B5
|
#define JOTANCK_LED2 B4
|
||||||
#define BACKLIGHT_BREATHING
|
|
||||||
#define BREATHING_PERIOD 5
|
|
||||||
|
|
||||||
/* COL2ROW or ROW2COL */
|
/* COL2ROW or ROW2COL */
|
||||||
#define DIODE_DIRECTION COL2ROW
|
#define DIODE_DIRECTION COL2ROW
|
||||||
|
|||||||
@@ -1,6 +1,10 @@
|
|||||||
#include "jotanck.h"
|
#include "jotanck.h"
|
||||||
|
|
||||||
void matrix_init_kb(void) {
|
void matrix_init_kb(void) {
|
||||||
|
matrix_init_user();
|
||||||
|
}
|
||||||
|
|
||||||
matrix_init_user();
|
void keyboard_pre_init_user() {
|
||||||
|
setPinOutput(JOTANCK_LED1);
|
||||||
|
setPinOutput(JOTANCK_LED2);
|
||||||
}
|
}
|
||||||
@@ -78,7 +78,7 @@ const uint16_t PROGMEM keymaps[][MATRIX_ROWS][MATRIX_COLS] = {
|
|||||||
[_ADJUST] = LAYOUT_ortho_4x12 (
|
[_ADJUST] = LAYOUT_ortho_4x12 (
|
||||||
_______, RESET, _______, _______, _______, _______, _______, _______, KC_PSCR, KC_SLCK, KC_PAUS, _______,
|
_______, RESET, _______, _______, _______, _______, _______, _______, KC_PSCR, KC_SLCK, KC_PAUS, _______,
|
||||||
_______, _______, _______, _______, _______, _______, _______, _______, _______, _______, _______, _______,
|
_______, _______, _______, _______, _______, _______, _______, _______, _______, _______, _______, _______,
|
||||||
_______, _______, _______, _______, _______, BL_STEP, BL_BRTG, _______, _______, _______, _______, _______,
|
_______, _______, _______, _______, _______, _______, _______, _______, _______, _______, _______, _______,
|
||||||
_______, _______, _______, _______, _______, _______, _______, _______, _______, _______, _______, _______
|
_______, _______, _______, _______, _______, _______, _______, _______, _______, _______, _______, _______
|
||||||
),
|
),
|
||||||
};
|
};
|
||||||
|
|||||||
@@ -20,10 +20,10 @@ Hardware Availability: [Mercado Libre](https://articulo.mercadolibre.com.ar/MLA-
|
|||||||
| Arduino pin | A3 | A2 | A1 | A0 | 15 | 14 | TX0 | RXI | 2 | 3 | 4 | 5 |
|
| Arduino pin | A3 | A2 | A1 | A0 | 15 | 14 | TX0 | RXI | 2 | 3 | 4 | 5 |
|
||||||
| QMK pin | F4 | F5 | F6 | F7 | B1 | B3 | D3 | D2 | D1 | D0 | D4 | C6 |
|
| QMK pin | F4 | F5 | F6 | F7 | B1 | B3 | D3 | D2 | D1 | D0 | D4 | C6 |
|
||||||
|
|
||||||
| | QMK led | Backlight |
|
| | LED1 | LED2 |
|
||||||
|-------------|-----------|-----------|
|
|-------------|------|------|
|
||||||
| Arduino pin | 8 | 9 |
|
| Arduino pin | 8 | 9 |
|
||||||
| QMK pin | B4 | B5 |
|
| QMK pin | B5 | B4 |
|
||||||
|
|
||||||
### Compiling the Firmware
|
### Compiling the Firmware
|
||||||
|
|
||||||
|
|||||||
@@ -50,10 +50,10 @@ OPT_DEFS += -DINTERRUPT_CONTROL_ENDPOINT
|
|||||||
BOOTMAGIC_ENABLE = no # Virtual DIP switch configuration(+1000)
|
BOOTMAGIC_ENABLE = no # Virtual DIP switch configuration(+1000)
|
||||||
MOUSEKEY_ENABLE = yes # Mouse keys(+4700)
|
MOUSEKEY_ENABLE = yes # Mouse keys(+4700)
|
||||||
EXTRAKEY_ENABLE = yes # Audio control and System control(+450)
|
EXTRAKEY_ENABLE = yes # Audio control and System control(+450)
|
||||||
CONSOLE_ENABLE = yes # Console for debug(+400)
|
CONSOLE_ENABLE = yes # Console for debug(+400)
|
||||||
COMMAND_ENABLE = no # Commands for debug and configuration
|
COMMAND_ENABLE = no # Commands for debug and configuration
|
||||||
NKRO_ENABLE = yes # Nkey Rollover - if this doesn't work, see here: https://github.com/tmk/tmk_keyboard/wiki/FAQ#nkro-doesnt-work
|
NKRO_ENABLE = yes # Nkey Rollover - if this doesn't work, see here: https://github.com/tmk/tmk_keyboard/wiki/FAQ#nkro-doesnt-work
|
||||||
BACKLIGHT_ENABLE = yes # Enable keyboard backlight functionality
|
BACKLIGHT_ENABLE = no # Enable keyboard backlight functionality
|
||||||
MIDI_ENABLE = no # MIDI controls
|
MIDI_ENABLE = no # MIDI controls
|
||||||
AUDIO_ENABLE = no # Audio output on port C6
|
AUDIO_ENABLE = no # Audio output on port C6
|
||||||
UNICODE_ENABLE = no # Unicode
|
UNICODE_ENABLE = no # Unicode
|
||||||
|
|||||||
@@ -29,6 +29,7 @@ along with this program. If not, see <http://www.gnu.org/licenses/>.
|
|||||||
#include "i2c.h"
|
#include "i2c.h"
|
||||||
#include "quantum.h"
|
#include "quantum.h"
|
||||||
|
|
||||||
|
#ifdef RGBLIGHT_ENABLE
|
||||||
extern rgblight_config_t rgblight_config;
|
extern rgblight_config_t rgblight_config;
|
||||||
|
|
||||||
void rgblight_set(void) {
|
void rgblight_set(void) {
|
||||||
@@ -43,12 +44,16 @@ void rgblight_set(void) {
|
|||||||
i2c_init();
|
i2c_init();
|
||||||
i2c_send(0xb0, (uint8_t*)led, 3 * RGBLED_NUM);
|
i2c_send(0xb0, (uint8_t*)led, 3 * RGBLED_NUM);
|
||||||
}
|
}
|
||||||
|
#endif
|
||||||
|
|
||||||
__attribute__ ((weak))
|
__attribute__ ((weak))
|
||||||
void matrix_scan_user(void) {
|
void matrix_scan_user(void) {
|
||||||
rgblight_task();
|
#ifdef RGBLIGHT_ENABLE
|
||||||
|
rgblight_task();
|
||||||
|
#endif
|
||||||
}
|
}
|
||||||
|
|
||||||
|
#ifdef BACKLIGHT_ENABLE
|
||||||
void backlight_init_ports(void) {
|
void backlight_init_ports(void) {
|
||||||
DDRD |= (1<<0 | 1<<1 | 1<<4 | 1<<6);
|
DDRD |= (1<<0 | 1<<1 | 1<<4 | 1<<6);
|
||||||
PORTD &= ~(1<<0 | 1<<1 | 1<<4 | 1<<6);
|
PORTD &= ~(1<<0 | 1<<1 | 1<<4 | 1<<6);
|
||||||
@@ -62,4 +67,5 @@ void backlight_set(uint8_t level) {
|
|||||||
// Turn on the lights
|
// Turn on the lights
|
||||||
PORTD |= (1<<0 | 1<<1 | 1<<4 | 1<<6);
|
PORTD |= (1<<0 | 1<<1 | 1<<4 | 1<<6);
|
||||||
}
|
}
|
||||||
}
|
}
|
||||||
|
#endif
|
||||||
@@ -0,0 +1,251 @@
|
|||||||
|
/*
|
||||||
|
Copyright 2019 Ryota Goto
|
||||||
|
|
||||||
|
This program is free software: you can redistribute it and/or modify
|
||||||
|
it under the terms of the GNU General Public License as published by
|
||||||
|
the Free Software Foundation, either version 2 of the License, or
|
||||||
|
(at your option) any later version.
|
||||||
|
|
||||||
|
This program is distributed in the hope that it will be useful,
|
||||||
|
but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
GNU General Public License for more details.
|
||||||
|
|
||||||
|
You should have received a copy of the GNU General Public License
|
||||||
|
along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
|
||||||
|
#pragma once
|
||||||
|
|
||||||
|
#include "config_common.h"
|
||||||
|
|
||||||
|
/* USB Device descriptor parameter */
|
||||||
|
#define VENDOR_ID 0xA103
|
||||||
|
#define PRODUCT_ID 0x0005
|
||||||
|
#define DEVICE_VER 0x0001
|
||||||
|
#define MANUFACTURER KBDfans
|
||||||
|
#define PRODUCT KBD8X-MKII
|
||||||
|
#define DESCRIPTION TKL Keyboard
|
||||||
|
|
||||||
|
/* key matrix size */
|
||||||
|
#define MATRIX_ROWS 12
|
||||||
|
#define MATRIX_COLS 9
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Keyboard Matrix Assignments
|
||||||
|
*
|
||||||
|
* Change this to how you wired your keyboard
|
||||||
|
* COLS: AVR pins used for columns, left to right
|
||||||
|
* ROWS: AVR pins used for rows, top to bottom
|
||||||
|
* DIODE_DIRECTION: COL2ROW = COL = Anode (+), ROW = Cathode (-, marked on diode)
|
||||||
|
* ROW2COL = ROW = Anode (+), COL = Cathode (-, marked on diode)
|
||||||
|
*
|
||||||
|
*/
|
||||||
|
#define MATRIX_ROW_PINS { C6, B6, B5, B4, D7, D6, D4, D5, D3, D2, D1, D0 }
|
||||||
|
#define MATRIX_COL_PINS { F0, F1, F4, F5, F6, F7, C7, B0, B1 }
|
||||||
|
#define UNUSED_PINS
|
||||||
|
|
||||||
|
/* COL2ROW, ROW2COL*/
|
||||||
|
#define DIODE_DIRECTION COL2ROW
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Split Keyboard specific options, make sure you have 'SPLIT_KEYBOARD = yes' in your rules.mk, and define SOFT_SERIAL_PIN.
|
||||||
|
*/
|
||||||
|
#define SOFT_SERIAL_PIN D0 // or D1, D2, D3, E6
|
||||||
|
|
||||||
|
#define BACKLIGHT_PIN B7
|
||||||
|
#define BACKLIGHT_BREATHING
|
||||||
|
#define BACKLIGHT_LEVELS 3
|
||||||
|
|
||||||
|
#define RGB_DI_PIN B3
|
||||||
|
#ifdef RGB_DI_PIN
|
||||||
|
#define RGBLED_NUM 20
|
||||||
|
#define RGBLIGHT_HUE_STEP 8
|
||||||
|
#define RGBLIGHT_SAT_STEP 8
|
||||||
|
#define RGBLIGHT_VAL_STEP 8
|
||||||
|
#define RGBLIGHT_LIMIT_VAL 200 /* The maximum brightness level */
|
||||||
|
#define RGBLIGHT_SLEEP /* If defined, the RGB lighting will be switched off when the host goes to sleep */
|
||||||
|
/*== all animations enable ==*/
|
||||||
|
#define RGBLIGHT_ANIMATIONS
|
||||||
|
// /*== or choose animations ==*/
|
||||||
|
// #define RGBLIGHT_EFFECT_BREATHING
|
||||||
|
// #define RGBLIGHT_EFFECT_RAINBOW_MOOD
|
||||||
|
// #define RGBLIGHT_EFFECT_RAINBOW_SWIRL
|
||||||
|
// #define RGBLIGHT_EFFECT_SNAKE
|
||||||
|
// #define RGBLIGHT_EFFECT_KNIGHT
|
||||||
|
// #define RGBLIGHT_EFFECT_CHRISTMAS
|
||||||
|
// #define RGBLIGHT_EFFECT_STATIC_GRADIENT
|
||||||
|
// #define RGBLIGHT_EFFECT_RGB_TEST
|
||||||
|
// #define RGBLIGHT_EFFECT_ALTERNATING
|
||||||
|
// /*== customize breathing effect ==*/
|
||||||
|
// /*==== (DEFAULT) use fixed table instead of exp() and sin() ====*/
|
||||||
|
// #define RGBLIGHT_BREATHE_TABLE_SIZE 256 // 256(default) or 128 or 64
|
||||||
|
// /*==== use exp() and sin() ====*/
|
||||||
|
// #define RGBLIGHT_EFFECT_BREATHE_CENTER 1.85 // 1 to 2.7
|
||||||
|
// #define RGBLIGHT_EFFECT_BREATHE_MAX 255 // 0 to 255
|
||||||
|
#endif
|
||||||
|
|
||||||
|
/* Debounce reduces chatter (unintended double-presses) - set 0 if debouncing is not needed */
|
||||||
|
#define DEBOUNCE 5
|
||||||
|
|
||||||
|
/* define if matrix has ghost (lacks anti-ghosting diodes) */
|
||||||
|
//#define MATRIX_HAS_GHOST
|
||||||
|
|
||||||
|
/* number of backlight levels */
|
||||||
|
|
||||||
|
/* Mechanical locking support. Use KC_LCAP, KC_LNUM or KC_LSCR instead in keymap */
|
||||||
|
#define LOCKING_SUPPORT_ENABLE
|
||||||
|
/* Locking resynchronize hack */
|
||||||
|
#define LOCKING_RESYNC_ENABLE
|
||||||
|
|
||||||
|
/* If defined, GRAVE_ESC will always act as ESC when CTRL is held.
|
||||||
|
* This is userful for the Windows task manager shortcut (ctrl+shift+esc).
|
||||||
|
*/
|
||||||
|
// #define GRAVE_ESC_CTRL_OVERRIDE
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Force NKRO
|
||||||
|
*
|
||||||
|
* Force NKRO (nKey Rollover) to be enabled by default, regardless of the saved
|
||||||
|
* state in the bootmagic EEPROM settings. (Note that NKRO must be enabled in the
|
||||||
|
* makefile for this to work.)
|
||||||
|
*
|
||||||
|
* If forced on, NKRO can be disabled via magic key (default = LShift+RShift+N)
|
||||||
|
* until the next keyboard reset.
|
||||||
|
*
|
||||||
|
* NKRO may prevent your keystrokes from being detected in the BIOS, but it is
|
||||||
|
* fully operational during normal computer usage.
|
||||||
|
*
|
||||||
|
* For a less heavy-handed approach, enable NKRO via magic key (LShift+RShift+N)
|
||||||
|
* or via bootmagic (hold SPACE+N while plugging in the keyboard). Once set by
|
||||||
|
* bootmagic, NKRO mode will always be enabled until it is toggled again during a
|
||||||
|
* power-up.
|
||||||
|
*
|
||||||
|
*/
|
||||||
|
//#define FORCE_NKRO
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Magic Key Options
|
||||||
|
*
|
||||||
|
* Magic keys are hotkey commands that allow control over firmware functions of
|
||||||
|
* the keyboard. They are best used in combination with the HID Listen program,
|
||||||
|
* found here: https://www.pjrc.com/teensy/hid_listen.html
|
||||||
|
*
|
||||||
|
* The options below allow the magic key functionality to be changed. This is
|
||||||
|
* useful if your keyboard/keypad is missing keys and you want magic key support.
|
||||||
|
*
|
||||||
|
*/
|
||||||
|
|
||||||
|
/* key combination for magic key command */
|
||||||
|
/* defined by default; to change, uncomment and set to the combination you want */
|
||||||
|
// #define IS_COMMAND() (get_mods() == (MOD_BIT(KC_LSHIFT) | MOD_BIT(KC_RSHIFT)))
|
||||||
|
|
||||||
|
/* control how magic key switches layers */
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_FKEYS true
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_NKEYS true
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_CUSTOM false
|
||||||
|
|
||||||
|
/* override magic key keymap */
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_FKEYS
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_NKEYS
|
||||||
|
//#define MAGIC_KEY_SWITCH_LAYER_WITH_CUSTOM
|
||||||
|
//#define MAGIC_KEY_HELP H
|
||||||
|
//#define MAGIC_KEY_HELP_ALT SLASH
|
||||||
|
//#define MAGIC_KEY_DEBUG D
|
||||||
|
//#define MAGIC_KEY_DEBUG_MATRIX X
|
||||||
|
//#define MAGIC_KEY_DEBUG_KBD K
|
||||||
|
//#define MAGIC_KEY_DEBUG_MOUSE M
|
||||||
|
//#define MAGIC_KEY_VERSION V
|
||||||
|
//#define MAGIC_KEY_STATUS S
|
||||||
|
//#define MAGIC_KEY_CONSOLE C
|
||||||
|
//#define MAGIC_KEY_LAYER0 0
|
||||||
|
//#define MAGIC_KEY_LAYER0_ALT GRAVE
|
||||||
|
//#define MAGIC_KEY_LAYER1 1
|
||||||
|
//#define MAGIC_KEY_LAYER2 2
|
||||||
|
//#define MAGIC_KEY_LAYER3 3
|
||||||
|
//#define MAGIC_KEY_LAYER4 4
|
||||||
|
//#define MAGIC_KEY_LAYER5 5
|
||||||
|
//#define MAGIC_KEY_LAYER6 6
|
||||||
|
//#define MAGIC_KEY_LAYER7 7
|
||||||
|
//#define MAGIC_KEY_LAYER8 8
|
||||||
|
//#define MAGIC_KEY_LAYER9 9
|
||||||
|
//#define MAGIC_KEY_BOOTLOADER B
|
||||||
|
//#define MAGIC_KEY_BOOTLOADER_ALT ESC
|
||||||
|
//#define MAGIC_KEY_LOCK CAPS
|
||||||
|
//#define MAGIC_KEY_EEPROM E
|
||||||
|
//#define MAGIC_KEY_EEPROM_CLEAR BSPACE
|
||||||
|
//#define MAGIC_KEY_NKRO N
|
||||||
|
//#define MAGIC_KEY_SLEEP_LED Z
|
||||||
|
|
||||||
|
/*
|
||||||
|
* Feature disable options
|
||||||
|
* These options are also useful to firmware size reduction.
|
||||||
|
*/
|
||||||
|
|
||||||
|
/* disable debug print */
|
||||||
|
//#define NO_DEBUG
|
||||||
|
|
||||||
|
/* disable print */
|
||||||
|
//#define NO_PRINT
|
||||||
|
|
||||||
|
/* disable action features */
|
||||||
|
//#define NO_ACTION_LAYER
|
||||||
|
//#define NO_ACTION_TAPPING
|
||||||
|
//#define NO_ACTION_ONESHOT
|
||||||
|
//#define NO_ACTION_MACRO
|
||||||
|
//#define NO_ACTION_FUNCTION
|
||||||
|
|
||||||
|
/*
|
||||||
|
* MIDI options
|
||||||
|
*/
|
||||||
|
|
||||||
|
/* Prevent use of disabled MIDI features in the keymap */
|
||||||
|
//#define MIDI_ENABLE_STRICT 1
|
||||||
|
|
||||||
|
/* enable basic MIDI features:
|
||||||
|
- MIDI notes can be sent when in Music mode is on
|
||||||
|
*/
|
||||||
|
//#define MIDI_BASIC
|
||||||
|
|
||||||
|
/* enable advanced MIDI features:
|
||||||
|
- MIDI notes can be added to the keymap
|
||||||
|
- Octave shift and transpose
|
||||||
|
- Virtual sustain, portamento, and modulation wheel
|
||||||
|
- etc.
|
||||||
|
*/
|
||||||
|
//#define MIDI_ADVANCED
|
||||||
|
|
||||||
|
/* override number of MIDI tone keycodes (each octave adds 12 keycodes and allocates 12 bytes) */
|
||||||
|
//#define MIDI_TONE_KEYCODE_OCTAVES 1
|
||||||
|
|
||||||
|
/*
|
||||||
|
* HD44780 LCD Display Configuration
|
||||||
|
*/
|
||||||
|
/*
|
||||||
|
#define LCD_LINES 2 //< number of visible lines of the display
|
||||||
|
#define LCD_DISP_LENGTH 16 //< visibles characters per line of the display
|
||||||
|
|
||||||
|
#define LCD_IO_MODE 1 //< 0: memory mapped mode, 1: IO port mode
|
||||||
|
|
||||||
|
#if LCD_IO_MODE
|
||||||
|
#define LCD_PORT PORTB //< port for the LCD lines
|
||||||
|
#define LCD_DATA0_PORT LCD_PORT //< port for 4bit data bit 0
|
||||||
|
#define LCD_DATA1_PORT LCD_PORT //< port for 4bit data bit 1
|
||||||
|
#define LCD_DATA2_PORT LCD_PORT //< port for 4bit data bit 2
|
||||||
|
#define LCD_DATA3_PORT LCD_PORT //< port for 4bit data bit 3
|
||||||
|
#define LCD_DATA0_PIN 4 //< pin for 4bit data bit 0
|
||||||
|
#define LCD_DATA1_PIN 5 //< pin for 4bit data bit 1
|
||||||
|
#define LCD_DATA2_PIN 6 //< pin for 4bit data bit 2
|
||||||
|
#define LCD_DATA3_PIN 7 //< pin for 4bit data bit 3
|
||||||
|
#define LCD_RS_PORT LCD_PORT //< port for RS line
|
||||||
|
#define LCD_RS_PIN 3 //< pin for RS line
|
||||||
|
#define LCD_RW_PORT LCD_PORT //< port for RW line
|
||||||
|
#define LCD_RW_PIN 2 //< pin for RW line
|
||||||
|
#define LCD_E_PORT LCD_PORT //< port for Enable line
|
||||||
|
#define LCD_E_PIN 1 //< pin for Enable line
|
||||||
|
#endif
|
||||||
|
*/
|
||||||
|
|
||||||
|
/* Bootmagic Lite key configuration */
|
||||||
|
// #define BOOTMAGIC_LITE_ROW 0
|
||||||
|
// #define BOOTMAGIC_LITE_COLUMN 0
|
||||||
@@ -0,0 +1,103 @@
|
|||||||
|
{
|
||||||
|
"keyboard_name": "kbd8x_mk2",
|
||||||
|
"url": "https://kb.ai03.me/projects/kbd8x-mkii.html",
|
||||||
|
"maintainer": "ai03",
|
||||||
|
"width": 18.25,
|
||||||
|
"height": 6.25,
|
||||||
|
"layouts": {
|
||||||
|
"LAYOUT": {
|
||||||
|
"layout": [
|
||||||
|
{"label":"Esc", "x":0, "y":0},
|
||||||
|
{"label":"F1", "x":2, "y":0},
|
||||||
|
{"label":"F2", "x":3, "y":0},
|
||||||
|
{"label":"F3", "x":4, "y":0},
|
||||||
|
{"label":"F4", "x":5, "y":0},
|
||||||
|
{"label":"F5", "x":6.5, "y":0},
|
||||||
|
{"label":"F6", "x":7.5, "y":0},
|
||||||
|
{"label":"F7", "x":8.5, "y":0},
|
||||||
|
{"label":"F8", "x":9.5, "y":0},
|
||||||
|
{"label":"F9", "x":11, "y":0},
|
||||||
|
{"label":"F10", "x":12, "y":0},
|
||||||
|
{"label":"F11", "x":13, "y":0},
|
||||||
|
{"label":"F12", "x":14, "y":0},
|
||||||
|
{"label":"PrtSc", "x":15.25, "y":0},
|
||||||
|
{"label":"Scroll Lock", "x":16.25, "y":0},
|
||||||
|
{"label":"Pause", "x":17.25, "y":0},
|
||||||
|
{"label":"~", "x":0, "y":1.25},
|
||||||
|
{"label":"!", "x":1, "y":1.25},
|
||||||
|
{"label":"@", "x":2, "y":1.25},
|
||||||
|
{"label":"#", "x":3, "y":1.25},
|
||||||
|
{"label":"$", "x":4, "y":1.25},
|
||||||
|
{"label":"%", "x":5, "y":1.25},
|
||||||
|
{"label":"^", "x":6, "y":1.25},
|
||||||
|
{"label":"&", "x":7, "y":1.25},
|
||||||
|
{"label":"*", "x":8, "y":1.25},
|
||||||
|
{"label":"(", "x":9, "y":1.25},
|
||||||
|
{"label":")", "x":10, "y":1.25},
|
||||||
|
{"label":"_", "x":11, "y":1.25},
|
||||||
|
{"label":"+", "x":12, "y":1.25},
|
||||||
|
{"label":"Back Space", "x":13, "y":1.25},
|
||||||
|
{"label":"Delete", "x":14, "y":1.25},
|
||||||
|
{"label":"Insert", "x":15.25, "y":1.25},
|
||||||
|
{"label":"Home", "x":16.25, "y":1.25},
|
||||||
|
{"label":"PgUp", "x":17.25, "y":1.25},
|
||||||
|
{"label":"Tab", "x":0, "y":2.25, "w":1.5},
|
||||||
|
{"label":"Q", "x":1.5, "y":2.25},
|
||||||
|
{"label":"W", "x":2.5, "y":2.25},
|
||||||
|
{"label":"E", "x":3.5, "y":2.25},
|
||||||
|
{"label":"R", "x":4.5, "y":2.25},
|
||||||
|
{"label":"T", "x":5.5, "y":2.25},
|
||||||
|
{"label":"Y", "x":6.5, "y":2.25},
|
||||||
|
{"label":"U", "x":7.5, "y":2.25},
|
||||||
|
{"label":"I", "x":8.5, "y":2.25},
|
||||||
|
{"label":"O", "x":9.5, "y":2.25},
|
||||||
|
{"label":"P", "x":10.5, "y":2.25},
|
||||||
|
{"label":"{", "x":11.5, "y":2.25},
|
||||||
|
{"label":"}", "x":12.5, "y":2.25},
|
||||||
|
{"label":"|", "x":13.5, "y":2.25, "w":1.5},
|
||||||
|
{"label":"Delete", "x":15.25, "y":2.25},
|
||||||
|
{"label":"End", "x":16.25, "y":2.25},
|
||||||
|
{"label":"PgDn", "x":17.25, "y":2.25},
|
||||||
|
{"label":"Caps Lock", "x":0, "y":3.25, "w":1.75},
|
||||||
|
{"label":"A", "x":1.75, "y":3.25},
|
||||||
|
{"label":"S", "x":2.75, "y":3.25},
|
||||||
|
{"label":"D", "x":3.75, "y":3.25},
|
||||||
|
{"label":"F", "x":4.75, "y":3.25},
|
||||||
|
{"label":"G", "x":5.75, "y":3.25},
|
||||||
|
{"label":"H", "x":6.75, "y":3.25},
|
||||||
|
{"label":"J", "x":7.75, "y":3.25},
|
||||||
|
{"label":"K", "x":8.75, "y":3.25},
|
||||||
|
{"label":"L", "x":9.75, "y":3.25},
|
||||||
|
{"label":":", "x":10.75, "y":3.25},
|
||||||
|
{"label":"\"", "x":11.75, "y":3.25},
|
||||||
|
{"label":"Enter", "x":12.75, "y":3.25, "w":2.25},
|
||||||
|
{"label":"Shift", "x":0, "y":4.25, "w":1.25},
|
||||||
|
{"label":"|", "x":1.25, "y":4.25},
|
||||||
|
{"label":"Z", "x":2.25, "y":4.25},
|
||||||
|
{"label":"X", "x":3.25, "y":4.25},
|
||||||
|
{"label":"C", "x":4.25, "y":4.25},
|
||||||
|
{"label":"V", "x":5.25, "y":4.25},
|
||||||
|
{"label":"B", "x":6.25, "y":4.25},
|
||||||
|
{"label":"N", "x":7.25, "y":4.25},
|
||||||
|
{"label":"M", "x":8.25, "y":4.25},
|
||||||
|
{"label":"<", "x":9.25, "y":4.25},
|
||||||
|
{"label":">", "x":10.25, "y":4.25},
|
||||||
|
{"label":"?", "x":11.25, "y":4.25},
|
||||||
|
{"label":"Shift", "x":12.25, "y":4.25, "w":1.75},
|
||||||
|
{"label":"Fn", "x":14, "y":4.25},
|
||||||
|
{"label":"\u2191", "x":16.25, "y":4.25},
|
||||||
|
{"label":"Ctrl", "x":0, "y":5.25, "w":1.25},
|
||||||
|
{"label":"Win", "x":1.25, "y":5.25, "w":1.25},
|
||||||
|
{"label":"Alt", "x":2.5, "y":5.25, "w":1.25},
|
||||||
|
{"x":3.75, "y":5.25, "w":6.25},
|
||||||
|
{"label":"Alt", "x":10, "y":5.25, "w":1.25},
|
||||||
|
{"label":"Win", "x":11.25, "y":5.25, "w":1.25},
|
||||||
|
{"label":"Menu", "x":12.5, "y":5.25, "w":1.25},
|
||||||
|
{"label":"Ctrl", "x":13.75, "y":5.25, "w":1.25},
|
||||||
|
{"label":"\u2190", "x":15.25, "y":5.25},
|
||||||
|
{"label":"\u2193", "x":16.25, "y":5.25},
|
||||||
|
{"label":"\u2192", "x":17.25, "y":5.25}
|
||||||
|
]
|
||||||
|
}
|
||||||
|
}
|
||||||
|
}
|
||||||
@@ -0,0 +1,71 @@
|
|||||||
|
/* Copyright 2019 Ryota Goto
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#include "kbd8x_mk2.h"
|
||||||
|
|
||||||
|
void matrix_init_kb(void) {
|
||||||
|
|
||||||
|
// Indicator pins
|
||||||
|
// B2 - Scroll Lock
|
||||||
|
// E6 - Caps Lock
|
||||||
|
// Sinking setup - 5V -> LED/Resistor -> Pin
|
||||||
|
|
||||||
|
setPinOutput(B2);
|
||||||
|
setPinOutput(E6);
|
||||||
|
|
||||||
|
matrix_init_user();
|
||||||
|
}
|
||||||
|
|
||||||
|
void led_set_kb(uint8_t usb_led) {
|
||||||
|
|
||||||
|
// Toggle indicator LEDs
|
||||||
|
// Since they are a sinking setup, write HIGH to DISABLE, LOW to ENABLE
|
||||||
|
|
||||||
|
if (IS_LED_ON(usb_led, USB_LED_CAPS_LOCK)) {
|
||||||
|
writePinLow(E6);
|
||||||
|
} else {
|
||||||
|
writePinHigh(E6);
|
||||||
|
}
|
||||||
|
|
||||||
|
if (IS_LED_ON(usb_led, USB_LED_SCROLL_LOCK)) {
|
||||||
|
writePinLow(B2);
|
||||||
|
} else {
|
||||||
|
writePinHigh(B2);
|
||||||
|
}
|
||||||
|
|
||||||
|
led_set_user(usb_led);
|
||||||
|
}
|
||||||
|
|
||||||
|
// Optional override functions below.
|
||||||
|
// You can leave any or all of these undefined.
|
||||||
|
// These are only required if you want to perform custom actions.
|
||||||
|
|
||||||
|
/*
|
||||||
|
|
||||||
|
void matrix_scan_kb(void) {
|
||||||
|
// put your looping keyboard code here
|
||||||
|
// runs every cycle (a lot)
|
||||||
|
|
||||||
|
matrix_scan_user();
|
||||||
|
}
|
||||||
|
|
||||||
|
bool process_record_kb(uint16_t keycode, keyrecord_t *record) {
|
||||||
|
// put your per-action keyboard code here
|
||||||
|
// runs for every action, just before processing by the firmware
|
||||||
|
|
||||||
|
return process_record_user(keycode, record);
|
||||||
|
}
|
||||||
|
|
||||||
|
*/
|
||||||
@@ -0,0 +1,51 @@
|
|||||||
|
/* Copyright 2019 Ryota Goto
|
||||||
|
*
|
||||||
|
* This program is free software: you can redistribute it and/or modify
|
||||||
|
* it under the terms of the GNU General Public License as published by
|
||||||
|
* the Free Software Foundation, either version 2 of the License, or
|
||||||
|
* (at your option) any later version.
|
||||||
|
*
|
||||||
|
* This program is distributed in the hope that it will be useful,
|
||||||
|
* but WITHOUT ANY WARRANTY; without even the implied warranty of
|
||||||
|
* MERCHANTABILITY or FITNESS FOR A PARTICULAR PURPOSE. See the
|
||||||
|
* GNU General Public License for more details.
|
||||||
|
*
|
||||||
|
* You should have received a copy of the GNU General Public License
|
||||||
|
* along with this program. If not, see <http://www.gnu.org/licenses/>.
|
||||||
|
*/
|
||||||
|
#pragma once
|
||||||
|
|
||||||
|
#include "quantum.h"
|
||||||
|
|
||||||
|
/* This a shortcut to help you visually see your layout.
|
||||||
|
*
|
||||||
|
* The first section contains all of the arguments representing the physical
|
||||||
|
* layout of the board and position of the keys.
|
||||||
|
*
|
||||||
|
* The second converts the arguments into a two-dimensional array which
|
||||||
|
* represents the switch matrix.
|
||||||
|
*/
|
||||||
|
#define LAYOUT( \
|
||||||
|
K000, K001, K011, K002, K012, K003, K013, K004, K014, K005, K015, K006, K016, K007, K017, K008, \
|
||||||
|
K020, K030, K021, K031, K022, K032, K023, K033, K024, K034, K025, K035, K026, K036, K066, K027, K037, K028, \
|
||||||
|
K040, K050, K041, K051, K042, K052, K043, K053, K044, K054, K045, K055, K046, K056, K047, K057, K048, \
|
||||||
|
K060, K070, K061, K071, K062, K072, K063, K073, K064, K074, K065, K075, K076, \
|
||||||
|
K080, K090, K081, K091, K082, K092, K083, K093, K084, K094, K085, K095, K086, K096, K097, \
|
||||||
|
K100, K110, K101, K103, K105, K115, K106, K116, K107, K117, K108 \
|
||||||
|
) \
|
||||||
|
{ \
|
||||||
|
{ K000, K001, K002, K003, K004, K005, K006, K007, K008 }, \
|
||||||
|
{ KC_NO, K011, K012, K013, K014, K015, K016, K017, KC_NO }, \
|
||||||
|
{ K020, K021, K022, K023, K024, K025, K026, K027, K028 }, \
|
||||||
|
{ K030, K031, K032, K033, K034, K035, K036, K037, KC_NO }, \
|
||||||
|
{ K040, K041, K042, K043, K044, K045, K046, K047, K048 }, \
|
||||||
|
{ K050, K051, K052, K053, K054, K055, K056, K057, KC_NO }, \
|
||||||
|
{ K060, K061, K062, K063, K064, K065, K066, KC_NO, KC_NO }, \
|
||||||
|
{ K070, K071, K072, K073, K074, K075, K076, KC_NO, KC_NO }, \
|
||||||
|
{ K080, K081, K082, K083, K084, K085, K086, KC_NO, KC_NO }, \
|
||||||
|
{ K090, K091, K092, K093, K094, K095, K096, K097, KC_NO }, \
|
||||||
|
{ K100, K101, KC_NO, K103, KC_NO, K105, K106, K107, K108 }, \
|
||||||
|
{ K110, KC_NO, KC_NO, KC_NO, KC_NO, K115, K116, K117, KC_NO } \
|
||||||
|
}
|
||||||
|
|
||||||
|
|
||||||
Loaded 100 of 171 files, more files were not shown because too many files have changed in this diff.
Show more
Reference in new issue
Block a user